
PostgreSQL Source Code git master
Loading...
Searching...
No Matches
pathnode.h File Reference
#include "nodes/bitmapset.h"
#include "nodes/pathnodes.h"
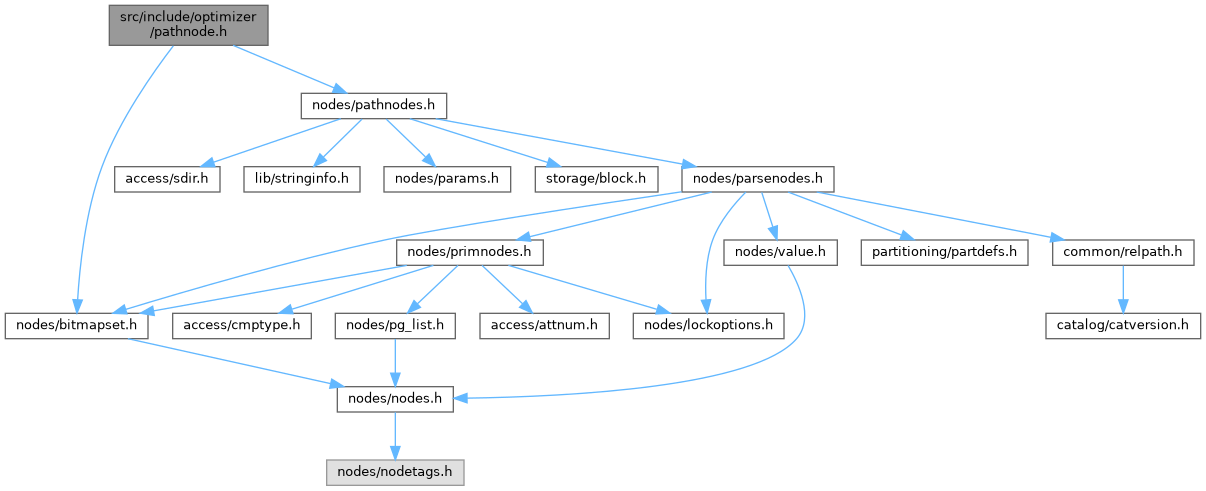
Include dependency graph for pathnode.h:
This graph shows which files directly or indirectly include this file:

Go to the source code of this file.

Data Structures

struct  AppendPathInput
 

Typedefs

typedef void(* build_simple_rel_hook_type) (PlannerInfo *root, RelOptInfo *rel, RangeTblEntry *rte)
 
typedef struct AppendPathInput AppendPathInput
 
typedef void(* joinrel_setup_hook_type) (PlannerInfo *root, RelOptInfo *joinrel, RelOptInfo *outer_rel, RelOptInfo *inner_rel, SpecialJoinInfo *sjinfo, List *restrictlist)
 

Functions

int compare_path_costs (Path *path1, Path *path2, CostSelector criterion)
 
int compare_fractional_path_costs (Path *path1, Path *path2, double fraction)
 
void set_cheapest (RelOptInfo *parent_rel)
 
void add_path (RelOptInfo *parent_rel, Path *new_path)
 
bool add_path_precheck (RelOptInfo *parent_rel, int disabled_nodes, Cost startup_cost, Cost total_cost, List *pathkeys, Relids required_outer)
 
void add_partial_path (RelOptInfo *parent_rel, Path *new_path)
 
bool add_partial_path_precheck (RelOptInfo *parent_rel, int disabled_nodes, Cost startup_cost, Cost total_cost, List *pathkeys)
 
Path * create_seqscan_path (PlannerInfo *root, RelOptInfo *rel, Relids required_outer, int parallel_workers)
 
Path * create_samplescan_path (PlannerInfo *root, RelOptInfo *rel, Relids required_outer)
 
IndexPath * create_index_path (PlannerInfo *root, IndexOptInfo *index, List *indexclauses, List *indexorderbys, List *indexorderbycols, List *pathkeys, ScanDirection indexscandir, bool indexonly, Relids required_outer, double loop_count, bool partial_path)
 
BitmapHeapPath * create_bitmap_heap_path (PlannerInfo *root, RelOptInfo *rel, Path *bitmapqual, Relids required_outer, double loop_count, int parallel_degree)
 
BitmapAndPath * create_bitmap_and_path (PlannerInfo *root, RelOptInfo *rel, List *bitmapquals)
 
BitmapOrPath * create_bitmap_or_path (PlannerInfo *root, RelOptInfo *rel, List *bitmapquals)
 
TidPath * create_tidscan_path (PlannerInfo *root, RelOptInfo *rel, List *tidquals, Relids required_outer)
 
TidRangePath * create_tidrangescan_path (PlannerInfo *root, RelOptInfo *rel, List *tidrangequals, Relids required_outer, int parallel_workers)
 
AppendPath * create_append_path (PlannerInfo *root, RelOptInfo *rel, AppendPathInput input, List *pathkeys, Relids required_outer, int parallel_workers, bool parallel_aware, double rows)
 
MergeAppendPath * create_merge_append_path (PlannerInfo *root, RelOptInfo *rel, List *subpaths, List *child_append_relid_sets, List *pathkeys, Relids required_outer)
 
GroupResultPath * create_group_result_path (PlannerInfo *root, RelOptInfo *rel, PathTarget *target, List *havingqual)
 
MaterialPath * create_material_path (RelOptInfo *rel, Path *subpath, bool enabled)
 
MemoizePath * create_memoize_path (PlannerInfo *root, RelOptInfo *rel, Path *subpath, List *param_exprs, List *hash_operators, bool singlerow, bool binary_mode, Cardinality est_calls)
 
GatherPath * create_gather_path (PlannerInfo *root, RelOptInfo *rel, Path *subpath, PathTarget *target, Relids required_outer, double *rows)
 
GatherMergePath * create_gather_merge_path (PlannerInfo *root, RelOptInfo *rel, Path *subpath, PathTarget *target, List *pathkeys, Relids required_outer, double *rows)
 
SubqueryScanPath * create_subqueryscan_path (PlannerInfo *root, RelOptInfo *rel, Path *subpath, bool trivial_pathtarget, List *pathkeys, Relids required_outer)
 
Path * create_functionscan_path (PlannerInfo *root, RelOptInfo *rel, List *pathkeys, Relids required_outer)
 
Path * create_valuesscan_path (PlannerInfo *root, RelOptInfo *rel, Relids required_outer)
 
Path * create_tablefuncscan_path (PlannerInfo *root, RelOptInfo *rel, Relids required_outer)
 
Path * create_ctescan_path (PlannerInfo *root, RelOptInfo *rel, List *pathkeys, Relids required_outer)
 
Path * create_namedtuplestorescan_path (PlannerInfo *root, RelOptInfo *rel, Relids required_outer)
 
Path * create_resultscan_path (PlannerInfo *root, RelOptInfo *rel, Relids required_outer)
 
Path * create_worktablescan_path (PlannerInfo *root, RelOptInfo *rel, Relids required_outer)
 
ForeignPath * create_foreignscan_path (PlannerInfo *root, RelOptInfo *rel, PathTarget *target, double rows, int disabled_nodes, Cost startup_cost, Cost total_cost, List *pathkeys, Relids required_outer, Path *fdw_outerpath, List *fdw_restrictinfo, List *fdw_private)
 
ForeignPath * create_foreign_join_path (PlannerInfo *root, RelOptInfo *rel, PathTarget *target, double rows, int disabled_nodes, Cost startup_cost, Cost total_cost, List *pathkeys, Relids required_outer, Path *fdw_outerpath, List *fdw_restrictinfo, List *fdw_private)
 
ForeignPath * create_foreign_upper_path (PlannerInfo *root, RelOptInfo *rel, PathTarget *target, double rows, int disabled_nodes, Cost startup_cost, Cost total_cost, List *pathkeys, Path *fdw_outerpath, List *fdw_restrictinfo, List *fdw_private)
 
Relids calc_nestloop_required_outer (Relids outerrelids, Relids outer_paramrels, Relids innerrelids, Relids inner_paramrels)
 
Relids calc_non_nestloop_required_outer (Path *outer_path, Path *inner_path)
 
NestPath * create_nestloop_path (PlannerInfo *root, RelOptInfo *joinrel, JoinType jointype, JoinCostWorkspace *workspace, JoinPathExtraData *extra, Path *outer_path, Path *inner_path, List *restrict_clauses, List *pathkeys, Relids required_outer)
 
MergePath * create_mergejoin_path (PlannerInfo *root, RelOptInfo *joinrel, JoinType jointype, JoinCostWorkspace *workspace, JoinPathExtraData *extra, Path *outer_path, Path *inner_path, List *restrict_clauses, List *pathkeys, Relids required_outer, List *mergeclauses, List *outersortkeys, List *innersortkeys, int outer_presorted_keys)
 
HashPath * create_hashjoin_path (PlannerInfo *root, RelOptInfo *joinrel, JoinType jointype, JoinCostWorkspace *workspace, JoinPathExtraData *extra, Path *outer_path, Path *inner_path, bool parallel_hash, List *restrict_clauses, Relids required_outer, List *hashclauses)
 
ProjectionPath * create_projection_path (PlannerInfo *root, RelOptInfo *rel, Path *subpath, PathTarget *target)
 
Path * apply_projection_to_path (PlannerInfo *root, RelOptInfo *rel, Path *path, PathTarget *target)
 
ProjectSetPath * create_set_projection_path (PlannerInfo *root, RelOptInfo *rel, Path *subpath, PathTarget *target)
 
SortPath * create_sort_path (PlannerInfo *root, RelOptInfo *rel, Path *subpath, List *pathkeys, double limit_tuples)
 
IncrementalSortPath * create_incremental_sort_path (PlannerInfo *root, RelOptInfo *rel, Path *subpath, List *pathkeys, int presorted_keys, double limit_tuples)
 
GroupPath * create_group_path (PlannerInfo *root, RelOptInfo *rel, Path *subpath, List *groupClause, List *qual, double numGroups)
 
UniquePath * create_unique_path (PlannerInfo *root, RelOptInfo *rel, Path *subpath, int numCols, double numGroups)
 
AggPath * create_agg_path (PlannerInfo *root, RelOptInfo *rel, Path *subpath, PathTarget *target, AggStrategy aggstrategy, AggSplit aggsplit, List *groupClause, List *qual, const AggClauseCosts *aggcosts, double numGroups)
 
GroupingSetsPath * create_groupingsets_path (PlannerInfo *root, RelOptInfo *rel, Path *subpath, List *having_qual, AggStrategy aggstrategy, List *rollups, const AggClauseCosts *agg_costs)
 
MinMaxAggPath * create_minmaxagg_path (PlannerInfo *root, RelOptInfo *rel, PathTarget *target, List *mmaggregates, List *quals)
 
WindowAggPath * create_windowagg_path (PlannerInfo *root, RelOptInfo *rel, Path *subpath, PathTarget *target, List *windowFuncs, List *runCondition, WindowClause *winclause, List *qual, bool topwindow)
 
SetOpPath * create_setop_path (PlannerInfo *root, RelOptInfo *rel, Path *leftpath, Path *rightpath, SetOpCmd cmd, SetOpStrategy strategy, List *groupList, double numGroups, double outputRows)
 
RecursiveUnionPath * create_recursiveunion_path (PlannerInfo *root, RelOptInfo *rel, Path *leftpath, Path *rightpath, PathTarget *target, List *distinctList, int wtParam, double numGroups)
 
LockRowsPath * create_lockrows_path (PlannerInfo *root, RelOptInfo *rel, Path *subpath, List *rowMarks, int epqParam)
 
ModifyTablePath * create_modifytable_path (PlannerInfo *root, RelOptInfo *rel, Path *subpath, CmdType operation, bool canSetTag, Index nominalRelation, Index rootRelation, List *resultRelations, List *updateColnosLists, List *withCheckOptionLists, List *returningLists, List *rowMarks, OnConflictExpr *onconflict, List *mergeActionLists, List *mergeJoinConditions, ForPortionOfExpr *forPortionOf, int epqParam)
 
LimitPath * create_limit_path (PlannerInfo *root, RelOptInfo *rel, Path *subpath, Node *limitOffset, Node *limitCount, LimitOption limitOption, int64 offset_est, int64 count_est)
 
void adjust_limit_rows_costs (double *rows, Cost *startup_cost, Cost *total_cost, int64 offset_est, int64 count_est)
 
Path * reparameterize_path (PlannerInfo *root, Path *path, Relids required_outer, double loop_count)
 
Path * reparameterize_path_by_child (PlannerInfo *root, Path *path, RelOptInfo *child_rel)
 
bool path_is_reparameterizable_by_child (Path *path, RelOptInfo *child_rel)
 
void setup_simple_rel_arrays (PlannerInfo *root)
 
void expand_planner_arrays (PlannerInfo *root, int add_size)
 
RelOptInfo * build_simple_rel (PlannerInfo *root, int relid, RelOptInfo *parent)
 
RelOptInfo * build_simple_grouped_rel (PlannerInfo *root, RelOptInfo *rel)
 
RelOptInfo * build_grouped_rel (PlannerInfo *root, RelOptInfo *rel)
 
RelOptInfo * find_base_rel (PlannerInfo *root, int relid)
 
RelOptInfo * find_base_rel_noerr (PlannerInfo *root, int relid)
 
RelOptInfo * find_base_rel_ignore_join (PlannerInfo *root, int relid)
 
RelOptInfo * find_join_rel (PlannerInfo *root, Relids relids)
 
RelOptInfo * build_join_rel (PlannerInfo *root, Relids joinrelids, RelOptInfo *outer_rel, RelOptInfo *inner_rel, SpecialJoinInfo *sjinfo, List *pushed_down_joins, List **restrictlist_ptr)
 
Relids min_join_parameterization (PlannerInfo *root, Relids joinrelids, RelOptInfo *outer_rel, RelOptInfo *inner_rel)
 
RelOptInfo * fetch_upper_rel (PlannerInfo *root, UpperRelationKind kind, Relids relids)
 
Relids find_childrel_parents (PlannerInfo *root, RelOptInfo *rel)
 
ParamPathInfo * get_baserel_parampathinfo (PlannerInfo *root, RelOptInfo *baserel, Relids required_outer)
 
ParamPathInfo * get_joinrel_parampathinfo (PlannerInfo *root, RelOptInfo *joinrel, Path *outer_path, Path *inner_path, SpecialJoinInfo *sjinfo, Relids required_outer, List **restrict_clauses)
 
ParamPathInfo * get_appendrel_parampathinfo (RelOptInfo *appendrel, Relids required_outer)
 
ParamPathInfo * find_param_path_info (RelOptInfo *rel, Relids required_outer)
 
Bitmapset * get_param_path_clause_serials (Path *path)
 
RelOptInfo * build_child_join_rel (PlannerInfo *root, RelOptInfo *outer_rel, RelOptInfo *inner_rel, RelOptInfo *parent_joinrel, List *restrictlist, SpecialJoinInfo *sjinfo, int nappinfos, AppendRelInfo **appinfos)
 
RelAggInfo * create_rel_agg_info (PlannerInfo *root, RelOptInfo *rel, bool calculate_grouped_rows)
 

Variables

PGDLLIMPORT build_simple_rel_hook_type build_simple_rel_hook
 
PGDLLIMPORT joinrel_setup_hook_type joinrel_setup_hook
 

Typedef Documentation

◆ AppendPathInput

◆ build_simple_rel_hook_type

typedef void(* build_simple_rel_hook_type) (PlannerInfo *root, RelOptInfo *rel, RangeTblEntry *rte)

Definition at line 21 of file pathnode.h.

◆ joinrel_setup_hook_type

typedef void(* joinrel_setup_hook_type) (PlannerInfo *root, RelOptInfo *joinrel, RelOptInfo *outer_rel, RelOptInfo *inner_rel, SpecialJoinInfo *sjinfo, List *restrictlist)

Definition at line 42 of file pathnode.h.

Function Documentation

◆ add_partial_path()

void add_partial_path ( RelOptInfo *  parent_rel,
Path *  new_path 
)
extern

Definition at line 793 of file pathnode.c.

794{
795 bool accept_new = true; /* unless we find a superior old path */
796 int insert_at = 0; /* where to insert new item */
797 ListCell *p1;
798
799 /* Check for query cancel. */
801
802 /* Path to be added must be parallel safe. */
803 Assert(new_path->parallel_safe);
804
805 /* Relation should be OK for parallelism, too. */
806 Assert(parent_rel->consider_parallel);
807
808 /*
809 * As in add_path, throw out any paths which are dominated by the new
810 * path, but throw out the new path if some existing path dominates it.
811 */
812 foreach(p1, parent_rel->partial_pathlist)
813 {
814 Path *old_path = (Path *) lfirst(p1);
815 bool remove_old = false; /* unless new proves superior */
817
818 /* Compare pathkeys. */
819 keyscmp = compare_pathkeys(new_path->pathkeys, old_path->pathkeys);
820
821 /*
822 * Unless pathkeys are incompatible, see if one of the paths dominates
823 * the other (both in startup and total cost). It may happen that one
824 * path has lower startup cost, the other has lower total cost.
825 */
827 {
829
830 /*
831 * Do a fuzzy cost comparison with standard fuzziness limit.
832 */
835 if (costcmp == COSTS_BETTER1)
836 {
838 remove_old = true;
839 }
840 else if (costcmp == COSTS_BETTER2)
841 {
843 accept_new = false;
844 }
845 else if (costcmp == COSTS_EQUAL)
846 {
848 remove_old = true;
849 else if (keyscmp == PATHKEYS_BETTER2)
850 accept_new = false;
852 1.0000000001) == COSTS_BETTER1)
853 remove_old = true;
854 else
855 accept_new = false;
856 }
857 }
858
859 /*
860 * Remove current element from partial_pathlist if dominated by new.
861 */
862 if (remove_old)
863 {
864 parent_rel->partial_pathlist =
865 foreach_delete_current(parent_rel->partial_pathlist, p1);
867 }
868 else
869 {
870 /*
871 * new belongs after this old path if it has more disabled nodes
872 * or if it has the same number of nodes but a greater total cost
873 */
874 if (new_path->disabled_nodes > old_path->disabled_nodes ||
875 (new_path->disabled_nodes == old_path->disabled_nodes &&
876 new_path->total_cost >= old_path->total_cost))
878 }
879
880 /*
881 * If we found an old path that dominates new_path, we can quit
882 * scanning the partial_pathlist; we will not add new_path, and we
883 * assume new_path cannot dominate any later path.
884 */
885 if (!accept_new)
886 break;
887 }
888
889 if (accept_new)
890 {
891 /* Accept the new path: insert it at proper place */
892 parent_rel->partial_pathlist =
893 list_insert_nth(parent_rel->partial_pathlist, insert_at, new_path);
894 }
895 else
896 {
897 /* Reject and recycle the new path */
899 }
900}
#define Assert(condition)
Definition c.h:1002
List * list_insert_nth(List *list, int pos, void *datum)
Definition list.c:439
void pfree(void *pointer)
Definition mcxt.c:1619
#define CHECK_FOR_INTERRUPTS()
Definition miscadmin.h:125
PathKeysComparison compare_pathkeys(List *keys1, List *keys2)
Definition pathkeys.c:304
static PathCostComparison compare_path_costs_fuzzily(Path *path1, Path *path2, double fuzz_factor)
Definition pathnode.c:181
#define STD_FUZZ_FACTOR
Definition pathnode.c:47
PathCostComparison
Definition pathnode.c:35
@ COSTS_EQUAL
Definition pathnode.c:36
@ COSTS_BETTER1
Definition pathnode.c:37
@ COSTS_BETTER2
Definition pathnode.c:38
PathKeysComparison
Definition paths.h:218
@ PATHKEYS_BETTER2
Definition paths.h:221
@ PATHKEYS_BETTER1
Definition paths.h:220
@ PATHKEYS_DIFFERENT
Definition paths.h:222
#define lfirst(lc)
Definition pg_list.h:172
#define foreach_current_index(var_or_cell)
Definition pg_list.h:435
#define foreach_delete_current(lst, var_or_cell)
Definition pg_list.h:423
static int fb(int x)

References Assert, CHECK_FOR_INTERRUPTS, compare_path_costs_fuzzily(), compare_pathkeys(), COSTS_BETTER1, COSTS_BETTER2, COSTS_EQUAL, fb(), foreach_current_index, foreach_delete_current, lfirst, list_insert_nth(), PATHKEYS_BETTER1, PATHKEYS_BETTER2, PATHKEYS_DIFFERENT, pfree(), and STD_FUZZ_FACTOR.

Referenced by add_paths_to_append_rel(), build_index_paths(), build_setop_child_paths(), create_partial_bitmap_paths(), create_partial_distinct_paths(), create_partial_grouping_paths(), create_partial_unique_paths(), create_plain_partial_paths(), create_tidscan_paths(), generate_grouped_paths(), grouping_planner(), set_subquery_pathlist(), try_partial_hashjoin_path(), try_partial_mergejoin_path(), and try_partial_nestloop_path().

◆ add_partial_path_precheck()

bool add_partial_path_precheck ( RelOptInfo *  parent_rel,
int  disabled_nodes,
Cost  startup_cost,
Cost  total_cost,
List *  pathkeys 
)
extern

Definition at line 912 of file pathnode.c.

914{
915 bool consider_startup = parent_rel->consider_startup;
916 ListCell *p1;
917
918 /*
919 * Our goal here is twofold. First, we want to find out whether this path
920 * is clearly inferior to some existing partial path. If so, we want to
921 * reject it immediately. Second, we want to find out whether this path
922 * is clearly superior to some existing partial path -- at least, modulo
923 * final cost computations. If so, we definitely want to consider it.
924 *
925 * Unlike add_path(), we never try to exit this loop early. This is
926 * because we expect partial_pathlist to be very short, and getting a
927 * definitive answer at this stage avoids the need to call
928 * add_path_precheck.
929 */
930 foreach(p1, parent_rel->partial_pathlist)
931 {
932 Path *old_path = (Path *) lfirst(p1);
935
936 /*
937 * First, compare costs and disabled nodes. This logic should be
938 * identical to compare_path_costs_fuzzily, except that one of the
939 * paths hasn't been created yet, and the fuzz factor is always
940 * STD_FUZZ_FACTOR.
941 */
942 if (unlikely(old_path->disabled_nodes != disabled_nodes))
943 {
944 if (disabled_nodes < old_path->disabled_nodes)
946 else
948 }
949 else if (total_cost > old_path->total_cost * STD_FUZZ_FACTOR)
950 {
951 if (consider_startup &&
952 old_path->startup_cost > startup_cost * STD_FUZZ_FACTOR)
954 else
956 }
957 else if (old_path->total_cost > total_cost * STD_FUZZ_FACTOR)
958 {
959 if (consider_startup &&
960 startup_cost > old_path->startup_cost * STD_FUZZ_FACTOR)
962 else
964 }
965 else if (startup_cost > old_path->startup_cost * STD_FUZZ_FACTOR)
967 else if (old_path->startup_cost > startup_cost * STD_FUZZ_FACTOR)
969 else
971
972 /*
973 * If one path wins on startup cost and the other on total cost, we
974 * can't say for sure which is better.
975 */
977 continue;
978
979 /*
980 * If the two paths have different pathkeys, we can't say for sure
981 * which is better.
982 */
983 keyscmp = compare_pathkeys(pathkeys, old_path->pathkeys);
985 continue;
986
987 /*
988 * If the existing path is cheaper and the pathkeys are equal or
989 * worse, the new path is not interesting.
990 */
992 return false;
993
994 /*
995 * If the new path is cheaper and the pathkeys are equal or better, it
996 * is definitely interesting.
997 */
999 return true;
1000 }
1001
1002 /*
1003 * This path is neither clearly inferior to an existing partial path nor
1004 * clearly good enough that it might replace one. Compare it to
1005 * non-parallel plans. If it loses even before accounting for the cost of
1006 * the Gather node, we should definitely reject it.
1007 */
1008 if (!add_path_precheck(parent_rel, disabled_nodes, startup_cost,
1009 total_cost, pathkeys, NULL))
1010 return false;
1011
1012 return true;
1013}
#define unlikely(x)
Definition c.h:497
@ COSTS_DIFFERENT
Definition pathnode.c:39
bool add_path_precheck(RelOptInfo *parent_rel, int disabled_nodes, Cost startup_cost, Cost total_cost, List *pathkeys, Relids required_outer)
Definition pathnode.c:686

References add_path_precheck(), compare_pathkeys(), COSTS_BETTER1, COSTS_BETTER2, COSTS_DIFFERENT, COSTS_EQUAL, fb(), lfirst, PATHKEYS_BETTER1, PATHKEYS_BETTER2, PATHKEYS_DIFFERENT, STD_FUZZ_FACTOR, and unlikely.

Referenced by try_partial_hashjoin_path(), try_partial_mergejoin_path(), and try_partial_nestloop_path().

◆ add_path()

void add_path ( RelOptInfo *  parent_rel,
Path *  new_path 
)
extern

Definition at line 459 of file pathnode.c.

460{
461 bool accept_new = true; /* unless we find a superior old path */
462 int insert_at = 0; /* where to insert new item */
464 ListCell *p1;
465
466 /*
467 * This is a convenient place to check for query cancel --- no part of the
468 * planner goes very long without calling add_path().
469 */
471
472 /* Pretend parameterized paths have no pathkeys, per comment above */
473 new_path_pathkeys = new_path->param_info ? NIL : new_path->pathkeys;
474
475 /*
476 * Loop to check proposed new path against old paths. Note it is possible
477 * for more than one old path to be tossed out because new_path dominates
478 * it.
479 */
480 foreach(p1, parent_rel->pathlist)
481 {
482 Path *old_path = (Path *) lfirst(p1);
483 bool remove_old = false; /* unless new proves superior */
487
488 /*
489 * Do a fuzzy cost comparison with standard fuzziness limit.
490 */
493
494 /*
495 * If the two paths compare differently for startup and total cost,
496 * then we want to keep both, and we can skip comparing pathkeys and
497 * required_outer rels. If they compare the same, proceed with the
498 * other comparisons. Row count is checked last. (We make the tests
499 * in this order because the cost comparison is most likely to turn
500 * out "different", and the pathkeys comparison next most likely. As
501 * explained above, row count very seldom makes a difference, so even
502 * though it's cheap to compare there's not much point in checking it
503 * earlier.)
504 */
506 {
507 /* Similarly check to see if either dominates on pathkeys */
509
510 old_path_pathkeys = old_path->param_info ? NIL : old_path->pathkeys;
514 {
515 switch (costcmp)
516 {
517 case COSTS_EQUAL:
521 {
522 if ((outercmp == BMS_EQUAL ||
523 outercmp == BMS_SUBSET1) &&
524 new_path->rows <= old_path->rows &&
525 new_path->parallel_safe >= old_path->parallel_safe)
526 remove_old = true; /* new dominates old */
527 }
528 else if (keyscmp == PATHKEYS_BETTER2)
529 {
530 if ((outercmp == BMS_EQUAL ||
531 outercmp == BMS_SUBSET2) &&
532 new_path->rows >= old_path->rows &&
533 new_path->parallel_safe <= old_path->parallel_safe)
534 accept_new = false; /* old dominates new */
535 }
536 else /* keyscmp == PATHKEYS_EQUAL */
537 {
538 if (outercmp == BMS_EQUAL)
539 {
540 /*
541 * Same pathkeys and outer rels, and fuzzily
542 * the same cost, so keep just one; to decide
543 * which, first check parallel-safety, then
544 * rows, then do a fuzzy cost comparison with
545 * very small fuzz limit. (We used to do an
546 * exact cost comparison, but that results in
547 * annoying platform-specific plan variations
548 * due to roundoff in the cost estimates.) If
549 * things are still tied, arbitrarily keep
550 * only the old path. Notice that we will
551 * keep only the old path even if the
552 * less-fuzzy comparison decides the startup
553 * and total costs compare differently.
554 */
555 if (new_path->parallel_safe >
556 old_path->parallel_safe)
557 remove_old = true; /* new dominates old */
558 else if (new_path->parallel_safe <
559 old_path->parallel_safe)
560 accept_new = false; /* old dominates new */
561 else if (new_path->rows < old_path->rows)
562 remove_old = true; /* new dominates old */
563 else if (new_path->rows > old_path->rows)
564 accept_new = false; /* old dominates new */
566 old_path,
567 1.0000000001) == COSTS_BETTER1)
568 remove_old = true; /* new dominates old */
569 else
570 accept_new = false; /* old equals or
571 * dominates new */
572 }
573 else if (outercmp == BMS_SUBSET1 &&
574 new_path->rows <= old_path->rows &&
575 new_path->parallel_safe >= old_path->parallel_safe)
576 remove_old = true; /* new dominates old */
577 else if (outercmp == BMS_SUBSET2 &&
578 new_path->rows >= old_path->rows &&
579 new_path->parallel_safe <= old_path->parallel_safe)
580 accept_new = false; /* old dominates new */
581 /* else different parameterizations, keep both */
582 }
583 break;
584 case COSTS_BETTER1:
586 {
589 if ((outercmp == BMS_EQUAL ||
590 outercmp == BMS_SUBSET1) &&
591 new_path->rows <= old_path->rows &&
592 new_path->parallel_safe >= old_path->parallel_safe)
593 remove_old = true; /* new dominates old */
594 }
595 break;
596 case COSTS_BETTER2:
598 {
601 if ((outercmp == BMS_EQUAL ||
602 outercmp == BMS_SUBSET2) &&
603 new_path->rows >= old_path->rows &&
604 new_path->parallel_safe <= old_path->parallel_safe)
605 accept_new = false; /* old dominates new */
606 }
607 break;
608 case COSTS_DIFFERENT:
609
610 /*
611 * can't get here, but keep this case to keep compiler
612 * quiet
613 */
614 break;
615 }
616 }
617 }
618
619 /*
620 * Remove current element from pathlist if dominated by new.
621 */
622 if (remove_old)
623 {
624 parent_rel->pathlist = foreach_delete_current(parent_rel->pathlist,
625 p1);
626
627 /*
628 * Delete the data pointed-to by the deleted cell, if possible
629 */
630 if (!IsA(old_path, IndexPath))
632 }
633 else
634 {
635 /*
636 * new belongs after this old path if it has more disabled nodes
637 * or if it has the same number of nodes but a greater total cost
638 */
639 if (new_path->disabled_nodes > old_path->disabled_nodes ||
640 (new_path->disabled_nodes == old_path->disabled_nodes &&
641 new_path->total_cost >= old_path->total_cost))
643 }
644
645 /*
646 * If we found an old path that dominates new_path, we can quit
647 * scanning the pathlist; we will not add new_path, and we assume
648 * new_path cannot dominate any other elements of the pathlist.
649 */
650 if (!accept_new)
651 break;
652 }
653
654 if (accept_new)
655 {
656 /* Accept the new path: insert it at proper place in pathlist */
657 parent_rel->pathlist =
659 }
660 else
661 {
662 /* Reject and recycle the new path */
663 if (!IsA(new_path, IndexPath))
665 }
666}
BMS_Comparison bms_subset_compare(const Bitmapset *a, const Bitmapset *b)
Definition bitmapset.c:580
BMS_Comparison
Definition bitmapset.h:61
@ BMS_SUBSET1
Definition bitmapset.h:63
@ BMS_EQUAL
Definition bitmapset.h:62
@ BMS_SUBSET2
Definition bitmapset.h:64
#define IsA(nodeptr, _type_)
Definition nodes.h:162
#define PATH_REQ_OUTER(path)
Definition pathnodes.h:2015
#define NIL
Definition pg_list.h:68
Definition pg_list.h:54

References BMS_EQUAL, BMS_SUBSET1, BMS_SUBSET2, bms_subset_compare(), CHECK_FOR_INTERRUPTS, compare_path_costs_fuzzily(), compare_pathkeys(), COSTS_BETTER1, COSTS_BETTER2, COSTS_DIFFERENT, COSTS_EQUAL, fb(), foreach_current_index, foreach_delete_current, IsA, lfirst, list_insert_nth(), NIL, PATH_REQ_OUTER, PATHKEYS_BETTER1, PATHKEYS_BETTER2, PATHKEYS_DIFFERENT, pfree(), and STD_FUZZ_FACTOR.

Referenced by add_foreign_final_paths(), add_foreign_grouping_paths(), add_foreign_ordered_paths(), add_paths_to_append_rel(), add_paths_to_grouping_rel(), add_paths_with_pathkeys_for_rel(), build_setop_child_paths(), BuildParameterizedTidPaths(), consider_groupingsets_paths(), create_degenerate_grouping_paths(), create_final_distinct_paths(), create_final_unique_paths(), create_index_paths(), create_one_window_path(), create_ordered_paths(), create_partial_grouping_paths(), create_tidscan_paths(), fileGetForeignPaths(), gather_grouping_paths(), generate_gather_paths(), generate_grouped_paths(), generate_nonunion_paths(), generate_orderedappend_paths(), generate_recursion_path(), generate_union_paths(), generate_useful_gather_paths(), get_index_paths(), grouping_planner(), mark_dummy_rel(), postgresGetForeignJoinPaths(), postgresGetForeignPaths(), preprocess_minmax_aggregates(), query_planner(), set_cte_pathlist(), set_dummy_rel_pathlist(), set_function_pathlist(), set_namedtuplestore_pathlist(), set_plain_rel_pathlist(), set_result_pathlist(), set_subquery_pathlist(), set_tablefunc_pathlist(), set_tablesample_rel_pathlist(), set_values_pathlist(), set_worktable_pathlist(), try_hashjoin_path(), try_mergejoin_path(), and try_nestloop_path().

◆ add_path_precheck()

bool add_path_precheck ( RelOptInfo *  parent_rel,
int  disabled_nodes,
Cost  startup_cost,
Cost  total_cost,
List *  pathkeys,
Relids  required_outer 
)
extern

Definition at line 686 of file pathnode.c.

689{
691 bool consider_startup;
692 ListCell *p1;
693
694 /* Pretend parameterized paths have no pathkeys, per add_path policy */
695 new_path_pathkeys = required_outer ? NIL : pathkeys;
696
697 /* Decide whether new path's startup cost is interesting */
698 consider_startup = required_outer ? parent_rel->consider_param_startup : parent_rel->consider_startup;
699
700 foreach(p1, parent_rel->pathlist)
701 {
702 Path *old_path = (Path *) lfirst(p1);
704
705 /*
706 * Since the pathlist is sorted by disabled_nodes and then by
707 * total_cost, we can stop looking once we reach a path with more
708 * disabled nodes, or the same number of disabled nodes plus a
709 * total_cost larger than the new path's.
710 */
711 if (unlikely(old_path->disabled_nodes != disabled_nodes))
712 {
713 if (disabled_nodes < old_path->disabled_nodes)
714 break;
715 }
716 else if (total_cost <= old_path->total_cost * STD_FUZZ_FACTOR)
717 break;
718
719 /*
720 * We are looking for an old_path with the same parameterization (and
721 * by assumption the same rowcount) that dominates the new path on
722 * pathkeys as well as both cost metrics. If we find one, we can
723 * reject the new path.
724 *
725 * Cost comparisons here should match compare_path_costs_fuzzily.
726 */
727 /* new path can win on startup cost only if consider_startup */
728 if (startup_cost > old_path->startup_cost * STD_FUZZ_FACTOR ||
729 !consider_startup)
730 {
731 /* new path loses on cost, so check pathkeys... */
733
734 old_path_pathkeys = old_path->param_info ? NIL : old_path->pathkeys;
737 if (keyscmp == PATHKEYS_EQUAL ||
739 {
740 /* new path does not win on pathkeys... */
742 {
743 /* Found an old path that dominates the new one */
744 return false;
745 }
746 }
747 }
748 }
749
750 return true;
751}
bool bms_equal(const Bitmapset *a, const Bitmapset *b)
Definition bitmapset.c:143
@ PATHKEYS_EQUAL
Definition paths.h:219

References bms_equal(), compare_pathkeys(), fb(), lfirst, NIL, PATH_REQ_OUTER, PATHKEYS_BETTER2, PATHKEYS_EQUAL, STD_FUZZ_FACTOR, and unlikely.

Referenced by add_partial_path_precheck(), try_hashjoin_path(), try_mergejoin_path(), and try_nestloop_path().

◆ adjust_limit_rows_costs()

void adjust_limit_rows_costs ( double *  rows,
Cost *  startup_cost,
Cost *  total_cost,
int64  offset_est,
int64  count_est 
)
extern

Definition at line 3869 of file pathnode.c.

3874{
3875 double input_rows = *rows;
3876 Cost input_startup_cost = *startup_cost;
3877 Cost input_total_cost = *total_cost;
3878
3879 if (offset_est != 0)
3880 {
3881 double offset_rows;
3882
3883 if (offset_est > 0)
3884 offset_rows = (double) offset_est;
3885 else
3887 if (offset_rows > *rows)
3888 offset_rows = *rows;
3889 if (input_rows > 0)
3890 *startup_cost +=
3893 *rows -= offset_rows;
3894 if (*rows < 1)
3895 *rows = 1;
3896 }
3897
3898 if (count_est != 0)
3899 {
3900 double count_rows;
3901
3902 if (count_est > 0)
3903 count_rows = (double) count_est;
3904 else
3906 if (count_rows > *rows)
3907 count_rows = *rows;
3908 if (input_rows > 0)
3909 *total_cost = *startup_cost +
3912 *rows = count_rows;
3913 if (*rows < 1)
3914 *rows = 1;
3915 }
3916}
double clamp_row_est(double nrows)
Definition costsize.c:215
double Cost
Definition nodes.h:259

References clamp_row_est(), and fb().

Referenced by create_limit_path(), and estimate_path_cost_size().

◆ apply_projection_to_path()

Path * apply_projection_to_path ( PlannerInfo *  root,
RelOptInfo *  rel,
Path *  path,
PathTarget *  target 
)
extern

Definition at line 2696 of file pathnode.c.

2700{
2702
2703 /*
2704 * If given path can't project, we might need a Result node, so make a
2705 * separate ProjectionPath.
2706 */
2707 if (!is_projection_capable_path(path))
2708 return (Path *) create_projection_path(root, rel, path, target);
2709
2710 /*
2711 * We can just jam the desired tlist into the existing path, being sure to
2712 * update its cost estimates appropriately.
2713 */
2714 oldcost = path->pathtarget->cost;
2715 path->pathtarget = target;
2716
2717 path->startup_cost += target->cost.startup - oldcost.startup;
2718 path->total_cost += target->cost.startup - oldcost.startup +
2719 (target->cost.per_tuple - oldcost.per_tuple) * path->rows;
2720
2721 /*
2722 * If the path happens to be a Gather or GatherMerge path, we'd like to
2723 * arrange for the subpath to return the required target list so that
2724 * workers can help project. But if there is something that is not
2725 * parallel-safe in the target expressions, then we can't.
2726 */
2727 if ((IsA(path, GatherPath) || IsA(path, GatherMergePath)) &&
2728 is_parallel_safe(root, (Node *) target->exprs))
2729 {
2730 /*
2731 * We always use create_projection_path here, even if the subpath is
2732 * projection-capable, so as to avoid modifying the subpath in place.
2733 * It seems unlikely at present that there could be any other
2734 * references to the subpath, but better safe than sorry.
2735 *
2736 * Note that we don't change the parallel path's cost estimates; it
2737 * might be appropriate to do so, to reflect the fact that the bulk of
2738 * the target evaluation will happen in workers.
2739 */
2740 if (IsA(path, GatherPath))
2741 {
2742 GatherPath *gpath = (GatherPath *) path;
2743
2744 gpath->subpath = (Path *)
2746 gpath->subpath->parent,
2747 gpath->subpath,
2748 target);
2749 }
2750 else
2751 {
2753
2754 gmpath->subpath = (Path *)
2756 gmpath->subpath->parent,
2757 gmpath->subpath,
2758 target);
2759 }
2760 }
2761 else if (path->parallel_safe &&
2762 !is_parallel_safe(root, (Node *) target->exprs))
2763 {
2764 /*
2765 * We're inserting a parallel-restricted target list into a path
2766 * currently marked parallel-safe, so we have to mark it as no longer
2767 * safe.
2768 */
2769 path->parallel_safe = false;
2770 }
2771
2772 return path;
2773}
bool is_parallel_safe(PlannerInfo *root, Node *node)
Definition clauses.c:782
bool is_projection_capable_path(Path *path)
ProjectionPath * create_projection_path(PlannerInfo *root, RelOptInfo *rel, Path *subpath, PathTarget *target)
Definition pathnode.c:2587
tree ctl root
Definition radixtree.h:1857
Path * subpath
Definition pathnodes.h:2372
Definition nodes.h:133
List * exprs
Definition pathnodes.h:1878
QualCost cost
Definition pathnodes.h:1884
Cardinality rows
Definition pathnodes.h:2005
Cost startup_cost
Definition pathnodes.h:2007
Cost total_cost
Definition pathnodes.h:2008
bool parallel_safe
Definition pathnodes.h:2000
Cost per_tuple
Definition pathnodes.h:121
Cost startup
Definition pathnodes.h:120

References PathTarget::cost, create_projection_path(), PathTarget::exprs, fb(), is_parallel_safe(), is_projection_capable_path(), IsA, Path::parallel_safe, QualCost::per_tuple, root, Path::rows, QualCost::startup, Path::startup_cost, and Path::total_cost.

Referenced by adjust_paths_for_srfs(), build_minmax_path(), create_ordered_paths(), and recurse_set_operations().

◆ build_child_join_rel()

RelOptInfo * build_child_join_rel ( PlannerInfo *  root,
RelOptInfo *  outer_rel,
RelOptInfo *  inner_rel,
RelOptInfo *  parent_joinrel,
List *  restrictlist,
SpecialJoinInfo *  sjinfo,
int  nappinfos,
AppendRelInfo **  appinfos 
)
extern

Definition at line 1026 of file relnode.c.

1030{
1031 RelOptInfo *joinrel = makeNode(RelOptInfo);
1032
1033 /* Only joins between "other" relations land here. */
1035
1036 /* The parent joinrel should have consider_partitionwise_join set. */
1037 Assert(parent_joinrel->consider_partitionwise_join);
1038
1040 joinrel->relids = adjust_child_relids(parent_joinrel->relids,
1041 nappinfos, appinfos);
1042 joinrel->rows = 0;
1043 /* cheap startup cost is interesting iff not all tuples to be retrieved */
1044 joinrel->consider_startup = (root->tuple_fraction > 0);
1045 joinrel->consider_param_startup = false;
1046 joinrel->consider_parallel = false;
1047 joinrel->pgs_mask = root->glob->default_pgs_mask;
1049 joinrel->pathlist = NIL;
1050 joinrel->ppilist = NIL;
1051 joinrel->partial_pathlist = NIL;
1052 joinrel->cheapest_startup_path = NULL;
1053 joinrel->cheapest_total_path = NULL;
1055 joinrel->direct_lateral_relids = NULL;
1056 joinrel->lateral_relids = NULL;
1057 joinrel->relid = 0; /* indicates not a baserel */
1058 joinrel->rtekind = RTE_JOIN;
1059 joinrel->min_attr = 0;
1060 joinrel->max_attr = 0;
1061 joinrel->attr_needed = NULL;
1062 joinrel->attr_widths = NULL;
1063 joinrel->notnullattnums = NULL;
1064 joinrel->nulling_relids = NULL;
1065 joinrel->lateral_vars = NIL;
1066 joinrel->lateral_referencers = NULL;
1067 joinrel->indexlist = NIL;
1068 joinrel->pages = 0;
1069 joinrel->tuples = 0;
1070 joinrel->allvisfrac = 0;
1071 joinrel->eclass_indexes = NULL;
1072 joinrel->subroot = NULL;
1073 joinrel->subplan_params = NIL;
1074 joinrel->amflags = 0;
1075 joinrel->serverid = InvalidOid;
1076 joinrel->userid = InvalidOid;
1077 joinrel->useridiscurrent = false;
1078 joinrel->fdwroutine = NULL;
1079 joinrel->fdw_private = NULL;
1080 joinrel->unique_rel = NULL;
1081 joinrel->unique_pathkeys = NIL;
1082 joinrel->unique_groupclause = NIL;
1083 joinrel->baserestrictinfo = NIL;
1084 joinrel->baserestrictcost.startup = 0;
1085 joinrel->baserestrictcost.per_tuple = 0;
1086 joinrel->joininfo = NIL;
1087 joinrel->has_eclass_joins = false;
1088 joinrel->consider_partitionwise_join = false; /* might get changed later */
1089 joinrel->agg_info = NULL;
1090 joinrel->grouped_rel = NULL;
1091 joinrel->parent = parent_joinrel;
1092 joinrel->top_parent = parent_joinrel->top_parent ? parent_joinrel->top_parent : parent_joinrel;
1093 joinrel->top_parent_relids = joinrel->top_parent->relids;
1094 joinrel->part_scheme = NULL;
1095 joinrel->nparts = -1;
1096 joinrel->boundinfo = NULL;
1097 joinrel->partbounds_merged = false;
1098 joinrel->partition_qual = NIL;
1099 joinrel->part_rels = NULL;
1100 joinrel->live_parts = NULL;
1101 joinrel->all_partrels = NULL;
1102 joinrel->partexprs = NULL;
1103 joinrel->nullable_partexprs = NULL;
1104
1105 /* Compute information relevant to foreign relations. */
1107
1108 /* Set up reltarget struct */
1110 nappinfos, appinfos);
1111
1112 /* Construct joininfo list. */
1114 (Node *) parent_joinrel->joininfo,
1115 nappinfos,
1116 appinfos);
1117
1118 /*
1119 * Lateral relids referred in child join will be same as that referred in
1120 * the parent relation.
1121 */
1122 joinrel->direct_lateral_relids = (Relids) bms_copy(parent_joinrel->direct_lateral_relids);
1123 joinrel->lateral_relids = (Relids) bms_copy(parent_joinrel->lateral_relids);
1124
1125 /*
1126 * If the parent joinrel has pending equivalence classes, so does the
1127 * child.
1128 */
1129 joinrel->has_eclass_joins = parent_joinrel->has_eclass_joins;
1130
1131 /* Child joinrel is parallel safe if parent is parallel safe. */
1132 joinrel->consider_parallel = parent_joinrel->consider_parallel;
1133
1134 /* Set estimates of the child-joinrel's size. */
1136 sjinfo, restrictlist);
1137
1138 /*
1139 * Allow a plugin to editorialize on the new joinrel's properties. Actions
1140 * might include altering the size estimate, clearing consider_parallel,
1141 * or adjusting pgs_mask. (However, note that clearing consider_parallel
1142 * would be better done in the parent joinrel rather than here.)
1143 */
1145 (*joinrel_setup_hook) (root, joinrel, outer_rel, inner_rel, sjinfo,
1146 restrictlist);
1147
1148 /* Is the join between partitions itself partitioned? */
1150 restrictlist);
1151
1152 /* We build the join only once. */
1153 Assert(!find_join_rel(root, joinrel->relids));
1154
1155 /* Add the relation to the PlannerInfo. */
1156 add_join_rel(root, joinrel);
1157
1158 /*
1159 * We might need EquivalenceClass members corresponding to the child join,
1160 * so that we can represent sort pathkeys for it. As with children of
1161 * baserels, we shouldn't need this unless there are relevant eclass joins
1162 * (implying that a merge join might be possible) or pathkeys to sort by.
1163 */
1164 if (joinrel->has_eclass_joins || has_useful_pathkeys(root, parent_joinrel))
1166 nappinfos, appinfos,
1167 parent_joinrel, joinrel);
1168
1169 return joinrel;
1170}
Node * adjust_appendrel_attrs(PlannerInfo *root, Node *node, int nappinfos, AppendRelInfo **appinfos)
Definition appendinfo.c:201
Relids adjust_child_relids(Relids relids, int nappinfos, AppendRelInfo **appinfos)
Definition appendinfo.c:630
Bitmapset * bms_copy(const Bitmapset *a)
Definition bitmapset.c:123
void set_joinrel_size_estimates(PlannerInfo *root, RelOptInfo *rel, RelOptInfo *outer_rel, RelOptInfo *inner_rel, SpecialJoinInfo *sjinfo, List *restrictlist)
Definition costsize.c:5595
void add_child_join_rel_equivalences(PlannerInfo *root, int nappinfos, AppendRelInfo **appinfos, RelOptInfo *parent_joinrel, RelOptInfo *child_joinrel)
#define makeNode(_type_)
Definition nodes.h:159
@ RTE_JOIN
bool has_useful_pathkeys(PlannerInfo *root, RelOptInfo *rel)
Definition pathkeys.c:2291
Bitmapset * Relids
Definition pathnodes.h:103
@ RELOPT_OTHER_JOINREL
Definition pathnodes.h:980
#define IS_OTHER_REL(rel)
Definition pathnodes.h:1004
#define InvalidOid
static void build_joinrel_partition_info(PlannerInfo *root, RelOptInfo *joinrel, RelOptInfo *outer_rel, RelOptInfo *inner_rel, SpecialJoinInfo *sjinfo, List *restrictlist)
Definition relnode.c:2150
joinrel_setup_hook_type joinrel_setup_hook
Definition relnode.c:54
RelOptInfo * find_join_rel(PlannerInfo *root, Relids relids)
Definition relnode.c:657
static void build_child_join_reltarget(PlannerInfo *root, RelOptInfo *parentrel, RelOptInfo *childrel, int nappinfos, AppendRelInfo **appinfos)
Definition relnode.c:2662
static void set_foreign_rel_properties(RelOptInfo *joinrel, RelOptInfo *outer_rel, RelOptInfo *inner_rel)
Definition relnode.c:719
static void add_join_rel(PlannerInfo *root, RelOptInfo *joinrel)
Definition relnode.c:757
List * baserestrictinfo
Definition pathnodes.h:1142
bool consider_param_startup
Definition pathnodes.h:1035
List * subplan_params
Definition pathnodes.h:1101
List * ppilist
Definition pathnodes.h:1051
bool useridiscurrent
Definition pathnodes.h:1115
uint32 amflags
Definition pathnodes.h:1105
List * joininfo
Definition pathnodes.h:1148
Bitmapset * notnullattnums
Definition pathnodes.h:1083
List * partition_qual
Definition pathnodes.h:1192
Relids relids
Definition pathnodes.h:1021
struct PathTarget * reltarget
Definition pathnodes.h:1045
Index relid
Definition pathnodes.h:1069
List * lateral_vars
Definition pathnodes.h:1087
struct RelAggInfo * agg_info
Definition pathnodes.h:1162
uint64 pgs_mask
Definition pathnodes.h:1039
List * unique_pathkeys
Definition pathnodes.h:1134
Cardinality tuples
Definition pathnodes.h:1096
bool consider_parallel
Definition pathnodes.h:1037
Relids top_parent_relids
Definition pathnodes.h:1174
bool partbounds_merged
Definition pathnodes.h:1190
BlockNumber pages
Definition pathnodes.h:1095
Relids lateral_relids
Definition pathnodes.h:1064
List * cheapest_parameterized_paths
Definition pathnodes.h:1055
List * pathlist
Definition pathnodes.h:1050
RelOptKind reloptkind
Definition pathnodes.h:1015
List * indexlist
Definition pathnodes.h:1091
Relids lateral_referencers
Definition pathnodes.h:1089
struct Path * cheapest_startup_path
Definition pathnodes.h:1053
QualCost baserestrictcost
Definition pathnodes.h:1144
struct Path * cheapest_total_path
Definition pathnodes.h:1054
List * unique_groupclause
Definition pathnodes.h:1136
struct RelOptInfo * grouped_rel
Definition pathnodes.h:1164
Bitmapset * eclass_indexes
Definition pathnodes.h:1099
Relids all_partrels
Definition pathnodes.h:1206
Relids direct_lateral_relids
Definition pathnodes.h:1062
bool has_eclass_joins
Definition pathnodes.h:1150
bool consider_startup
Definition pathnodes.h:1033
Bitmapset * live_parts
Definition pathnodes.h:1204
bool consider_partitionwise_join
Definition pathnodes.h:1156
List * partial_pathlist
Definition pathnodes.h:1052
PlannerInfo * subroot
Definition pathnodes.h:1100
AttrNumber max_attr
Definition pathnodes.h:1077
Relids nulling_relids
Definition pathnodes.h:1085
double allvisfrac
Definition pathnodes.h:1097
struct RelOptInfo * unique_rel
Definition pathnodes.h:1132
Cardinality rows
Definition pathnodes.h:1027
AttrNumber min_attr
Definition pathnodes.h:1075
RTEKind rtekind
Definition pathnodes.h:1073
PathTarget * create_empty_pathtarget(void)
Definition tlist.c:690

References add_child_join_rel_equivalences(), add_join_rel(), adjust_appendrel_attrs(), adjust_child_relids(), RelOptInfo::agg_info, RelOptInfo::all_partrels, RelOptInfo::allvisfrac, RelOptInfo::amflags, Assert, RelOptInfo::baserestrictcost, RelOptInfo::baserestrictinfo, bms_copy(), build_child_join_reltarget(), build_joinrel_partition_info(), RelOptInfo::cheapest_parameterized_paths, RelOptInfo::cheapest_startup_path, RelOptInfo::cheapest_total_path, RelOptInfo::consider_parallel, RelOptInfo::consider_param_startup, RelOptInfo::consider_partitionwise_join, RelOptInfo::consider_startup, create_empty_pathtarget(), RelOptInfo::direct_lateral_relids, RelOptInfo::eclass_indexes, fb(), find_join_rel(), RelOptInfo::grouped_rel, RelOptInfo::has_eclass_joins, has_useful_pathkeys(), RelOptInfo::indexlist, InvalidOid, IS_OTHER_REL, RelOptInfo::joininfo, joinrel_setup_hook, RelOptInfo::lateral_referencers, RelOptInfo::lateral_relids, RelOptInfo::lateral_vars, RelOptInfo::live_parts, makeNode, RelOptInfo::max_attr, RelOptInfo::min_attr, NIL, RelOptInfo::notnullattnums, RelOptInfo::nparts, RelOptInfo::nulling_relids, RelOptInfo::pages, RelOptInfo::partbounds_merged, RelOptInfo::partial_pathlist, RelOptInfo::partition_qual, RelOptInfo::pathlist, QualCost::per_tuple, RelOptInfo::pgs_mask, RelOptInfo::ppilist, RelOptInfo::relid, RelOptInfo::relids, RELOPT_OTHER_JOINREL, RelOptInfo::reloptkind, RelOptInfo::reltarget, root, RelOptInfo::rows, RTE_JOIN, RelOptInfo::rtekind, RelOptInfo::serverid, set_foreign_rel_properties(), set_joinrel_size_estimates(), QualCost::startup, RelOptInfo::subplan_params, RelOptInfo::subroot, RelOptInfo::top_parent_relids, RelOptInfo::tuples, RelOptInfo::unique_groupclause, RelOptInfo::unique_pathkeys, RelOptInfo::unique_rel, RelOptInfo::userid, and RelOptInfo::useridiscurrent.

Referenced by try_partitionwise_join().

◆ build_grouped_rel()

RelOptInfo * build_grouped_rel ( PlannerInfo *  root,
RelOptInfo *  rel 
)
extern

Definition at line 499 of file relnode.c.

500{
501 RelOptInfo *grouped_rel;
502
503 grouped_rel = makeNode(RelOptInfo);
504 memcpy(grouped_rel, rel, sizeof(RelOptInfo));
505
506 /*
507 * clear path info
508 */
509 grouped_rel->pathlist = NIL;
510 grouped_rel->ppilist = NIL;
511 grouped_rel->partial_pathlist = NIL;
512 grouped_rel->cheapest_startup_path = NULL;
513 grouped_rel->cheapest_total_path = NULL;
514 grouped_rel->cheapest_parameterized_paths = NIL;
515
516 /*
517 * clear partition info
518 */
519 grouped_rel->part_scheme = NULL;
520 grouped_rel->nparts = -1;
521 grouped_rel->boundinfo = NULL;
522 grouped_rel->partbounds_merged = false;
523 grouped_rel->partition_qual = NIL;
524 grouped_rel->part_rels = NULL;
525 grouped_rel->live_parts = NULL;
526 grouped_rel->all_partrels = NULL;
527 grouped_rel->partexprs = NULL;
528 grouped_rel->nullable_partexprs = NULL;
529 grouped_rel->consider_partitionwise_join = false;
530
531 /*
532 * clear size estimates
533 */
534 grouped_rel->rows = 0;
535
536 return grouped_rel;
537}
memcpy(sums, checksumBaseOffsets, sizeof(checksumBaseOffsets))

References RelOptInfo::all_partrels, RelOptInfo::cheapest_parameterized_paths, RelOptInfo::cheapest_startup_path, RelOptInfo::cheapest_total_path, RelOptInfo::consider_partitionwise_join, fb(), RelOptInfo::live_parts, makeNode, memcpy(), NIL, RelOptInfo::nparts, RelOptInfo::partbounds_merged, RelOptInfo::partial_pathlist, RelOptInfo::partition_qual, RelOptInfo::pathlist, RelOptInfo::ppilist, and RelOptInfo::rows.

Referenced by build_simple_grouped_rel(), and make_grouped_join_rel().

◆ build_join_rel()

RelOptInfo * build_join_rel ( PlannerInfo *  root,
Relids  joinrelids,
RelOptInfo *  outer_rel,
RelOptInfo *  inner_rel,
SpecialJoinInfo *  sjinfo,
List *  pushed_down_joins,
List **  restrictlist_ptr 
)
extern

Definition at line 795 of file relnode.c.

802{
803 RelOptInfo *joinrel;
804 List *restrictlist;
805
806 /* This function should be used only for join between parents. */
808
809 /*
810 * See if we already have a joinrel for this set of base rels.
811 */
812 joinrel = find_join_rel(root, joinrelids);
813
814 if (joinrel)
815 {
816 /*
817 * Yes, so we only need to figure the restrictlist for this particular
818 * pair of component relations.
819 */
822 joinrel,
823 outer_rel,
824 inner_rel,
825 sjinfo);
826 return joinrel;
827 }
828
829 /*
830 * Nope, so make one.
831 */
832 joinrel = makeNode(RelOptInfo);
833 joinrel->reloptkind = RELOPT_JOINREL;
834 joinrel->relids = bms_copy(joinrelids);
835 joinrel->rows = 0;
836 /* cheap startup cost is interesting iff not all tuples to be retrieved */
837 joinrel->consider_startup = (root->tuple_fraction > 0);
838 joinrel->consider_param_startup = false;
839 joinrel->consider_parallel = false;
840 joinrel->pgs_mask = root->glob->default_pgs_mask;
842 joinrel->pathlist = NIL;
843 joinrel->ppilist = NIL;
844 joinrel->partial_pathlist = NIL;
845 joinrel->cheapest_startup_path = NULL;
846 joinrel->cheapest_total_path = NULL;
848 /* init direct_lateral_relids from children; we'll finish it up below */
849 joinrel->direct_lateral_relids =
850 bms_union(outer_rel->direct_lateral_relids,
851 inner_rel->direct_lateral_relids);
854 joinrel->relid = 0; /* indicates not a baserel */
855 joinrel->rtekind = RTE_JOIN;
856 joinrel->min_attr = 0;
857 joinrel->max_attr = 0;
858 joinrel->attr_needed = NULL;
859 joinrel->attr_widths = NULL;
860 joinrel->notnullattnums = NULL;
861 joinrel->nulling_relids = NULL;
862 joinrel->lateral_vars = NIL;
863 joinrel->lateral_referencers = NULL;
864 joinrel->indexlist = NIL;
865 joinrel->statlist = NIL;
866 joinrel->pages = 0;
867 joinrel->tuples = 0;
868 joinrel->allvisfrac = 0;
869 joinrel->eclass_indexes = NULL;
870 joinrel->subroot = NULL;
871 joinrel->subplan_params = NIL;
872 joinrel->rel_parallel_workers = -1;
873 joinrel->amflags = 0;
874 joinrel->serverid = InvalidOid;
875 joinrel->userid = InvalidOid;
876 joinrel->useridiscurrent = false;
877 joinrel->fdwroutine = NULL;
878 joinrel->fdw_private = NULL;
879 joinrel->unique_for_rels = NIL;
880 joinrel->non_unique_for_rels = NIL;
881 joinrel->unique_rel = NULL;
882 joinrel->unique_pathkeys = NIL;
883 joinrel->unique_groupclause = NIL;
884 joinrel->baserestrictinfo = NIL;
885 joinrel->baserestrictcost.startup = 0;
886 joinrel->baserestrictcost.per_tuple = 0;
888 joinrel->joininfo = NIL;
889 joinrel->has_eclass_joins = false;
890 joinrel->consider_partitionwise_join = false; /* might get changed later */
891 joinrel->agg_info = NULL;
892 joinrel->grouped_rel = NULL;
893 joinrel->parent = NULL;
894 joinrel->top_parent = NULL;
895 joinrel->top_parent_relids = NULL;
896 joinrel->part_scheme = NULL;
897 joinrel->nparts = -1;
898 joinrel->boundinfo = NULL;
899 joinrel->partbounds_merged = false;
900 joinrel->partition_qual = NIL;
901 joinrel->part_rels = NULL;
902 joinrel->live_parts = NULL;
903 joinrel->all_partrels = NULL;
904 joinrel->partexprs = NULL;
905 joinrel->nullable_partexprs = NULL;
906
907 /* Compute information relevant to the foreign relations. */
909
910 /*
911 * Fill the joinrel's tlist with just the Vars and PHVs that need to be
912 * output from this join (ie, are needed for higher joinclauses or final
913 * output).
914 *
915 * NOTE: the tlist order for a join rel will depend on which pair of outer
916 * and inner rels we first try to build it from. But the contents should
917 * be the same regardless.
918 */
920 (sjinfo->jointype == JOIN_FULL));
922 (sjinfo->jointype != JOIN_INNER));
924
925 /*
926 * add_placeholders_to_joinrel also took care of adding the ph_lateral
927 * sets of any PlaceHolderVars computed here to direct_lateral_relids, so
928 * now we can finish computing that. This is much like the computation of
929 * the transitively-closed lateral_relids in min_join_parameterization,
930 * except that here we *do* have to consider the added PHVs.
931 */
932 joinrel->direct_lateral_relids =
933 bms_del_members(joinrel->direct_lateral_relids, joinrel->relids);
934
935 /*
936 * Construct restrict and join clause lists for the new joinrel. (The
937 * caller might or might not need the restrictlist, but I need it anyway
938 * for set_joinrel_size_estimates().)
939 */
940 restrictlist = build_joinrel_restrictlist(root, joinrel,
942 sjinfo);
944 *restrictlist_ptr = restrictlist;
946
947 /*
948 * This is also the right place to check whether the joinrel has any
949 * pending EquivalenceClass joins.
950 */
952
953 /*
954 * Set estimates of the joinrel's size.
955 */
957 sjinfo, restrictlist);
958
959 /*
960 * Set the consider_parallel flag if this joinrel could potentially be
961 * scanned within a parallel worker. If this flag is false for either
962 * inner_rel or outer_rel, then it must be false for the joinrel also.
963 * Even if both are true, there might be parallel-restricted expressions
964 * in the targetlist or quals.
965 *
966 * Note that if there are more than two rels in this relation, they could
967 * be divided between inner_rel and outer_rel in any arbitrary way. We
968 * assume this doesn't matter, because we should hit all the same baserels
969 * and joinclauses while building up to this joinrel no matter which we
970 * take; therefore, we should make the same decision here however we get
971 * here.
972 */
973 if (inner_rel->consider_parallel && outer_rel->consider_parallel &&
974 is_parallel_safe(root, (Node *) restrictlist) &&
975 is_parallel_safe(root, (Node *) joinrel->reltarget->exprs))
976 joinrel->consider_parallel = true;
977
978 /*
979 * Allow a plugin to editorialize on the new joinrel's properties. Actions
980 * might include altering the size estimate, clearing consider_parallel,
981 * or adjusting pgs_mask.
982 */
984 (*joinrel_setup_hook) (root, joinrel, outer_rel, inner_rel, sjinfo,
985 restrictlist);
986
987 /* Store the partition information. */
989 restrictlist);
990
991 /* Add the joinrel to the PlannerInfo. */
992 add_join_rel(root, joinrel);
993
994 /*
995 * Also, if dynamic-programming join search is active, add the new joinrel
996 * to the appropriate sublist. Note: you might think the Assert on number
997 * of members should be for equality, but some of the level 1 rels might
998 * have been joinrels already, so we can only assert <=.
999 */
1000 if (root->join_rel_level)
1001 {
1002 Assert(root->join_cur_level > 0);
1003 Assert(root->join_cur_level <= bms_num_members(joinrel->relids));
1004 root->join_rel_level[root->join_cur_level] =
1005 lappend(root->join_rel_level[root->join_cur_level], joinrel);
1006 }
1007
1008 return joinrel;
1009}
Bitmapset * bms_del_members(Bitmapset *a, const Bitmapset *b)
Definition bitmapset.c:1280
int bms_num_members(const Bitmapset *a)
Definition bitmapset.c:879
Bitmapset * bms_union(const Bitmapset *a, const Bitmapset *b)
Definition bitmapset.c:252
bool has_relevant_eclass_joinclause(PlannerInfo *root, RelOptInfo *rel1)
List * lappend(List *list, void *datum)
Definition list.c:339
@ JOIN_FULL
Definition nodes.h:303
@ JOIN_INNER
Definition nodes.h:301
@ RELOPT_JOINREL
Definition pathnodes.h:978
void add_placeholders_to_joinrel(PlannerInfo *root, RelOptInfo *joinrel, RelOptInfo *outer_rel, RelOptInfo *inner_rel, SpecialJoinInfo *sjinfo)
static void build_joinrel_tlist(PlannerInfo *root, RelOptInfo *joinrel, RelOptInfo *input_rel, SpecialJoinInfo *sjinfo, List *pushed_down_joins, bool can_null)
Definition relnode.c:1259
Relids min_join_parameterization(PlannerInfo *root, Relids joinrelids, RelOptInfo *outer_rel, RelOptInfo *inner_rel)
Definition relnode.c:1181
static List * build_joinrel_restrictlist(PlannerInfo *root, RelOptInfo *joinrel, RelOptInfo *outer_rel, RelOptInfo *inner_rel, SpecialJoinInfo *sjinfo)
Definition relnode.c:1444
static void build_joinrel_joinlist(RelOptInfo *joinrel, RelOptInfo *outer_rel, RelOptInfo *inner_rel)
Definition relnode.c:1481
List * statlist
Definition pathnodes.h:1093
List * unique_for_rels
Definition pathnodes.h:1124
List * non_unique_for_rels
Definition pathnodes.h:1126
int rel_parallel_workers
Definition pathnodes.h:1103
Index baserestrict_min_security
Definition pathnodes.h:1146
JoinType jointype
Definition pathnodes.h:3230

References add_join_rel(), add_placeholders_to_joinrel(), RelOptInfo::agg_info, RelOptInfo::all_partrels, RelOptInfo::allvisfrac, RelOptInfo::amflags, Assert, RelOptInfo::baserestrict_min_security, RelOptInfo::baserestrictcost, RelOptInfo::baserestrictinfo, bms_copy(), bms_del_members(), bms_num_members(), bms_union(), build_joinrel_joinlist(), build_joinrel_partition_info(), build_joinrel_restrictlist(), build_joinrel_tlist(), RelOptInfo::cheapest_parameterized_paths, RelOptInfo::cheapest_startup_path, RelOptInfo::cheapest_total_path, RelOptInfo::consider_parallel, RelOptInfo::consider_param_startup, RelOptInfo::consider_partitionwise_join, RelOptInfo::consider_startup, create_empty_pathtarget(), RelOptInfo::direct_lateral_relids, RelOptInfo::eclass_indexes, PathTarget::exprs, fb(), find_join_rel(), RelOptInfo::grouped_rel, RelOptInfo::has_eclass_joins, has_relevant_eclass_joinclause(), RelOptInfo::indexlist, InvalidOid, IS_OTHER_REL, is_parallel_safe(), JOIN_FULL, JOIN_INNER, RelOptInfo::joininfo, joinrel_setup_hook, SpecialJoinInfo::jointype, lappend(), RelOptInfo::lateral_referencers, RelOptInfo::lateral_relids, RelOptInfo::lateral_vars, RelOptInfo::live_parts, makeNode, RelOptInfo::max_attr, RelOptInfo::min_attr, min_join_parameterization(), NIL, RelOptInfo::non_unique_for_rels, RelOptInfo::notnullattnums, RelOptInfo::nparts, RelOptInfo::nulling_relids, RelOptInfo::pages, RelOptInfo::partbounds_merged, RelOptInfo::partial_pathlist, RelOptInfo::partition_qual, RelOptInfo::pathlist, QualCost::per_tuple, RelOptInfo::pgs_mask, RelOptInfo::ppilist, RelOptInfo::rel_parallel_workers, RelOptInfo::relid, RelOptInfo::relids, RELOPT_JOINREL, RelOptInfo::reloptkind, RelOptInfo::reltarget, root, RelOptInfo::rows, RTE_JOIN, RelOptInfo::rtekind, RelOptInfo::serverid, set_foreign_rel_properties(), set_joinrel_size_estimates(), QualCost::startup, RelOptInfo::statlist, RelOptInfo::subplan_params, RelOptInfo::subroot, RelOptInfo::top_parent_relids, RelOptInfo::tuples, RelOptInfo::unique_for_rels, RelOptInfo::unique_groupclause, RelOptInfo::unique_pathkeys, RelOptInfo::unique_rel, RelOptInfo::userid, and RelOptInfo::useridiscurrent.

Referenced by make_join_rel().

◆ build_simple_grouped_rel()

RelOptInfo * build_simple_grouped_rel ( PlannerInfo *  root,
RelOptInfo *  rel 
)
extern

Definition at line 448 of file relnode.c.

449{
450 RelOptInfo *grouped_rel;
451 RelAggInfo *agg_info;
452
453 /*
454 * We should have available aggregate expressions and grouping
455 * expressions, otherwise we cannot reach here.
456 */
457 Assert(root->agg_clause_list != NIL);
458 Assert(root->group_expr_list != NIL);
459
460 /* nothing to do for dummy rel */
461 if (IS_DUMMY_REL(rel))
462 return NULL;
463
464 /*
465 * Prepare the information needed to create grouped paths for this simple
466 * relation.
467 */
468 agg_info = create_rel_agg_info(root, rel, true);
469 if (agg_info == NULL)
470 return NULL;
471
472 /*
473 * If grouped paths for the given simple relation are not considered
474 * useful, skip building the grouped relation.
475 */
476 if (!agg_info->agg_useful)
477 return NULL;
478
479 /* Track the set of relids at which partial aggregation is applied */
480 agg_info->apply_agg_at = bms_copy(rel->relids);
481
482 /* build the grouped relation */
483 grouped_rel = build_grouped_rel(root, rel);
484 grouped_rel->reltarget = agg_info->target;
485 grouped_rel->rows = agg_info->grouped_rows;
486 grouped_rel->agg_info = agg_info;
487
488 rel->grouped_rel = grouped_rel;
489
490 return grouped_rel;
491}
#define IS_DUMMY_REL(r)
Definition pathnodes.h:2299
RelOptInfo * build_grouped_rel(PlannerInfo *root, RelOptInfo *rel)
Definition relnode.c:499
RelAggInfo * create_rel_agg_info(PlannerInfo *root, RelOptInfo *rel, bool calculate_grouped_rows)
Definition relnode.c:2691
Relids apply_agg_at
Definition pathnodes.h:1302
bool agg_useful
Definition pathnodes.h:1308
Cardinality grouped_rows
Definition pathnodes.h:1305
struct PathTarget * target
Definition pathnodes.h:1291

References RelOptInfo::agg_info, RelAggInfo::agg_useful, RelAggInfo::apply_agg_at, Assert, bms_copy(), build_grouped_rel(), create_rel_agg_info(), fb(), RelOptInfo::grouped_rel, RelAggInfo::grouped_rows, IS_DUMMY_REL, NIL, RelOptInfo::relids, RelOptInfo::reltarget, root, RelOptInfo::rows, and RelAggInfo::target.

Referenced by setup_simple_grouped_rels().

◆ build_simple_rel()

RelOptInfo * build_simple_rel ( PlannerInfo *  root,
int  relid,
RelOptInfo *  parent 
)
extern

Definition at line 212 of file relnode.c.

213{
214 RelOptInfo *rel;
216
217 /* Rel should not exist already */
218 Assert(relid > 0 && relid < root->simple_rel_array_size);
219 if (root->simple_rel_array[relid] != NULL)
220 elog(ERROR, "rel %d already exists", relid);
221
222 /* Fetch RTE for relation */
223 rte = root->simple_rte_array[relid];
224 Assert(rte != NULL);
225
226 rel = makeNode(RelOptInfo);
228 rel->relids = bms_make_singleton(relid);
229 rel->rows = 0;
230 /* cheap startup cost is interesting iff not all tuples to be retrieved */
231 rel->consider_startup = (root->tuple_fraction > 0);
232 rel->consider_param_startup = false; /* might get changed later */
233 rel->consider_parallel = false; /* might get changed later */
234 rel->pgs_mask = root->glob->default_pgs_mask;
236 rel->pathlist = NIL;
237 rel->ppilist = NIL;
238 rel->partial_pathlist = NIL;
242 rel->relid = relid;
243 rel->rtekind = rte->rtekind;
244 /* min_attr, max_attr, attr_needed, attr_widths are set below */
245 rel->notnullattnums = NULL;
246 rel->lateral_vars = NIL;
247 rel->indexlist = NIL;
248 rel->statlist = NIL;
249 rel->pages = 0;
250 rel->tuples = 0;
251 rel->allvisfrac = 0;
252 rel->eclass_indexes = NULL;
253 rel->subroot = NULL;
254 rel->subplan_params = NIL;
255 rel->rel_parallel_workers = -1; /* set up in get_relation_info */
256 rel->amflags = 0;
257 rel->serverid = InvalidOid;
258 if (rte->rtekind == RTE_RELATION)
259 {
260 Assert(parent == NULL ||
261 parent->rtekind == RTE_RELATION ||
262 parent->rtekind == RTE_SUBQUERY);
263
264 /*
265 * For any RELATION rte, we need a userid with which to check
266 * permission access. Baserels simply use their own
267 * RTEPermissionInfo's checkAsUser.
268 *
269 * For otherrels normally there's no RTEPermissionInfo, so we use the
270 * parent's, which normally has one. The exceptional case is that the
271 * parent is a subquery, in which case the otherrel will have its own.
272 */
273 if (rel->reloptkind == RELOPT_BASEREL ||
275 parent->rtekind == RTE_SUBQUERY))
276 {
278
279 perminfo = getRTEPermissionInfo(root->parse->rteperminfos, rte);
280 rel->userid = perminfo->checkAsUser;
281 }
282 else
283 rel->userid = parent->userid;
284 }
285 else
286 rel->userid = InvalidOid;
287 rel->useridiscurrent = false;
288 rel->fdwroutine = NULL;
289 rel->fdw_private = NULL;
290 rel->unique_for_rels = NIL;
292 rel->unique_rel = NULL;
293 rel->unique_pathkeys = NIL;
294 rel->unique_groupclause = NIL;
295 rel->baserestrictinfo = NIL;
296 rel->baserestrictcost.startup = 0;
299 rel->joininfo = NIL;
300 rel->has_eclass_joins = false;
301 rel->consider_partitionwise_join = false; /* might get changed later */
302 rel->agg_info = NULL;
303 rel->grouped_rel = NULL;
304 rel->part_scheme = NULL;
305 rel->nparts = -1;
306 rel->boundinfo = NULL;
307 rel->partbounds_merged = false;
308 rel->partition_qual = NIL;
309 rel->part_rels = NULL;
310 rel->live_parts = NULL;
311 rel->all_partrels = NULL;
312 rel->partexprs = NULL;
313 rel->nullable_partexprs = NULL;
314
315 /*
316 * Pass assorted information down the inheritance hierarchy.
317 */
318 if (parent)
319 {
320 /* We keep back-links to immediate parent and topmost parent. */
321 rel->parent = parent;
322 rel->top_parent = parent->top_parent ? parent->top_parent : parent;
323 rel->top_parent_relids = rel->top_parent->relids;
324
325 /*
326 * A child rel is below the same outer joins as its parent. (We
327 * presume this info was already calculated for the parent.)
328 */
329 rel->nulling_relids = parent->nulling_relids;
330
331 /*
332 * Also propagate lateral-reference information from appendrel parent
333 * rels to their child rels. We intentionally give each child rel the
334 * same minimum parameterization, even though it's quite possible that
335 * some don't reference all the lateral rels. This is because any
336 * append path for the parent will have to have the same
337 * parameterization for every child anyway, and there's no value in
338 * forcing extra reparameterize_path() calls. Similarly, a lateral
339 * reference to the parent prevents use of otherwise-movable join rels
340 * for each child.
341 *
342 * It's possible for child rels to have their own children, in which
343 * case the topmost parent's lateral info propagates all the way down.
344 */
346 rel->lateral_relids = parent->lateral_relids;
348 }
349 else
350 {
351 rel->parent = NULL;
352 rel->top_parent = NULL;
353 rel->top_parent_relids = NULL;
354 rel->nulling_relids = NULL;
356 rel->lateral_relids = NULL;
358 }
359
360 /* Check type of rtable entry */
361 switch (rte->rtekind)
362 {
363 case RTE_RELATION:
364 /* Table --- retrieve statistics from the system catalogs */
365 get_relation_info(root, rte->relid, rte->inh, rel);
366 break;
367 case RTE_SUBQUERY:
368 case RTE_FUNCTION:
369 case RTE_TABLEFUNC:
370 case RTE_VALUES:
371 case RTE_CTE:
373
374 /*
375 * Subquery, function, tablefunc, values list, CTE, or ENR --- set
376 * up attr range and arrays
377 *
378 * Note: 0 is included in range to support whole-row Vars
379 */
380 rel->min_attr = 0;
381 rel->max_attr = list_length(rte->eref->colnames);
382 rel->attr_needed = (Relids *)
383 palloc0_array(Relids, rel->max_attr - rel->min_attr + 1);
384 rel->attr_widths = (int32 *)
385 palloc0_array(int32, rel->max_attr - rel->min_attr + 1);
386 break;
387 case RTE_RESULT:
388 /* RTE_RESULT has no columns, nor could it have whole-row Var */
389 rel->min_attr = 0;
390 rel->max_attr = -1;
391 rel->attr_needed = NULL;
392 rel->attr_widths = NULL;
393 break;
394 default:
395 elog(ERROR, "unrecognized RTE kind: %d",
396 (int) rte->rtekind);
397 break;
398 }
399
400 /*
401 * Allow a plugin to editorialize on the new RelOptInfo. This could
402 * involve editorializing on the information which get_relation_info
403 * obtained from the catalogs, such as altering the assumed relation size,
404 * removing an index, or adding a hypothetical index to the indexlist.
405 *
406 * An extension can also modify rel->pgs_mask here to control path
407 * generation.
408 */
410 (*build_simple_rel_hook) (root, rel, rte);
411
412 /*
413 * Apply the parent's quals to the child, with appropriate substitution of
414 * variables. If any resulting clause is reduced to constant FALSE or
415 * NULL, apply_child_basequals returns false to indicate that scanning
416 * this relation won't yield any rows. In this case, we mark the child as
417 * dummy right away. (We must do this immediately so that pruning works
418 * correctly when recursing in expand_partitioned_rtentry.)
419 */
420 if (parent)
421 {
422 AppendRelInfo *appinfo = root->append_rel_array[relid];
423
424 Assert(appinfo != NULL);
425 if (!apply_child_basequals(root, parent, rel, rte, appinfo))
426 {
427 /*
428 * A restriction clause reduced to constant FALSE or NULL after
429 * substitution. Mark the child as dummy so that it need not be
430 * scanned.
431 */
432 mark_dummy_rel(rel);
433 }
434 }
435
436 /* Save the finished struct in the query's simple_rel_array */
437 root->simple_rel_array[relid] = rel;
438
439 return rel;
440}
Bitmapset * bms_make_singleton(int x)
Definition bitmapset.c:217
int32_t int32
Definition c.h:679
#define ERROR
Definition elog.h:40
#define elog(elevel,...)
Definition elog.h:228
#define palloc0_array(type, count)
Definition fe_memutils.h:92
bool apply_child_basequals(PlannerInfo *root, RelOptInfo *parentrel, RelOptInfo *childrel, RangeTblEntry *childRTE, AppendRelInfo *appinfo)
Definition inherit.c:839
void mark_dummy_rel(RelOptInfo *rel)
Definition joinrels.c:1513
RTEPermissionInfo * getRTEPermissionInfo(List *rteperminfos, RangeTblEntry *rte)
@ RTE_CTE
@ RTE_NAMEDTUPLESTORE
@ RTE_VALUES
@ RTE_SUBQUERY
@ RTE_RESULT
@ RTE_FUNCTION
@ RTE_TABLEFUNC
@ RTE_RELATION
@ RELOPT_BASEREL
Definition pathnodes.h:977
@ RELOPT_OTHER_MEMBER_REL
Definition pathnodes.h:979
static int list_length(const List *l)
Definition pg_list.h:152
void get_relation_info(PlannerInfo *root, Oid relationObjectId, bool inhparent, RelOptInfo *rel)
Definition plancat.c:121
build_simple_rel_hook_type build_simple_rel_hook
Definition relnode.c:51

References RelOptInfo::agg_info, RelOptInfo::all_partrels, RelOptInfo::allvisfrac, RelOptInfo::amflags, apply_child_basequals(), Assert, RelOptInfo::baserestrict_min_security, RelOptInfo::baserestrictcost, RelOptInfo::baserestrictinfo, bms_make_singleton(), build_simple_rel_hook, RelOptInfo::cheapest_parameterized_paths, RelOptInfo::cheapest_startup_path, RelOptInfo::cheapest_total_path, RelOptInfo::consider_parallel, RelOptInfo::consider_param_startup, RelOptInfo::consider_partitionwise_join, RelOptInfo::consider_startup, create_empty_pathtarget(), RelOptInfo::direct_lateral_relids, RelOptInfo::eclass_indexes, elog, ERROR, fb(), get_relation_info(), getRTEPermissionInfo(), RelOptInfo::grouped_rel, RelOptInfo::has_eclass_joins, RelOptInfo::indexlist, InvalidOid, RelOptInfo::joininfo, RelOptInfo::lateral_referencers, RelOptInfo::lateral_relids, RelOptInfo::lateral_vars, list_length(), RelOptInfo::live_parts, makeNode, mark_dummy_rel(), RelOptInfo::max_attr, RelOptInfo::min_attr, NIL, RelOptInfo::non_unique_for_rels, RelOptInfo::notnullattnums, RelOptInfo::nparts, RelOptInfo::nulling_relids, RelOptInfo::pages, palloc0_array, RelOptInfo::partbounds_merged, RelOptInfo::partial_pathlist, RelOptInfo::partition_qual, RelOptInfo::pathlist, QualCost::per_tuple, RelOptInfo::pgs_mask, RelOptInfo::ppilist, RelOptInfo::rel_parallel_workers, RelOptInfo::relid, RelOptInfo::relids, RELOPT_BASEREL, RELOPT_OTHER_MEMBER_REL, RelOptInfo::reloptkind, RelOptInfo::reltarget, root, RelOptInfo::rows, RTE_CTE, RTE_FUNCTION, RTE_NAMEDTUPLESTORE, RTE_RELATION, RTE_RESULT, RTE_SUBQUERY, RTE_TABLEFUNC, RTE_VALUES, RelOptInfo::rtekind, RelOptInfo::serverid, QualCost::startup, RelOptInfo::statlist, RelOptInfo::subplan_params, RelOptInfo::subroot, RelOptInfo::top_parent_relids, RelOptInfo::tuples, RelOptInfo::unique_for_rels, RelOptInfo::unique_groupclause, RelOptInfo::unique_pathkeys, RelOptInfo::unique_rel, RelOptInfo::userid, and RelOptInfo::useridiscurrent.

Referenced by add_base_rels_to_query(), expand_appendrel_subquery(), expand_inherited_rtentry(), expand_partitioned_rtentry(), plan_cluster_use_sort(), plan_create_index_workers(), query_planner(), and recurse_set_operations().

◆ calc_nestloop_required_outer()

Relids calc_nestloop_required_outer ( Relids  outerrelids,
Relids  outer_paramrels,
Relids  innerrelids,
Relids  inner_paramrels 
)
extern

Definition at line 2277 of file pathnode.c.

2281{
2283
2284 /* inner_path can require rels from outer path, but not vice versa */
2286 /* easy case if inner path is not parameterized */
2287 if (!inner_paramrels)
2288 return bms_copy(outer_paramrels);
2289 /* else, form the union ... */
2291 /* ... and remove any mention of now-satisfied outer rels */
2293 outerrelids);
2294 return required_outer;
2295}
bool bms_overlap(const Bitmapset *a, const Bitmapset *b)
Definition bitmapset.c:710

References Assert, bms_copy(), bms_del_members(), bms_overlap(), bms_union(), and fb().

Referenced by try_nestloop_path().

◆ calc_non_nestloop_required_outer()

Relids calc_non_nestloop_required_outer ( Path *  outer_path,
Path *  inner_path 
)
extern

Definition at line 2304 of file pathnode.c.

2305{
2309 Relids outerrelids PG_USED_FOR_ASSERTS_ONLY;
2311
2312 /*
2313 * Any parameterization of the input paths refers to topmost parents of
2314 * the relevant relations, because reparameterize_path_by_child() hasn't
2315 * been called yet. So we must consider topmost parents of the relations
2316 * being joined, too, while checking for disallowed parameterization
2317 * cases.
2318 */
2319 if (inner_path->parent->top_parent_relids)
2320 innerrelids = inner_path->parent->top_parent_relids;
2321 else
2322 innerrelids = inner_path->parent->relids;
2323
2324 if (outer_path->parent->top_parent_relids)
2325 outerrelids = outer_path->parent->top_parent_relids;
2326 else
2327 outerrelids = outer_path->parent->relids;
2328
2329 /* neither path can require rels from the other */
2331 Assert(!bms_overlap(inner_paramrels, outerrelids));
2332 /* form the union ... */
2334 /* we do not need an explicit test for empty; bms_union gets it right */
2335 return required_outer;
2336}
#define PG_USED_FOR_ASSERTS_ONLY
Definition c.h:308

References Assert, bms_overlap(), bms_union(), fb(), PATH_REQ_OUTER, and PG_USED_FOR_ASSERTS_ONLY.

Referenced by try_hashjoin_path(), and try_mergejoin_path().

◆ compare_fractional_path_costs()

int compare_fractional_path_costs ( Path *  path1,
Path *  path2,
double  fraction 
)
extern

Definition at line 123 of file pathnode.c.

125{
126 Cost cost1,
127 cost2;
128
129 /* Number of disabled nodes, if different, trumps all else. */
130 if (unlikely(path1->disabled_nodes != path2->disabled_nodes))
131 {
132 if (path1->disabled_nodes < path2->disabled_nodes)
133 return -1;
134 else
135 return +1;
136 }
137
140 cost1 = path1->startup_cost +
141 fraction * (path1->total_cost - path1->startup_cost);
142 cost2 = path2->startup_cost +
143 fraction * (path2->total_cost - path2->startup_cost);
144 if (cost1 < cost2)
145 return -1;
146 if (cost1 > cost2)
147 return +1;
148 return 0;
149}
int compare_path_costs(Path *path1, Path *path2, CostSelector criterion)
Definition pathnode.c:68
@ TOTAL_COST
Definition pathnodes.h:111

References compare_path_costs(), fb(), TOTAL_COST, and unlikely.

Referenced by get_cheapest_fractional_path(), and get_cheapest_fractional_path_for_pathkeys().

◆ compare_path_costs()

int compare_path_costs ( Path *  path1,
Path *  path2,
CostSelector  criterion 
)
extern

Definition at line 68 of file pathnode.c.

69{
70 /* Number of disabled nodes, if different, trumps all else. */
71 if (unlikely(path1->disabled_nodes != path2->disabled_nodes))
72 {
73 if (path1->disabled_nodes < path2->disabled_nodes)
74 return -1;
75 else
76 return +1;
77 }
78
80 {
81 if (path1->startup_cost < path2->startup_cost)
82 return -1;
83 if (path1->startup_cost > path2->startup_cost)
84 return +1;
85
86 /*
87 * If paths have the same startup cost (not at all unlikely), order
88 * them by total cost.
89 */
90 if (path1->total_cost < path2->total_cost)
91 return -1;
92 if (path1->total_cost > path2->total_cost)
93 return +1;
94 }
95 else
96 {
97 if (path1->total_cost < path2->total_cost)
98 return -1;
99 if (path1->total_cost > path2->total_cost)
100 return +1;
101
102 /*
103 * If paths have the same total cost, order them by startup cost.
104 */
105 if (path1->startup_cost < path2->startup_cost)
106 return -1;
107 if (path1->startup_cost > path2->startup_cost)
108 return +1;
109 }
110 return 0;
111}
@ STARTUP_COST
Definition pathnodes.h:111

References fb(), STARTUP_COST, and unlikely.

Referenced by append_startup_cost_compare(), append_total_cost_compare(), compare_fractional_path_costs(), generate_mergejoin_paths(), get_cheapest_parameterized_child_path(), get_cheapest_path_for_pathkeys(), and set_cheapest().

◆ create_agg_path()

AggPath * create_agg_path ( PlannerInfo *  root,
RelOptInfo *  rel,
Path *  subpath,
PathTarget *  target,
AggStrategy  aggstrategy,
AggSplit  aggsplit,
List *  groupClause,
List *  qual,
const AggClauseCosts *  aggcosts,
double  numGroups 
)
extern

Definition at line 3067 of file pathnode.c.

3077{
3079
3080 pathnode->path.pathtype = T_Agg;
3081 pathnode->path.parent = rel;
3082 pathnode->path.pathtarget = target;
3083 pathnode->path.param_info = subpath->param_info;
3084 pathnode->path.parallel_aware = false;
3085 pathnode->path.parallel_safe = rel->consider_parallel &&
3086 subpath->parallel_safe;
3087 pathnode->path.parallel_workers = subpath->parallel_workers;
3088
3089 if (aggstrategy == AGG_SORTED)
3090 {
3091 /*
3092 * Attempt to preserve the order of the subpath. Additional pathkeys
3093 * may have been added in adjust_group_pathkeys_for_groupagg() to
3094 * support ORDER BY / DISTINCT aggregates. Pathkeys added there
3095 * belong to columns within the aggregate function, so we must strip
3096 * these additional pathkeys off as those columns are unavailable
3097 * above the aggregate node.
3098 */
3099 if (list_length(subpath->pathkeys) > root->num_groupby_pathkeys)
3100 pathnode->path.pathkeys = list_copy_head(subpath->pathkeys,
3101 root->num_groupby_pathkeys);
3102 else
3103 pathnode->path.pathkeys = subpath->pathkeys; /* preserves order */
3104 }
3105 else
3106 pathnode->path.pathkeys = NIL; /* output is unordered */
3107
3108 pathnode->subpath = subpath;
3109
3110 pathnode->aggstrategy = aggstrategy;
3111 pathnode->aggsplit = aggsplit;
3112 pathnode->numGroups = numGroups;
3113 pathnode->transitionSpace = aggcosts ? aggcosts->transitionSpace : 0;
3114 pathnode->groupClause = groupClause;
3115 pathnode->qual = qual;
3116
3117 cost_agg(&pathnode->path, root,
3118 aggstrategy, aggcosts,
3119 list_length(groupClause), numGroups,
3120 qual,
3121 subpath->disabled_nodes,
3122 subpath->startup_cost, subpath->total_cost,
3123 subpath->rows, subpath->pathtarget->width);
3124
3125 /* add tlist eval cost for each output row */
3126 pathnode->path.startup_cost += target->cost.startup;
3127 pathnode->path.total_cost += target->cost.startup +
3128 target->cost.per_tuple * pathnode->path.rows;
3129
3130 return pathnode;
3131}
void cost_agg(Path *path, PlannerInfo *root, AggStrategy aggstrategy, const AggClauseCosts *aggcosts, int numGroupCols, double numGroups, List *quals, int disabled_nodes, Cost input_startup_cost, Cost input_total_cost, double input_tuples, double input_width)
Definition costsize.c:2789
List * list_copy_head(const List *oldlist, int len)
Definition list.c:1593
Datum subpath(PG_FUNCTION_ARGS)
Definition ltree_op.c:348
@ AGG_SORTED
Definition nodes.h:363

References AGG_SORTED, RelOptInfo::consider_parallel, PathTarget::cost, cost_agg(), fb(), list_copy_head(), list_length(), makeNode, NIL, QualCost::per_tuple, root, QualCost::startup, and subpath().

Referenced by add_paths_to_grouping_rel(), create_final_distinct_paths(), create_final_unique_paths(), create_partial_distinct_paths(), create_partial_grouping_paths(), create_partial_unique_paths(), generate_grouped_paths(), and generate_union_paths().

◆ create_append_path()

AppendPath * create_append_path ( PlannerInfo *  root,
RelOptInfo *  rel,
AppendPathInput  input,
List *  pathkeys,
Relids  required_outer,
int  parallel_workers,
bool  parallel_aware,
double  rows 
)
extern

Definition at line 1352 of file pathnode.c.

1358{
1360 ListCell *l;
1361
1362 Assert(!parallel_aware || parallel_workers > 0);
1363
1364 pathnode->child_append_relid_sets = input.child_append_relid_sets;
1365 pathnode->path.pathtype = T_Append;
1366 pathnode->path.parent = rel;
1367 pathnode->path.pathtarget = rel->reltarget;
1368
1369 /*
1370 * If this is for a baserel (not a join or non-leaf partition), we prefer
1371 * to apply get_baserel_parampathinfo to construct a full ParamPathInfo
1372 * for the path. This supports building a Memoize path atop this path,
1373 * and if this is a partitioned table the info may be useful for run-time
1374 * pruning (cf make_partition_pruneinfo()).
1375 *
1376 * However, if we don't have "root" then that won't work and we fall back
1377 * on the simpler get_appendrel_parampathinfo. There's no point in doing
1378 * the more expensive thing for a dummy path, either.
1379 */
1380 if (rel->reloptkind == RELOPT_BASEREL && root && input.subpaths != NIL)
1381 pathnode->path.param_info = get_baserel_parampathinfo(root,
1382 rel,
1384 else
1385 pathnode->path.param_info = get_appendrel_parampathinfo(rel,
1387
1388 pathnode->path.parallel_aware = parallel_aware;
1389 pathnode->path.parallel_safe = rel->consider_parallel;
1390 pathnode->path.parallel_workers = parallel_workers;
1391 pathnode->path.pathkeys = pathkeys;
1392
1393 /*
1394 * For parallel append, non-partial paths are sorted by descending total
1395 * costs. That way, the total time to finish all non-partial paths is
1396 * minimized. Also, the partial paths are sorted by descending startup
1397 * costs. There may be some paths that require to do startup work by a
1398 * single worker. In such case, it's better for workers to choose the
1399 * expensive ones first, whereas the leader should choose the cheapest
1400 * startup plan.
1401 */
1402 if (pathnode->path.parallel_aware)
1403 {
1404 /*
1405 * We mustn't fiddle with the order of subpaths when the Append has
1406 * pathkeys. The order they're listed in is critical to keeping the
1407 * pathkeys valid.
1408 */
1409 Assert(pathkeys == NIL);
1410
1412 list_sort(input.partial_subpaths, append_startup_cost_compare);
1413 }
1414 pathnode->first_partial_path = list_length(input.subpaths);
1415 pathnode->subpaths = list_concat(input.subpaths, input.partial_subpaths);
1416
1417 /*
1418 * Apply query-wide LIMIT if known and path is for sole base relation.
1419 * (Handling this at this low level is a bit klugy.)
1420 */
1421 if (root != NULL && bms_equal(rel->relids, root->all_query_rels))
1422 pathnode->limit_tuples = root->limit_tuples;
1423 else
1424 pathnode->limit_tuples = -1.0;
1425
1426 foreach(l, pathnode->subpaths)
1427 {
1428 Path *subpath = (Path *) lfirst(l);
1429
1430 pathnode->path.parallel_safe = pathnode->path.parallel_safe &&
1431 subpath->parallel_safe;
1432
1433 /* All child paths must have same parameterization */
1435 }
1436
1437 Assert(!parallel_aware || pathnode->path.parallel_safe);
1438
1439 /*
1440 * If there's exactly one child path then the output of the Append is
1441 * necessarily ordered the same as the child's, so we can inherit the
1442 * child's pathkeys if any, overriding whatever the caller might've said.
1443 * Furthermore, if the child's parallel awareness matches the Append's,
1444 * then the Append is a no-op and will be discarded later (in setrefs.c).
1445 * Then we can inherit the child's size and cost too, effectively charging
1446 * zero for the Append. Otherwise, we must do the normal costsize
1447 * calculation.
1448 */
1449 if (list_length(pathnode->subpaths) == 1)
1450 {
1451 Path *child = (Path *) linitial(pathnode->subpaths);
1452
1453 if (child->parallel_aware == parallel_aware)
1454 {
1455 pathnode->path.rows = child->rows;
1456 pathnode->path.startup_cost = child->startup_cost;
1457 pathnode->path.total_cost = child->total_cost;
1458 }
1459 else
1461 /* Must do this last, else cost_append complains */
1462 pathnode->path.pathkeys = child->pathkeys;
1463 }
1464 else
1466
1467 /* If the caller provided a row estimate, override the computed value. */
1468 if (rows >= 0)
1469 pathnode->path.rows = rows;
1470
1471 return pathnode;
1472}
void cost_append(AppendPath *apath, PlannerInfo *root)
Definition costsize.c:2312
FILE * input
void list_sort(List *list, list_sort_comparator cmp)
Definition list.c:1674
List * list_concat(List *list1, const List *list2)
Definition list.c:561
static int append_startup_cost_compare(const ListCell *a, const ListCell *b)
Definition pathnode.c:1506
static int append_total_cost_compare(const ListCell *a, const ListCell *b)
Definition pathnode.c:1484
#define linitial(l)
Definition pg_list.h:178
ParamPathInfo * get_appendrel_parampathinfo(RelOptInfo *appendrel, Relids required_outer)
Definition relnode.c:2015
ParamPathInfo * get_baserel_parampathinfo(PlannerInfo *root, RelOptInfo *baserel, Relids required_outer)
Definition relnode.c:1704
List * pathkeys
Definition pathnodes.h:2011
bool parallel_aware
Definition pathnodes.h:1998

References append_startup_cost_compare(), append_total_cost_compare(), Assert, bms_equal(), RelOptInfo::consider_parallel, cost_append(), fb(), get_appendrel_parampathinfo(), get_baserel_parampathinfo(), input, lfirst, linitial, list_concat(), list_length(), list_sort(), makeNode, NIL, Path::parallel_aware, Path::parallel_safe, PATH_REQ_OUTER, Path::pathkeys, RelOptInfo::relids, RELOPT_BASEREL, RelOptInfo::reloptkind, RelOptInfo::reltarget, root, Path::rows, Path::startup_cost, subpath(), and Path::total_cost.

Referenced by add_paths_to_append_rel(), create_degenerate_grouping_paths(), generate_nonunion_paths(), generate_orderedappend_paths(), generate_union_paths(), mark_dummy_rel(), reparameterize_path(), and set_dummy_rel_pathlist().

◆ create_bitmap_and_path()

BitmapAndPath * create_bitmap_and_path ( PlannerInfo *  root,
RelOptInfo *  rel,
List *  bitmapquals 
)
extern

Definition at line 1182 of file pathnode.c.

1185{
1188 ListCell *lc;
1189
1190 pathnode->path.pathtype = T_BitmapAnd;
1191 pathnode->path.parent = rel;
1192 pathnode->path.pathtarget = rel->reltarget;
1193
1194 /*
1195 * Identify the required outer rels as the union of what the child paths
1196 * depend on. (Alternatively, we could insist that the caller pass this
1197 * in, but it's more convenient and reliable to compute it here.)
1198 */
1199 foreach(lc, bitmapquals)
1200 {
1201 Path *bitmapqual = (Path *) lfirst(lc);
1202
1204 PATH_REQ_OUTER(bitmapqual));
1205 }
1206 pathnode->path.param_info = get_baserel_parampathinfo(root, rel,
1208
1209 /*
1210 * Currently, a BitmapHeapPath, BitmapAndPath, or BitmapOrPath will be
1211 * parallel-safe if and only if rel->consider_parallel is set. So, we can
1212 * set the flag for this path based only on the relation-level flag,
1213 * without actually iterating over the list of children.
1214 */
1215 pathnode->path.parallel_aware = false;
1216 pathnode->path.parallel_safe = rel->consider_parallel;
1217 pathnode->path.parallel_workers = 0;
1218
1219 pathnode->path.pathkeys = NIL; /* always unordered */
1220
1221 pathnode->bitmapquals = bitmapquals;
1222
1223 /* this sets bitmapselectivity as well as the regular cost fields: */
1225
1226 return pathnode;
1227}
Bitmapset * bms_add_members(Bitmapset *a, const Bitmapset *b)
Definition bitmapset.c:1036
void cost_bitmap_and_node(BitmapAndPath *path, PlannerInfo *root)
Definition costsize.c:1159

References bms_add_members(), RelOptInfo::consider_parallel, cost_bitmap_and_node(), fb(), get_baserel_parampathinfo(), lfirst, makeNode, NIL, PATH_REQ_OUTER, RelOptInfo::reltarget, and root.

Referenced by bitmap_and_cost_est(), and choose_bitmap_and().

◆ create_bitmap_heap_path()

BitmapHeapPath * create_bitmap_heap_path ( PlannerInfo *  root,
RelOptInfo *  rel,
Path *  bitmapqual,
Relids  required_outer,
double  loop_count,
int  parallel_degree 
)
extern

Definition at line 1149 of file pathnode.c.

1155{
1157
1158 pathnode->path.pathtype = T_BitmapHeapScan;
1159 pathnode->path.parent = rel;
1160 pathnode->path.pathtarget = rel->reltarget;
1161 pathnode->path.param_info = get_baserel_parampathinfo(root, rel,
1163 pathnode->path.parallel_aware = (parallel_degree > 0);
1164 pathnode->path.parallel_safe = rel->consider_parallel;
1165 pathnode->path.parallel_workers = parallel_degree;
1166 pathnode->path.pathkeys = NIL; /* always unordered */
1167
1168 pathnode->bitmapqual = bitmapqual;
1169
1170 cost_bitmap_heap_scan(&pathnode->path, root, rel,
1171 pathnode->path.param_info,
1172 bitmapqual, loop_count);
1173
1174 return pathnode;
1175}
void cost_bitmap_heap_scan(Path *path, PlannerInfo *root, RelOptInfo *baserel, ParamPathInfo *param_info, Path *bitmapqual, double loop_count)
Definition costsize.c:1013

References RelOptInfo::consider_parallel, cost_bitmap_heap_scan(), fb(), get_baserel_parampathinfo(), makeNode, NIL, RelOptInfo::reltarget, and root.

Referenced by create_index_paths(), create_partial_bitmap_paths(), and reparameterize_path().

◆ create_bitmap_or_path()

BitmapOrPath * create_bitmap_or_path ( PlannerInfo *  root,
RelOptInfo *  rel,
List *  bitmapquals 
)
extern

Definition at line 1234 of file pathnode.c.

1237{
1240 ListCell *lc;
1241
1242 pathnode->path.pathtype = T_BitmapOr;
1243 pathnode->path.parent = rel;
1244 pathnode->path.pathtarget = rel->reltarget;
1245
1246 /*
1247 * Identify the required outer rels as the union of what the child paths
1248 * depend on. (Alternatively, we could insist that the caller pass this
1249 * in, but it's more convenient and reliable to compute it here.)
1250 */
1251 foreach(lc, bitmapquals)
1252 {
1253 Path *bitmapqual = (Path *) lfirst(lc);
1254
1256 PATH_REQ_OUTER(bitmapqual));
1257 }
1258 pathnode->path.param_info = get_baserel_parampathinfo(root, rel,
1260
1261 /*
1262 * Currently, a BitmapHeapPath, BitmapAndPath, or BitmapOrPath will be
1263 * parallel-safe if and only if rel->consider_parallel is set. So, we can
1264 * set the flag for this path based only on the relation-level flag,
1265 * without actually iterating over the list of children.
1266 */
1267 pathnode->path.parallel_aware = false;
1268 pathnode->path.parallel_safe = rel->consider_parallel;
1269 pathnode->path.parallel_workers = 0;
1270
1271 pathnode->path.pathkeys = NIL; /* always unordered */
1272
1273 pathnode->bitmapquals = bitmapquals;
1274
1275 /* this sets bitmapselectivity as well as the regular cost fields: */
1277
1278 return pathnode;
1279}
void cost_bitmap_or_node(BitmapOrPath *path, PlannerInfo *root)
Definition costsize.c:1204

References bms_add_members(), RelOptInfo::consider_parallel, cost_bitmap_or_node(), fb(), get_baserel_parampathinfo(), lfirst, makeNode, NIL, PATH_REQ_OUTER, RelOptInfo::reltarget, and root.

Referenced by generate_bitmap_or_paths().

◆ create_ctescan_path()

Path * create_ctescan_path ( PlannerInfo *  root,
RelOptInfo *  rel,
List *  pathkeys,
Relids  required_outer 
)
extern

Definition at line 2017 of file pathnode.c.

2019{
2021
2022 pathnode->pathtype = T_CteScan;
2023 pathnode->parent = rel;
2024 pathnode->pathtarget = rel->reltarget;
2025 pathnode->param_info = get_baserel_parampathinfo(root, rel,
2027 pathnode->parallel_aware = false;
2028 pathnode->parallel_safe = rel->consider_parallel;
2029 pathnode->parallel_workers = 0;
2030 pathnode->pathkeys = pathkeys;
2031
2032 cost_ctescan(pathnode, root, rel, pathnode->param_info);
2033
2034 return pathnode;
2035}
void cost_ctescan(Path *path, PlannerInfo *root, RelOptInfo *baserel, ParamPathInfo *param_info)
Definition costsize.c:1746

References RelOptInfo::consider_parallel, cost_ctescan(), fb(), get_baserel_parampathinfo(), makeNode, RelOptInfo::reltarget, and root.

Referenced by set_cte_pathlist().

◆ create_foreign_join_path()

ForeignPath * create_foreign_join_path ( PlannerInfo *  root,
RelOptInfo *  rel,
PathTarget *  target,
double  rows,
int  disabled_nodes,
Cost  startup_cost,
Cost  total_cost,
List *  pathkeys,
Relids  required_outer,
Path *  fdw_outerpath,
List *  fdw_restrictinfo,
List *  fdw_private 
)
extern

Definition at line 2176 of file pathnode.c.

2185{
2187
2188 /*
2189 * We should use get_joinrel_parampathinfo to handle parameterized paths,
2190 * but the API of this function doesn't support it, and existing
2191 * extensions aren't yet trying to build such paths anyway. For the
2192 * moment just throw an error if someone tries it; eventually we should
2193 * revisit this.
2194 */
2196 elog(ERROR, "parameterized foreign joins are not supported yet");
2197
2198 pathnode->path.pathtype = T_ForeignScan;
2199 pathnode->path.parent = rel;
2200 pathnode->path.pathtarget = target ? target : rel->reltarget;
2201 pathnode->path.param_info = NULL; /* XXX see above */
2202 pathnode->path.parallel_aware = false;
2203 pathnode->path.parallel_safe = rel->consider_parallel;
2204 pathnode->path.parallel_workers = 0;
2205 pathnode->path.rows = rows;
2206 pathnode->path.disabled_nodes = disabled_nodes;
2207 pathnode->path.startup_cost = startup_cost;
2208 pathnode->path.total_cost = total_cost;
2209 pathnode->path.pathkeys = pathkeys;
2210
2211 pathnode->fdw_outerpath = fdw_outerpath;
2212 pathnode->fdw_restrictinfo = fdw_restrictinfo;
2213 pathnode->fdw_private = fdw_private;
2214
2215 return pathnode;
2216}
#define bms_is_empty(a)
Definition bitmapset.h:119

References bms_is_empty, RelOptInfo::consider_parallel, elog, ERROR, fb(), RelOptInfo::lateral_relids, makeNode, and RelOptInfo::reltarget.

Referenced by add_paths_with_pathkeys_for_rel(), and postgresGetForeignJoinPaths().

◆ create_foreign_upper_path()

ForeignPath * create_foreign_upper_path ( PlannerInfo *  root,
RelOptInfo *  rel,
PathTarget *  target,
double  rows,
int  disabled_nodes,
Cost  startup_cost,
Cost  total_cost,
List *  pathkeys,
Path *  fdw_outerpath,
List *  fdw_restrictinfo,
List *  fdw_private 
)
extern

Definition at line 2230 of file pathnode.c.

2238{
2240
2241 /*
2242 * Upper relations should never have any lateral references, since joining
2243 * is complete.
2244 */
2246
2247 pathnode->path.pathtype = T_ForeignScan;
2248 pathnode->path.parent = rel;
2249 pathnode->path.pathtarget = target ? target : rel->reltarget;
2250 pathnode->path.param_info = NULL;
2251 pathnode->path.parallel_aware = false;
2252 pathnode->path.parallel_safe = rel->consider_parallel;
2253 pathnode->path.parallel_workers = 0;
2254 pathnode->path.rows = rows;
2255 pathnode->path.disabled_nodes = disabled_nodes;
2256 pathnode->path.startup_cost = startup_cost;
2257 pathnode->path.total_cost = total_cost;
2258 pathnode->path.pathkeys = pathkeys;
2259
2260 pathnode->fdw_outerpath = fdw_outerpath;
2261 pathnode->fdw_restrictinfo = fdw_restrictinfo;
2262 pathnode->fdw_private = fdw_private;
2263
2264 return pathnode;
2265}

References Assert, bms_is_empty, RelOptInfo::consider_parallel, fb(), RelOptInfo::lateral_relids, makeNode, and RelOptInfo::reltarget.

Referenced by add_foreign_final_paths(), add_foreign_grouping_paths(), and add_foreign_ordered_paths().

◆ create_foreignscan_path()

ForeignPath * create_foreignscan_path ( PlannerInfo *  root,
RelOptInfo *  rel,
PathTarget *  target,
double  rows,
int  disabled_nodes,
Cost  startup_cost,
Cost  total_cost,
List *  pathkeys,
Relids  required_outer,
Path *  fdw_outerpath,
List *  fdw_restrictinfo,
List *  fdw_private 
)
extern

Definition at line 2128 of file pathnode.c.

2137{
2139
2140 /* Historically some FDWs were confused about when to use this */
2141 Assert(IS_SIMPLE_REL(rel));
2142
2143 pathnode->path.pathtype = T_ForeignScan;
2144 pathnode->path.parent = rel;
2145 pathnode->path.pathtarget = target ? target : rel->reltarget;
2146 pathnode->path.param_info = get_baserel_parampathinfo(root, rel,
2148 pathnode->path.parallel_aware = false;
2149 pathnode->path.parallel_safe = rel->consider_parallel;
2150 pathnode->path.parallel_workers = 0;
2151 pathnode->path.rows = rows;
2152 pathnode->path.disabled_nodes = disabled_nodes;
2153 pathnode->path.startup_cost = startup_cost;
2154 pathnode->path.total_cost = total_cost;
2155 pathnode->path.pathkeys = pathkeys;
2156
2157 pathnode->fdw_outerpath = fdw_outerpath;
2158 pathnode->fdw_restrictinfo = fdw_restrictinfo;
2159 pathnode->fdw_private = fdw_private;
2160
2161 return pathnode;
2162}
#define IS_SIMPLE_REL(rel)
Definition pathnodes.h:989

References Assert, RelOptInfo::consider_parallel, fb(), get_baserel_parampathinfo(), IS_SIMPLE_REL, makeNode, RelOptInfo::reltarget, and root.

Referenced by add_paths_with_pathkeys_for_rel(), fileGetForeignPaths(), and postgresGetForeignPaths().

◆ create_functionscan_path()

Path * create_functionscan_path ( PlannerInfo *  root,
RelOptInfo *  rel,
List *  pathkeys,
Relids  required_outer 
)
extern

Definition at line 1939 of file pathnode.c.

1941{
1943
1944 pathnode->pathtype = T_FunctionScan;
1945 pathnode->parent = rel;
1946 pathnode->pathtarget = rel->reltarget;
1947 pathnode->param_info = get_baserel_parampathinfo(root, rel,
1949 pathnode->parallel_aware = false;
1950 pathnode->parallel_safe = rel->consider_parallel;
1951 pathnode->parallel_workers = 0;
1952 pathnode->pathkeys = pathkeys;
1953
1954 cost_functionscan(pathnode, root, rel, pathnode->param_info);
1955
1956 return pathnode;
1957}
void cost_functionscan(Path *path, PlannerInfo *root, RelOptInfo *baserel, ParamPathInfo *param_info)
Definition costsize.c:1564

References RelOptInfo::consider_parallel, cost_functionscan(), fb(), get_baserel_parampathinfo(), makeNode, RelOptInfo::reltarget, and root.

Referenced by set_function_pathlist().

◆ create_gather_merge_path()

GatherMergePath * create_gather_merge_path ( PlannerInfo *  root,
RelOptInfo *  rel,
Path *  subpath,
PathTarget *  target,
List *  pathkeys,
Relids  required_outer,
double *  rows 
)
extern

Definition at line 1813 of file pathnode.c.

1816{
1818 int input_disabled_nodes = 0;
1821
1822 Assert(subpath->parallel_safe);
1823 Assert(pathkeys);
1824
1825 /*
1826 * The subpath should guarantee that it is adequately ordered either by
1827 * adding an explicit sort node or by using presorted input. We cannot
1828 * add an explicit Sort node for the subpath in createplan.c on additional
1829 * pathkeys, because we can't guarantee the sort would be safe. For
1830 * example, expressions may be volatile or otherwise parallel unsafe.
1831 */
1832 if (!pathkeys_contained_in(pathkeys, subpath->pathkeys))
1833 elog(ERROR, "gather merge input not sufficiently sorted");
1834
1835 pathnode->path.pathtype = T_GatherMerge;
1836 pathnode->path.parent = rel;
1837 pathnode->path.param_info = get_baserel_parampathinfo(root, rel,
1839 pathnode->path.parallel_aware = false;
1840
1841 pathnode->subpath = subpath;
1842 pathnode->num_workers = subpath->parallel_workers;
1843 pathnode->path.pathkeys = pathkeys;
1844 pathnode->path.pathtarget = target ? target : rel->reltarget;
1845
1846 input_disabled_nodes += subpath->disabled_nodes;
1847 input_startup_cost += subpath->startup_cost;
1848 input_total_cost += subpath->total_cost;
1849
1850 cost_gather_merge(pathnode, root, rel, pathnode->path.param_info,
1852 input_total_cost, rows);
1853
1854 return pathnode;
1855}
void cost_gather_merge(GatherMergePath *path, PlannerInfo *root, RelOptInfo *rel, ParamPathInfo *param_info, int input_disabled_nodes, Cost input_startup_cost, Cost input_total_cost, double *rows)
Definition costsize.c:471
bool pathkeys_contained_in(List *keys1, List *keys2)
Definition pathkeys.c:343

References Assert, cost_gather_merge(), elog, ERROR, fb(), get_baserel_parampathinfo(), makeNode, pathkeys_contained_in(), RelOptInfo::reltarget, root, and subpath().

Referenced by create_ordered_paths(), gather_grouping_paths(), generate_gather_paths(), and generate_useful_gather_paths().

◆ create_gather_path()

GatherPath * create_gather_path ( PlannerInfo *  root,
RelOptInfo *  rel,
Path *  subpath,
PathTarget *  target,
Relids  required_outer,
double *  rows 
)
extern

Definition at line 1865 of file pathnode.c.

1867{
1869
1870 Assert(subpath->parallel_safe);
1871
1872 pathnode->path.pathtype = T_Gather;
1873 pathnode->path.parent = rel;
1874 pathnode->path.pathtarget = target;
1875 pathnode->path.param_info = get_baserel_parampathinfo(root, rel,
1877 pathnode->path.parallel_aware = false;
1878 pathnode->path.parallel_safe = false;
1879 pathnode->path.parallel_workers = 0;
1880 pathnode->path.pathkeys = NIL; /* Gather has unordered result */
1881
1882 pathnode->subpath = subpath;
1883 pathnode->num_workers = subpath->parallel_workers;
1884 pathnode->single_copy = false;
1885
1886 if (pathnode->num_workers == 0)
1887 {
1888 pathnode->path.pathkeys = subpath->pathkeys;
1889 pathnode->num_workers = 1;
1890 pathnode->single_copy = true;
1891 }
1892
1893 cost_gather(pathnode, root, rel, pathnode->path.param_info, rows);
1894
1895 return pathnode;
1896}
void cost_gather(GatherPath *path, PlannerInfo *root, RelOptInfo *rel, ParamPathInfo *param_info, double *rows)
Definition costsize.c:431

References Assert, cost_gather(), fb(), get_baserel_parampathinfo(), makeNode, NIL, root, and subpath().

Referenced by generate_gather_paths(), and generate_union_paths().

◆ create_group_path()

GroupPath * create_group_path ( PlannerInfo *  root,
RelOptInfo *  rel,
Path *  subpath,
List *  groupClause,
List *  qual,
double  numGroups 
)
extern

Definition at line 2948 of file pathnode.c.

2954{
2956 PathTarget *target = rel->reltarget;
2957
2958 pathnode->path.pathtype = T_Group;
2959 pathnode->path.parent = rel;
2960 pathnode->path.pathtarget = target;
2961 /* For now, assume we are above any joins, so no parameterization */
2962 pathnode->path.param_info = NULL;
2963 pathnode->path.parallel_aware = false;
2964 pathnode->path.parallel_safe = rel->consider_parallel &&
2965 subpath->parallel_safe;
2966 pathnode->path.parallel_workers = subpath->parallel_workers;
2967 /* Group doesn't change sort ordering */
2968 pathnode->path.pathkeys = subpath->pathkeys;
2969
2970 pathnode->subpath = subpath;
2971
2972 pathnode->groupClause = groupClause;
2973 pathnode->qual = qual;
2974
2975 cost_group(&pathnode->path, root,
2976 list_length(groupClause),
2977 numGroups,
2978 qual,
2979 subpath->disabled_nodes,
2980 subpath->startup_cost, subpath->total_cost,
2981 subpath->rows);
2982
2983 /* add tlist eval cost for each output row */
2984 pathnode->path.startup_cost += target->cost.startup;
2985 pathnode->path.total_cost += target->cost.startup +
2986 target->cost.per_tuple * pathnode->path.rows;
2987
2988 return pathnode;
2989}
void cost_group(Path *path, PlannerInfo *root, int numGroupCols, double numGroups, List *quals, int input_disabled_nodes, Cost input_startup_cost, Cost input_total_cost, double input_tuples)
Definition costsize.c:3324

References RelOptInfo::consider_parallel, PathTarget::cost, cost_group(), fb(), list_length(), makeNode, QualCost::per_tuple, RelOptInfo::reltarget, root, QualCost::startup, and subpath().

Referenced by add_paths_to_grouping_rel(), and create_partial_grouping_paths().

◆ create_group_result_path()

GroupResultPath * create_group_result_path ( PlannerInfo *  root,
RelOptInfo *  rel,
PathTarget *  target,
List *  havingqual 
)
extern

Definition at line 1664 of file pathnode.c.

1666{
1668
1669 pathnode->path.pathtype = T_Result;
1670 pathnode->path.parent = rel;
1671 pathnode->path.pathtarget = target;
1672 pathnode->path.param_info = NULL; /* there are no other rels... */
1673 pathnode->path.parallel_aware = false;
1674 pathnode->path.parallel_safe = rel->consider_parallel;
1675 pathnode->path.parallel_workers = 0;
1676 pathnode->path.pathkeys = NIL;
1677 pathnode->quals = havingqual;
1678
1679 /*
1680 * We can't quite use cost_resultscan() because the quals we want to
1681 * account for are not baserestrict quals of the rel. Might as well just
1682 * hack it here.
1683 */
1684 pathnode->path.rows = 1;
1685 pathnode->path.startup_cost = target->cost.startup;
1686 pathnode->path.total_cost = target->cost.startup +
1687 cpu_tuple_cost + target->cost.per_tuple;
1688
1689 /*
1690 * Add cost of qual, if any --- but we ignore its selectivity, since our
1691 * rowcount estimate should be 1 no matter what the qual is.
1692 */
1693 if (havingqual)
1694 {
1696
1698 /* havingqual is evaluated once at startup */
1699 pathnode->path.startup_cost += qual_cost.startup + qual_cost.per_tuple;
1700 pathnode->path.total_cost += qual_cost.startup + qual_cost.per_tuple;
1701 }
1702
1703 return pathnode;
1704}
double cpu_tuple_cost
Definition costsize.c:133
void cost_qual_eval(QualCost *cost, List *quals, PlannerInfo *root)
Definition costsize.c:4923

References RelOptInfo::consider_parallel, PathTarget::cost, cost_qual_eval(), cpu_tuple_cost, fb(), makeNode, NIL, QualCost::per_tuple, root, and QualCost::startup.

Referenced by create_degenerate_grouping_paths(), and query_planner().

◆ create_groupingsets_path()

GroupingSetsPath * create_groupingsets_path ( PlannerInfo *  root,
RelOptInfo *  rel,
Path *  subpath,
List *  having_qual,
AggStrategy  aggstrategy,
List *  rollups,
const AggClauseCosts *  agg_costs 
)
extern

Definition at line 3149 of file pathnode.c.

3156{
3158 PathTarget *target = rel->reltarget;
3159 ListCell *lc;
3160 bool is_first = true;
3161 bool is_first_sort = true;
3162
3163 /* The topmost generated Plan node will be an Agg */
3164 pathnode->path.pathtype = T_Agg;
3165 pathnode->path.parent = rel;
3166 pathnode->path.pathtarget = target;
3167 pathnode->path.param_info = subpath->param_info;
3168 pathnode->path.parallel_aware = false;
3169 pathnode->path.parallel_safe = rel->consider_parallel &&
3170 subpath->parallel_safe;
3171 pathnode->path.parallel_workers = subpath->parallel_workers;
3172 pathnode->subpath = subpath;
3173
3174 /*
3175 * Simplify callers by downgrading AGG_SORTED to AGG_PLAIN, and AGG_MIXED
3176 * to AGG_HASHED, here if possible.
3177 */
3178 if (aggstrategy == AGG_SORTED &&
3179 list_length(rollups) == 1 &&
3180 ((RollupData *) linitial(rollups))->groupClause == NIL)
3181 aggstrategy = AGG_PLAIN;
3182
3183 if (aggstrategy == AGG_MIXED &&
3184 list_length(rollups) == 1)
3185 aggstrategy = AGG_HASHED;
3186
3187 /*
3188 * Output will be in sorted order by group_pathkeys if, and only if, there
3189 * is a single rollup operation on a non-empty list of grouping
3190 * expressions.
3191 */
3192 if (aggstrategy == AGG_SORTED && list_length(rollups) == 1)
3193 pathnode->path.pathkeys = root->group_pathkeys;
3194 else
3195 pathnode->path.pathkeys = NIL;
3196
3197 pathnode->aggstrategy = aggstrategy;
3198 pathnode->rollups = rollups;
3199 pathnode->qual = having_qual;
3200 pathnode->transitionSpace = agg_costs ? agg_costs->transitionSpace : 0;
3201
3202 Assert(rollups != NIL);
3203 Assert(aggstrategy != AGG_PLAIN || list_length(rollups) == 1);
3204 Assert(aggstrategy != AGG_MIXED || list_length(rollups) > 1);
3205
3206 foreach(lc, rollups)
3207 {
3209 List *gsets = rollup->gsets;
3210 int numGroupCols = list_length(linitial(gsets));
3211
3212 /*
3213 * In AGG_SORTED or AGG_PLAIN mode, the first rollup takes the
3214 * (already-sorted) input, and following ones do their own sort.
3215 *
3216 * In AGG_HASHED mode, there is one rollup for each grouping set.
3217 *
3218 * In AGG_MIXED mode, the first rollups are hashed, the first
3219 * non-hashed one takes the (already-sorted) input, and following ones
3220 * do their own sort.
3221 */
3222 if (is_first)
3223 {
3224 cost_agg(&pathnode->path, root,
3225 aggstrategy,
3226 agg_costs,
3228 rollup->numGroups,
3230 subpath->disabled_nodes,
3231 subpath->startup_cost,
3232 subpath->total_cost,
3233 subpath->rows,
3234 subpath->pathtarget->width);
3235 is_first = false;
3236 if (!rollup->is_hashed)
3237 is_first_sort = false;
3238 }
3239 else
3240 {
3241 Path sort_path; /* dummy for result of cost_sort */
3242 Path agg_path; /* dummy for result of cost_agg */
3243
3244 if (rollup->is_hashed || is_first_sort)
3245 {
3246 /*
3247 * Account for cost of aggregation, but don't charge input
3248 * cost again
3249 */
3251 rollup->is_hashed ? AGG_HASHED : AGG_SORTED,
3252 agg_costs,
3254 rollup->numGroups,
3256 0, 0.0, 0.0,
3257 subpath->rows,
3258 subpath->pathtarget->width);
3259 if (!rollup->is_hashed)
3260 is_first_sort = false;
3261 }
3262 else
3263 {
3264 /* Account for cost of sort, but don't charge input cost again */
3266 0.0,
3267 subpath->rows,
3268 subpath->pathtarget->width,
3269 0.0,
3270 work_mem,
3271 -1.0);
3272
3273 /* Account for cost of aggregation */
3274
3276 AGG_SORTED,
3277 agg_costs,
3279 rollup->numGroups,
3281 sort_path.disabled_nodes,
3282 sort_path.startup_cost,
3283 sort_path.total_cost,
3284 sort_path.rows,
3285 subpath->pathtarget->width);
3286 }
3287
3288 pathnode->path.disabled_nodes += agg_path.disabled_nodes;
3289 pathnode->path.total_cost += agg_path.total_cost;
3290 pathnode->path.rows += agg_path.rows;
3291 }
3292 }
3293
3294 /* add tlist eval cost for each output row */
3295 pathnode->path.startup_cost += target->cost.startup;
3296 pathnode->path.total_cost += target->cost.startup +
3297 target->cost.per_tuple * pathnode->path.rows;
3298
3299 return pathnode;
3300}
void cost_sort(Path *path, PlannerInfo *root, List *pathkeys, int input_disabled_nodes, Cost input_cost, double tuples, int width, Cost comparison_cost, int sort_mem, double limit_tuples)
Definition costsize.c:2202
int work_mem
Definition globals.c:133
@ AGG_HASHED
Definition nodes.h:364
@ AGG_MIXED
Definition nodes.h:365
@ AGG_PLAIN
Definition nodes.h:362

References AGG_HASHED, AGG_MIXED, AGG_PLAIN, AGG_SORTED, Assert, RelOptInfo::consider_parallel, PathTarget::cost, cost_agg(), cost_sort(), fb(), lfirst, linitial, list_length(), makeNode, NIL, QualCost::per_tuple, RelOptInfo::reltarget, root, QualCost::startup, subpath(), and work_mem.

Referenced by consider_groupingsets_paths().

◆ create_hashjoin_path()

HashPath * create_hashjoin_path ( PlannerInfo *  root,
RelOptInfo *  joinrel,
JoinType  jointype,
JoinCostWorkspace *  workspace,
JoinPathExtraData *  extra,
Path *  outer_path,
Path *  inner_path,
bool  parallel_hash,
List *  restrict_clauses,
Relids  required_outer,
List *  hashclauses 
)
extern

Definition at line 2521 of file pathnode.c.

2532{
2534
2535 pathnode->jpath.path.pathtype = T_HashJoin;
2536 pathnode->jpath.path.parent = joinrel;
2537 pathnode->jpath.path.pathtarget = joinrel->reltarget;
2538 pathnode->jpath.path.param_info =
2540 joinrel,
2541 outer_path,
2542 inner_path,
2543 extra->sjinfo,
2546 pathnode->jpath.path.parallel_aware =
2547 joinrel->consider_parallel && parallel_hash;
2548 pathnode->jpath.path.parallel_safe = joinrel->consider_parallel &&
2549 outer_path->parallel_safe && inner_path->parallel_safe;
2550 /* This is a foolish way to estimate parallel_workers, but for now... */
2551 pathnode->jpath.path.parallel_workers = outer_path->parallel_workers;
2552
2553 /*
2554 * A hashjoin never has pathkeys, since its output ordering is
2555 * unpredictable due to possible batching. XXX If the inner relation is
2556 * small enough, we could instruct the executor that it must not batch,
2557 * and then we could assume that the output inherits the outer relation's
2558 * ordering, which might save a sort step. However there is considerable
2559 * downside if our estimate of the inner relation size is badly off. For
2560 * the moment we don't risk it. (Note also that if we wanted to take this
2561 * seriously, joinpath.c would have to consider many more paths for the
2562 * outer rel than it does now.)
2563 */
2564 pathnode->jpath.path.pathkeys = NIL;
2565 pathnode->jpath.jointype = jointype;
2566 pathnode->jpath.inner_unique = extra->inner_unique;
2567 pathnode->jpath.outerjoinpath = outer_path;
2568 pathnode->jpath.innerjoinpath = inner_path;
2569 pathnode->jpath.joinrestrictinfo = restrict_clauses;
2570 pathnode->path_hashclauses = hashclauses;
2571 /* final_cost_hashjoin will fill in pathnode->num_batches */
2572
2573 final_cost_hashjoin(root, pathnode, workspace, extra);
2574
2575 return pathnode;
2576}
void final_cost_hashjoin(PlannerInfo *root, HashPath *path, JoinCostWorkspace *workspace, JoinPathExtraData *extra)
Definition costsize.c:4439
ParamPathInfo * get_joinrel_parampathinfo(PlannerInfo *root, RelOptInfo *joinrel, Path *outer_path, Path *inner_path, SpecialJoinInfo *sjinfo, Relids required_outer, List **restrict_clauses)
Definition relnode.c:1818
SpecialJoinInfo * sjinfo
Definition pathnodes.h:3623

References RelOptInfo::consider_parallel, fb(), final_cost_hashjoin(), get_joinrel_parampathinfo(), JoinPathExtraData::inner_unique, makeNode, NIL, RelOptInfo::reltarget, root, and JoinPathExtraData::sjinfo.

Referenced by try_hashjoin_path(), and try_partial_hashjoin_path().

◆ create_incremental_sort_path()

IncrementalSortPath * create_incremental_sort_path ( PlannerInfo *  root,
RelOptInfo *  rel,
Path *  subpath,
List *  pathkeys,
int  presorted_keys,
double  limit_tuples 
)
extern

Definition at line 2855 of file pathnode.c.

2861{
2863 SortPath *pathnode = &sort->spath;
2864
2866 pathnode->path.parent = rel;
2867 /* Sort doesn't project, so use source path's pathtarget */
2868 pathnode->path.pathtarget = subpath->pathtarget;
2869 pathnode->path.param_info = subpath->param_info;
2870 pathnode->path.parallel_aware = false;
2871 pathnode->path.parallel_safe = rel->consider_parallel &&
2872 subpath->parallel_safe;
2873 pathnode->path.parallel_workers = subpath->parallel_workers;
2874 pathnode->path.pathkeys = pathkeys;
2875
2876 pathnode->subpath = subpath;
2877
2879 root, pathkeys, presorted_keys,
2880 subpath->disabled_nodes,
2881 subpath->startup_cost,
2882 subpath->total_cost,
2883 subpath->rows,
2884 subpath->pathtarget->width,
2885 0.0, /* XXX comparison_cost shouldn't be 0? */
2886 work_mem, limit_tuples);
2887
2888 sort->nPresortedCols = presorted_keys;
2889
2890 return sort;
2891}
Datum sort(PG_FUNCTION_ARGS)
Definition _int_op.c:199
void cost_incremental_sort(Path *path, PlannerInfo *root, List *pathkeys, int presorted_keys, int input_disabled_nodes, Cost input_startup_cost, Cost input_total_cost, double input_tuples, int width, Cost comparison_cost, int sort_mem, double limit_tuples)
Definition costsize.c:2054
NodeTag pathtype
Definition pathnodes.h:1971
Path path
Definition pathnodes.h:2537

References RelOptInfo::consider_parallel, cost_incremental_sort(), fb(), makeNode, SortPath::path, Path::pathtype, root, sort(), subpath(), and work_mem.

Referenced by build_setop_child_paths(), create_final_unique_paths(), create_one_window_path(), create_ordered_paths(), create_partial_unique_paths(), gather_grouping_paths(), generate_grouped_paths(), generate_useful_gather_paths(), and make_ordered_path().

◆ create_index_path()

IndexPath * create_index_path ( PlannerInfo *  root,
IndexOptInfo *  index,
List *  indexclauses,
List *  indexorderbys,
List *  indexorderbycols,
List *  pathkeys,
ScanDirection  indexscandir,
bool  indexonly,
Relids  required_outer,
double  loop_count,
bool  partial_path 
)
extern

Definition at line 1092 of file pathnode.c.

1103{
1105 RelOptInfo *rel = index->rel;
1106
1107 pathnode->path.pathtype = indexonly ? T_IndexOnlyScan : T_IndexScan;
1108 pathnode->path.parent = rel;
1109 pathnode->path.pathtarget = rel->reltarget;
1110 pathnode->path.param_info = get_baserel_parampathinfo(root, rel,
1112 pathnode->path.parallel_aware = false;
1113 pathnode->path.parallel_safe = rel->consider_parallel;
1114 pathnode->path.parallel_workers = 0;
1115 pathnode->path.pathkeys = pathkeys;
1116
1117 pathnode->indexinfo = index;
1118 pathnode->indexclauses = indexclauses;
1119 pathnode->indexorderbys = indexorderbys;
1120 pathnode->indexorderbycols = indexorderbycols;
1121 pathnode->indexscandir = indexscandir;
1122
1124
1125 /*
1126 * cost_index will set disabled_nodes to 1 if this rel is not allowed to
1127 * use index scans in general, but it doesn't have the IndexOptInfo to
1128 * know whether this specific index has been disabled.
1129 */
1130 if (index->disabled)
1131 pathnode->path.disabled_nodes = 1;
1132
1133 return pathnode;
1134}
void cost_index(IndexPath *path, PlannerInfo *root, double loop_count, bool partial_path)
Definition costsize.c:546
Definition type.h:97

References RelOptInfo::consider_parallel, cost_index(), fb(), get_baserel_parampathinfo(), makeNode, RelOptInfo::reltarget, and root.

Referenced by build_index_paths(), and plan_cluster_use_sort().

◆ create_limit_path()

LimitPath * create_limit_path ( PlannerInfo *  root,
RelOptInfo *  rel,
Path *  subpath,
Node *  limitOffset,
Node *  limitCount,
LimitOption  limitOption,
int64  offset_est,
int64  count_est 
)
extern

Definition at line 3813 of file pathnode.c.

3818{
3820
3821 pathnode->path.pathtype = T_Limit;
3822 pathnode->path.parent = rel;
3823 /* Limit doesn't project, so use source path's pathtarget */
3824 pathnode->path.pathtarget = subpath->pathtarget;
3825 /* For now, assume we are above any joins, so no parameterization */
3826 pathnode->path.param_info = NULL;
3827 pathnode->path.parallel_aware = false;
3828 pathnode->path.parallel_safe = rel->consider_parallel &&
3829 subpath->parallel_safe;
3830 pathnode->path.parallel_workers = subpath->parallel_workers;
3831 pathnode->path.rows = subpath->rows;
3832 pathnode->path.disabled_nodes = subpath->disabled_nodes;
3833 pathnode->path.startup_cost = subpath->startup_cost;
3834 pathnode->path.total_cost = subpath->total_cost;
3835 pathnode->path.pathkeys = subpath->pathkeys;
3836 pathnode->subpath = subpath;
3837 pathnode->limitOffset = limitOffset;
3838 pathnode->limitCount = limitCount;
3839 pathnode->limitOption = limitOption;
3840
3841 /*
3842 * Adjust the output rows count and costs according to the offset/limit.
3843 */
3845 &pathnode->path.startup_cost,
3846 &pathnode->path.total_cost,
3847 offset_est, count_est);
3848
3849 return pathnode;
3850}
void adjust_limit_rows_costs(double *rows, Cost *startup_cost, Cost *total_cost, int64 offset_est, int64 count_est)
Definition pathnode.c:3869

References adjust_limit_rows_costs(), RelOptInfo::consider_parallel, fb(), makeNode, and subpath().

Referenced by create_final_distinct_paths(), create_partial_distinct_paths(), and grouping_planner().

◆ create_lockrows_path()

LockRowsPath * create_lockrows_path ( PlannerInfo *  root,
RelOptInfo *  rel,
Path *  subpath,
List *  rowMarks,
int  epqParam 
)
extern

Definition at line 3650 of file pathnode.c.

3652{
3654
3655 pathnode->path.pathtype = T_LockRows;
3656 pathnode->path.parent = rel;
3657 /* LockRows doesn't project, so use source path's pathtarget */
3658 pathnode->path.pathtarget = subpath->pathtarget;
3659 /* For now, assume we are above any joins, so no parameterization */
3660 pathnode->path.param_info = NULL;
3661 pathnode->path.parallel_aware = false;
3662 pathnode->path.parallel_safe = false;
3663 pathnode->path.parallel_workers = 0;
3664 pathnode->path.rows = subpath->rows;
3665
3666 /*
3667 * The result cannot be assumed sorted, since locking might cause the sort
3668 * key columns to be replaced with new values.
3669 */
3670 pathnode->path.pathkeys = NIL;
3671
3672 pathnode->subpath = subpath;
3673 pathnode->rowMarks = rowMarks;
3674 pathnode->epqParam = epqParam;
3675
3676 /*
3677 * We should charge something extra for the costs of row locking and
3678 * possible refetches, but it's hard to say how much. For now, use
3679 * cpu_tuple_cost per row.
3680 */
3681 pathnode->path.disabled_nodes = subpath->disabled_nodes;
3682 pathnode->path.startup_cost = subpath->startup_cost;
3683 pathnode->path.total_cost = subpath->total_cost +
3684 cpu_tuple_cost * subpath->rows;
3685
3686 return pathnode;
3687}

References cpu_tuple_cost, fb(), makeNode, NIL, RelOptInfo::rows, and subpath().

Referenced by grouping_planner().

◆ create_material_path()

MaterialPath * create_material_path ( RelOptInfo *  rel,
Path *  subpath,
bool  enabled 
)
extern

Definition at line 1712 of file pathnode.c.

1713{
1715
1716 Assert(subpath->parent == rel);
1717
1718 pathnode->path.pathtype = T_Material;
1719 pathnode->path.parent = rel;
1720 pathnode->path.pathtarget = rel->reltarget;
1721 pathnode->path.param_info = subpath->param_info;
1722 pathnode->path.parallel_aware = false;
1723 pathnode->path.parallel_safe = rel->consider_parallel &&
1724 subpath->parallel_safe;
1725 pathnode->path.parallel_workers = subpath->parallel_workers;
1726 pathnode->path.pathkeys = subpath->pathkeys;
1727
1728 pathnode->subpath = subpath;
1729
1730 cost_material(&pathnode->path,
1731 enabled,
1732 subpath->disabled_nodes,
1733 subpath->startup_cost,
1734 subpath->total_cost,
1735 subpath->rows,
1736 subpath->pathtarget->width);
1737
1738 return pathnode;
1739}
void cost_material(Path *path, bool enabled, int input_disabled_nodes, Cost input_startup_cost, Cost input_total_cost, double tuples, int width)
Definition costsize.c:2584

References Assert, RelOptInfo::consider_parallel, cost_material(), fb(), makeNode, RelOptInfo::reltarget, and subpath().

Referenced by consider_parallel_nestloop(), match_unsorted_outer(), reparameterize_path(), and set_tablesample_rel_pathlist().

◆ create_memoize_path()

MemoizePath * create_memoize_path ( PlannerInfo *  root,
RelOptInfo *  rel,
Path *  subpath,
List *  param_exprs,
List *  hash_operators,
bool  singlerow,
bool  binary_mode,
Cardinality  est_calls 
)
extern

Definition at line 1746 of file pathnode.c.

1749{
1751
1752 Assert(subpath->parent == rel);
1753
1754 pathnode->path.pathtype = T_Memoize;
1755 pathnode->path.parent = rel;
1756 pathnode->path.pathtarget = rel->reltarget;
1757 pathnode->path.param_info = subpath->param_info;
1758 pathnode->path.parallel_aware = false;
1759 pathnode->path.parallel_safe = rel->consider_parallel &&
1760 subpath->parallel_safe;
1761 pathnode->path.parallel_workers = subpath->parallel_workers;
1762 pathnode->path.pathkeys = subpath->pathkeys;
1763
1764 pathnode->subpath = subpath;
1765 pathnode->hash_operators = hash_operators;
1766 pathnode->param_exprs = param_exprs;
1767 pathnode->singlerow = singlerow;
1768 pathnode->binary_mode = binary_mode;
1769
1770 /*
1771 * For now we set est_entries to 0. cost_memoize_rescan() does all the
1772 * hard work to determine how many cache entries there are likely to be,
1773 * so it seems best to leave it up to that function to fill this field in.
1774 * If left at 0, the executor will make a guess at a good value.
1775 */
1776 pathnode->est_entries = 0;
1777
1778 pathnode->est_calls = clamp_row_est(est_calls);
1779
1780 /* These will also be set later in cost_memoize_rescan() */
1781 pathnode->est_unique_keys = 0.0;
1782 pathnode->est_hit_ratio = 0.0;
1783
1784 /*
1785 * We should not be asked to generate this path type when memoization is
1786 * disabled, so set our count of disabled nodes equal to the subpath's
1787 * count.
1788 *
1789 * It would be nice to also Assert that memoization is enabled, but the
1790 * value of enable_memoize is not controlling: what we would need to check
1791 * is that the JoinPathExtraData's pgs_mask included PGS_NESTLOOP_MEMOIZE.
1792 */
1793 pathnode->path.disabled_nodes = subpath->disabled_nodes;
1794
1795 /*
1796 * Add a small additional charge for caching the first entry. All the
1797 * harder calculations for rescans are performed in cost_memoize_rescan().
1798 */
1799 pathnode->path.startup_cost = subpath->startup_cost + cpu_tuple_cost;
1800 pathnode->path.total_cost = subpath->total_cost + cpu_tuple_cost;
1801 pathnode->path.rows = subpath->rows;
1802
1803 return pathnode;
1804}

References Assert, clamp_row_est(), RelOptInfo::consider_parallel, cpu_tuple_cost, fb(), makeNode, RelOptInfo::reltarget, and subpath().

Referenced by get_memoize_path(), and reparameterize_path().

◆ create_merge_append_path()

MergeAppendPath * create_merge_append_path ( PlannerInfo *  root,
RelOptInfo *  rel,
List *  subpaths,
List *  child_append_relid_sets,
List *  pathkeys,
Relids  required_outer 
)
extern

Definition at line 1524 of file pathnode.c.

1530{
1535 ListCell *l;
1536
1537 /*
1538 * We don't currently support parameterized MergeAppend paths, as
1539 * explained in the comments for generate_orderedappend_paths.
1540 */
1542
1543 pathnode->child_append_relid_sets = child_append_relid_sets;
1544 pathnode->path.pathtype = T_MergeAppend;
1545 pathnode->path.parent = rel;
1546 pathnode->path.pathtarget = rel->reltarget;
1547 pathnode->path.param_info = NULL;
1548 pathnode->path.parallel_aware = false;
1549 pathnode->path.parallel_safe = rel->consider_parallel;
1550 pathnode->path.parallel_workers = 0;
1551 pathnode->path.pathkeys = pathkeys;
1552 pathnode->subpaths = subpaths;
1553
1554 /*
1555 * Apply query-wide LIMIT if known and path is for sole base relation.
1556 * (Handling this at this low level is a bit klugy.)
1557 */
1558 if (bms_equal(rel->relids, root->all_query_rels))
1559 pathnode->limit_tuples = root->limit_tuples;
1560 else
1561 pathnode->limit_tuples = -1.0;
1562
1563 /*
1564 * Add up the sizes and costs of the input paths.
1565 */
1566 pathnode->path.rows = 0;
1569 input_total_cost = 0;
1570 foreach(l, subpaths)
1571 {
1572 Path *subpath = (Path *) lfirst(l);
1573 int presorted_keys;
1574 Path sort_path; /* dummy for result of
1575 * cost_sort/cost_incremental_sort */
1576
1577 /* All child paths should be unparameterized */
1579
1580 pathnode->path.rows += subpath->rows;
1581 pathnode->path.parallel_safe = pathnode->path.parallel_safe &&
1582 subpath->parallel_safe;
1583
1584 if (!pathkeys_count_contained_in(pathkeys, subpath->pathkeys,
1585 &presorted_keys))
1586 {
1587 /*
1588 * We'll need to insert a Sort node, so include costs for that. We
1589 * choose to use incremental sort if it is enabled and there are
1590 * presorted keys; otherwise we use full sort.
1591 *
1592 * We can use the parent's LIMIT if any, since we certainly won't
1593 * pull more than that many tuples from any child.
1594 */
1595 if (enable_incremental_sort && presorted_keys > 0)
1596 {
1598 root,
1599 pathkeys,
1600 presorted_keys,
1601 subpath->disabled_nodes,
1602 subpath->startup_cost,
1603 subpath->total_cost,
1604 subpath->rows,
1605 subpath->pathtarget->width,
1606 0.0,
1607 work_mem,
1608 pathnode->limit_tuples);
1609 }
1610 else
1611 {
1613 root,
1614 pathkeys,
1615 subpath->disabled_nodes,
1616 subpath->total_cost,
1617 subpath->rows,
1618 subpath->pathtarget->width,
1619 0.0,
1620 work_mem,
1621 pathnode->limit_tuples);
1622 }
1623
1624 subpath = &sort_path;
1625 }
1626
1627 input_disabled_nodes += subpath->disabled_nodes;
1628 input_startup_cost += subpath->startup_cost;
1629 input_total_cost += subpath->total_cost;
1630 }
1631
1632 /*
1633 * Now we can compute total costs of the MergeAppend. If there's exactly
1634 * one child path and its parallel awareness matches that of the
1635 * MergeAppend, then the MergeAppend is a no-op and will be discarded
1636 * later (in setrefs.c); otherwise we do the normal cost calculation.
1637 */
1638 if (list_length(subpaths) == 1 &&
1639 ((Path *) linitial(subpaths))->parallel_aware ==
1640 pathnode->path.parallel_aware)
1641 {
1642 pathnode->path.disabled_nodes = input_disabled_nodes;
1643 pathnode->path.startup_cost = input_startup_cost;
1644 pathnode->path.total_cost = input_total_cost;
1645 }
1646 else
1648 pathkeys, list_length(subpaths),
1651 pathnode->path.rows);
1652
1653 return pathnode;
1654}
void cost_merge_append(Path *path, PlannerInfo *root, List *pathkeys, int n_streams, int input_disabled_nodes, Cost input_startup_cost, Cost input_total_cost, double tuples)
Definition costsize.c:2526
bool enable_incremental_sort
Definition costsize.c:152
bool pathkeys_count_contained_in(List *keys1, List *keys2, int *n_common)
Definition pathkeys.c:558

References Assert, bms_equal(), bms_is_empty, RelOptInfo::consider_parallel, cost_incremental_sort(), cost_merge_append(), cost_sort(), enable_incremental_sort, fb(), RelOptInfo::lateral_relids, lfirst, linitial, list_length(), makeNode, PATH_REQ_OUTER, pathkeys_count_contained_in(), RelOptInfo::relids, RelOptInfo::reltarget, root, subpath(), and work_mem.

Referenced by generate_orderedappend_paths(), and generate_union_paths().

◆ create_mergejoin_path()

MergePath * create_mergejoin_path ( PlannerInfo *  root,
RelOptInfo *  joinrel,
JoinType  jointype,
JoinCostWorkspace *  workspace,
JoinPathExtraData *  extra,
Path *  outer_path,
Path *  inner_path,
List *  restrict_clauses,
List *  pathkeys,
Relids  required_outer,
List *  mergeclauses,
List *  outersortkeys,
List *  innersortkeys,
int  outer_presorted_keys 
)
extern

Definition at line 2453 of file pathnode.c.

2467{
2469
2470 pathnode->jpath.path.pathtype = T_MergeJoin;
2471 pathnode->jpath.path.parent = joinrel;
2472 pathnode->jpath.path.pathtarget = joinrel->reltarget;
2473 pathnode->jpath.path.param_info =
2475 joinrel,
2476 outer_path,
2477 inner_path,
2478 extra->sjinfo,
2481 pathnode->jpath.path.parallel_aware = false;
2482 pathnode->jpath.path.parallel_safe = joinrel->consider_parallel &&
2483 outer_path->parallel_safe && inner_path->parallel_safe;
2484 /* This is a foolish way to estimate parallel_workers, but for now... */
2485 pathnode->jpath.path.parallel_workers = outer_path->parallel_workers;
2486 pathnode->jpath.path.pathkeys = pathkeys;
2487 pathnode->jpath.jointype = jointype;
2488 pathnode->jpath.inner_unique = extra->inner_unique;
2489 pathnode->jpath.outerjoinpath = outer_path;
2490 pathnode->jpath.innerjoinpath = inner_path;
2491 pathnode->jpath.joinrestrictinfo = restrict_clauses;
2492 pathnode->path_mergeclauses = mergeclauses;
2493 pathnode->outersortkeys = outersortkeys;
2494 pathnode->innersortkeys = innersortkeys;
2495 pathnode->outer_presorted_keys = outer_presorted_keys;
2496 /* pathnode->skip_mark_restore will be set by final_cost_mergejoin */
2497 /* pathnode->materialize_inner will be set by final_cost_mergejoin */
2498
2499 final_cost_mergejoin(root, pathnode, workspace, extra);
2500
2501 return pathnode;
2502}
void final_cost_mergejoin(PlannerInfo *root, MergePath *path, JoinCostWorkspace *workspace, JoinPathExtraData *extra)
Definition costsize.c:3978

References RelOptInfo::consider_parallel, fb(), final_cost_mergejoin(), get_joinrel_parampathinfo(), JoinPathExtraData::inner_unique, makeNode, RelOptInfo::reltarget, root, and JoinPathExtraData::sjinfo.

Referenced by try_mergejoin_path(), and try_partial_mergejoin_path().

◆ create_minmaxagg_path()

MinMaxAggPath * create_minmaxagg_path ( PlannerInfo *  root,
RelOptInfo *  rel,
PathTarget *  target,
List *  mmaggregates,
List *  quals 
)
extern

Definition at line 3312 of file pathnode.c.

3317{
3321 ListCell *lc;
3322
3323 /* The topmost generated Plan node will be a Result */
3324 pathnode->path.pathtype = T_Result;
3325 pathnode->path.parent = rel;
3326 pathnode->path.pathtarget = target;
3327 /* For now, assume we are above any joins, so no parameterization */
3328 pathnode->path.param_info = NULL;
3329 pathnode->path.parallel_aware = false;
3330 pathnode->path.parallel_safe = true; /* might change below */
3331 pathnode->path.parallel_workers = 0;
3332 /* Result is one unordered row */
3333 pathnode->path.rows = 1;
3334 pathnode->path.pathkeys = NIL;
3335
3336 pathnode->mmaggregates = mmaggregates;
3337 pathnode->quals = quals;
3338
3339 /* Calculate cost of all the initplans, and check parallel safety */
3340 initplan_cost = 0;
3341 foreach(lc, mmaggregates)
3342 {
3344
3346 initplan_cost += mminfo->pathcost;
3347 if (!mminfo->path->parallel_safe)
3348 pathnode->path.parallel_safe = false;
3349 }
3350
3351 /* add tlist eval cost for each output row, plus cpu_tuple_cost */
3352 pathnode->path.disabled_nodes = initplan_disabled_nodes;
3353 pathnode->path.startup_cost = initplan_cost + target->cost.startup;
3354 pathnode->path.total_cost = initplan_cost + target->cost.startup +
3355 target->cost.per_tuple + cpu_tuple_cost;
3356
3357 /*
3358 * Add cost of qual, if any --- but we ignore its selectivity, since our
3359 * rowcount estimate should be 1 no matter what the qual is.
3360 */
3361 if (quals)
3362 {
3364
3365 cost_qual_eval(&qual_cost, quals, root);
3366 pathnode->path.startup_cost += qual_cost.startup;
3367 pathnode->path.total_cost += qual_cost.startup + qual_cost.per_tuple;
3368 }
3369
3370 /*
3371 * If the initplans were all parallel-safe, also check safety of the
3372 * target and quals. (The Result node itself isn't parallelizable, but if
3373 * we are in a subquery then it can be useful for the outer query to know
3374 * that this one is parallel-safe.)
3375 */
3376 if (pathnode->path.parallel_safe)
3377 pathnode->path.parallel_safe =
3378 is_parallel_safe(root, (Node *) target->exprs) &&
3379 is_parallel_safe(root, (Node *) quals);
3380
3381 return pathnode;
3382}
int disabled_nodes
Definition pathnodes.h:2006

References PathTarget::cost, cost_qual_eval(), cpu_tuple_cost, Path::disabled_nodes, PathTarget::exprs, fb(), is_parallel_safe(), lfirst, makeNode, NIL, MinMaxAggInfo::path, QualCost::per_tuple, root, and QualCost::startup.

Referenced by preprocess_minmax_aggregates().

◆ create_modifytable_path()

ModifyTablePath * create_modifytable_path ( PlannerInfo *  root,
RelOptInfo *  rel,
Path *  subpath,
CmdType  operation,
bool  canSetTag,
Index  nominalRelation,
Index  rootRelation,
List *  resultRelations,
List *  updateColnosLists,
List *  withCheckOptionLists,
List *  returningLists,
List *  rowMarks,
OnConflictExpr *  onconflict,
List *  mergeActionLists,
List *  mergeJoinConditions,
ForPortionOfExpr *  forPortionOf,
int  epqParam 
)
extern

Definition at line 3712 of file pathnode.c.

3722{
3724
3726 (operation == CMD_UPDATE ?
3727 list_length(resultRelations) == list_length(updateColnosLists) :
3728 updateColnosLists == NIL));
3729 Assert(withCheckOptionLists == NIL ||
3730 list_length(resultRelations) == list_length(withCheckOptionLists));
3731 Assert(returningLists == NIL ||
3732 list_length(resultRelations) == list_length(returningLists));
3733
3734 pathnode->path.pathtype = T_ModifyTable;
3735 pathnode->path.parent = rel;
3736 /* pathtarget is not interesting, just make it minimally valid */
3737 pathnode->path.pathtarget = rel->reltarget;
3738 /* For now, assume we are above any joins, so no parameterization */
3739 pathnode->path.param_info = NULL;
3740 pathnode->path.parallel_aware = false;
3741 pathnode->path.parallel_safe = false;
3742 pathnode->path.parallel_workers = 0;
3743 pathnode->path.pathkeys = NIL;
3744
3745 /*
3746 * Compute cost & rowcount as subpath cost & rowcount (if RETURNING)
3747 *
3748 * Currently, we don't charge anything extra for the actual table
3749 * modification work, nor for the WITH CHECK OPTIONS or RETURNING
3750 * expressions if any. It would only be window dressing, since
3751 * ModifyTable is always a top-level node and there is no way for the
3752 * costs to change any higher-level planning choices. But we might want
3753 * to make it look better sometime.
3754 */
3755 pathnode->path.disabled_nodes = subpath->disabled_nodes;
3756 pathnode->path.startup_cost = subpath->startup_cost;
3757 pathnode->path.total_cost = subpath->total_cost;
3758 if (returningLists != NIL)
3759 {
3760 pathnode->path.rows = subpath->rows;
3761
3762 /*
3763 * Set width to match the subpath output. XXX this is totally wrong:
3764 * we should return an average of the RETURNING tlist widths. But
3765 * it's what happened historically, and improving it is a task for
3766 * another day. (Again, it's mostly window dressing.)
3767 */
3768 pathnode->path.pathtarget->width = subpath->pathtarget->width;
3769 }
3770 else
3771 {
3772 pathnode->path.rows = 0;
3773 pathnode->path.pathtarget->width = 0;
3774 }
3775
3776 pathnode->subpath = subpath;
3777 pathnode->operation = operation;
3778 pathnode->canSetTag = canSetTag;
3779 pathnode->nominalRelation = nominalRelation;
3780 pathnode->rootRelation = rootRelation;
3781 pathnode->resultRelations = resultRelations;
3782 pathnode->updateColnosLists = updateColnosLists;
3783 pathnode->withCheckOptionLists = withCheckOptionLists;
3784 pathnode->returningLists = returningLists;
3785 pathnode->rowMarks = rowMarks;
3786 pathnode->onconflict = onconflict;
3787 pathnode->forPortionOf = forPortionOf;
3788 pathnode->epqParam = epqParam;
3789 pathnode->mergeActionLists = mergeActionLists;
3790 pathnode->mergeJoinConditions = mergeJoinConditions;
3791
3792 return pathnode;
3793}
static DataChecksumsWorkerOperation operation
@ CMD_MERGE
Definition nodes.h:277
@ CMD_UPDATE
Definition nodes.h:274

References Assert, CMD_MERGE, CMD_UPDATE, fb(), list_length(), makeNode, NIL, operation, RelOptInfo::reltarget, subpath(), and PathTarget::width.

Referenced by grouping_planner().

◆ create_namedtuplestorescan_path()

Path * create_namedtuplestorescan_path ( PlannerInfo *  root,
RelOptInfo *  rel,
Relids  required_outer 
)
extern

Definition at line 2043 of file pathnode.c.

2045{
2047
2048 pathnode->pathtype = T_NamedTuplestoreScan;
2049 pathnode->parent = rel;
2050 pathnode->pathtarget = rel->reltarget;
2051 pathnode->param_info = get_baserel_parampathinfo(root, rel,
2053 pathnode->parallel_aware = false;
2054 pathnode->parallel_safe = rel->consider_parallel;
2055 pathnode->parallel_workers = 0;
2056 pathnode->pathkeys = NIL; /* result is always unordered */
2057
2058 cost_namedtuplestorescan(pathnode, root, rel, pathnode->param_info);
2059
2060 return pathnode;
2061}
void cost_namedtuplestorescan(Path *path, PlannerInfo *root, RelOptInfo *baserel, ParamPathInfo *param_info)
Definition costsize.c:1792

References RelOptInfo::consider_parallel, cost_namedtuplestorescan(), fb(), get_baserel_parampathinfo(), makeNode, NIL, RelOptInfo::reltarget, and root.

Referenced by set_namedtuplestore_pathlist().

◆ create_nestloop_path()

NestPath * create_nestloop_path ( PlannerInfo *  root,
RelOptInfo *  joinrel,
JoinType  jointype,
JoinCostWorkspace *  workspace,
JoinPathExtraData *  extra,
Path *  outer_path,
Path *  inner_path,
List *  restrict_clauses,
List *  pathkeys,
Relids  required_outer 
)
extern

Definition at line 2356 of file pathnode.c.

2366{
2369 Relids outerrelids;
2370
2371 /*
2372 * Paths are parameterized by top-level parents, so run parameterization
2373 * tests on the parent relids.
2374 */
2375 if (outer_path->parent->top_parent_relids)
2376 outerrelids = outer_path->parent->top_parent_relids;
2377 else
2378 outerrelids = outer_path->parent->relids;
2379
2380 /*
2381 * If the inner path is parameterized by the outer, we must drop any
2382 * restrict_clauses that are due to be moved into the inner path. We have
2383 * to do this now, rather than postpone the work till createplan time,
2384 * because the restrict_clauses list can affect the size and cost
2385 * estimates for this path. We detect such clauses by checking for serial
2386 * number match to clauses already enforced in the inner path.
2387 */
2388 if (bms_overlap(inner_req_outer, outerrelids))
2389 {
2391 List *jclauses = NIL;
2392 ListCell *lc;
2393
2394 foreach(lc, restrict_clauses)
2395 {
2396 RestrictInfo *rinfo = (RestrictInfo *) lfirst(lc);
2397
2399 jclauses = lappend(jclauses, rinfo);
2400 }
2402 }
2403
2404 pathnode->jpath.path.pathtype = T_NestLoop;
2405 pathnode->jpath.path.parent = joinrel;
2406 pathnode->jpath.path.pathtarget = joinrel->reltarget;
2407 pathnode->jpath.path.param_info =
2409 joinrel,
2410 outer_path,
2411 inner_path,
2412 extra->sjinfo,
2415 pathnode->jpath.path.parallel_aware = false;
2416 pathnode->jpath.path.parallel_safe = joinrel->consider_parallel &&
2417 outer_path->parallel_safe && inner_path->parallel_safe;
2418 /* This is a foolish way to estimate parallel_workers, but for now... */
2419 pathnode->jpath.path.parallel_workers = outer_path->parallel_workers;
2420 pathnode->jpath.path.pathkeys = pathkeys;
2421 pathnode->jpath.jointype = jointype;
2422 pathnode->jpath.inner_unique = extra->inner_unique;
2423 pathnode->jpath.outerjoinpath = outer_path;
2424 pathnode->jpath.innerjoinpath = inner_path;
2425 pathnode->jpath.joinrestrictinfo = restrict_clauses;
2426
2427 final_cost_nestloop(root, pathnode, workspace, extra);
2428
2429 return pathnode;
2430}
bool bms_is_member(int x, const Bitmapset *a)
Definition bitmapset.c:645
void final_cost_nestloop(PlannerInfo *root, NestPath *path, JoinCostWorkspace *workspace, JoinPathExtraData *extra)
Definition costsize.c:3478
Bitmapset * get_param_path_clause_serials(Path *path)
Definition relnode.c:2069

References bms_is_member(), bms_overlap(), RelOptInfo::consider_parallel, fb(), final_cost_nestloop(), get_joinrel_parampathinfo(), get_param_path_clause_serials(), JoinPathExtraData::inner_unique, lappend(), lfirst, makeNode, NIL, PATH_REQ_OUTER, RelOptInfo::reltarget, RestrictInfo::rinfo_serial, root, and JoinPathExtraData::sjinfo.

Referenced by try_nestloop_path(), and try_partial_nestloop_path().

◆ create_projection_path()

ProjectionPath * create_projection_path ( PlannerInfo *  root,
RelOptInfo *  rel,
Path *  subpath,
PathTarget *  target 
)
extern

Definition at line 2587 of file pathnode.c.

2591{
2594
2595 /*
2596 * We mustn't put a ProjectionPath directly above another; it's useless
2597 * and will confuse create_projection_plan. Rather than making sure all
2598 * callers handle that, let's implement it here, by stripping off any
2599 * ProjectionPath in what we're given. Given this rule, there won't be
2600 * more than one.
2601 */
2603 {
2605
2606 Assert(subpp->path.parent == rel);
2607 subpath = subpp->subpath;
2609 }
2610
2611 pathnode->path.pathtype = T_Result;
2612 pathnode->path.parent = rel;
2613 pathnode->path.pathtarget = target;
2614 pathnode->path.param_info = subpath->param_info;
2615 pathnode->path.parallel_aware = false;
2616 pathnode->path.parallel_safe = rel->consider_parallel &&
2617 subpath->parallel_safe &&
2618 is_parallel_safe(root, (Node *) target->exprs);
2619 pathnode->path.parallel_workers = subpath->parallel_workers;
2620 /* Projection does not change the sort order */
2621 pathnode->path.pathkeys = subpath->pathkeys;
2622
2623 pathnode->subpath = subpath;
2624
2625 /*
2626 * We might not need a separate Result node. If the input plan node type
2627 * can project, we can just tell it to project something else. Or, if it
2628 * can't project but the desired target has the same expression list as
2629 * what the input will produce anyway, we can still give it the desired
2630 * tlist (possibly changing its ressortgroupref labels, but nothing else).
2631 * Note: in the latter case, create_projection_plan has to recheck our
2632 * conclusion; see comments therein.
2633 */
2634 oldtarget = subpath->pathtarget;
2636 equal(oldtarget->exprs, target->exprs))
2637 {
2638 /* No separate Result node needed */
2639 pathnode->dummypp = true;
2640
2641 /*
2642 * Set cost of plan as subpath's cost, adjusted for tlist replacement.
2643 */
2644 pathnode->path.rows = subpath->rows;
2645 pathnode->path.disabled_nodes = subpath->disabled_nodes;
2646 pathnode->path.startup_cost = subpath->startup_cost +
2647 (target->cost.startup - oldtarget->cost.startup);
2648 pathnode->path.total_cost = subpath->total_cost +
2649 (target->cost.startup - oldtarget->cost.startup) +
2650 (target->cost.per_tuple - oldtarget->cost.per_tuple) * subpath->rows;
2651 }
2652 else
2653 {
2654 /* We really do need the Result node */
2655 pathnode->dummypp = false;
2656
2657 /*
2658 * The Result node's cost is cpu_tuple_cost per row, plus the cost of
2659 * evaluating the tlist. There is no qual to worry about.
2660 */
2661 pathnode->path.rows = subpath->rows;
2662 pathnode->path.disabled_nodes = subpath->disabled_nodes;
2663 pathnode->path.startup_cost = subpath->startup_cost +
2664 target->cost.startup;
2665 pathnode->path.total_cost = subpath->total_cost +
2666 target->cost.startup +
2667 (cpu_tuple_cost + target->cost.per_tuple) * subpath->rows;
2668 }
2669
2670 return pathnode;
2671}
bool equal(const void *a, const void *b)
Definition equalfuncs.c:223

References Assert, RelOptInfo::consider_parallel, PathTarget::cost, cpu_tuple_cost, equal(), PathTarget::exprs, fb(), is_parallel_safe(), is_projection_capable_path(), IsA, makeNode, QualCost::per_tuple, root, QualCost::startup, and subpath().

Referenced by add_paths_with_pathkeys_for_rel(), adjust_paths_for_srfs(), apply_projection_to_path(), apply_scanjoin_target_to_paths(), create_final_unique_paths(), create_partial_grouping_paths(), create_partial_unique_paths(), generate_grouped_paths(), and recurse_set_operations().

◆ create_recursiveunion_path()

RecursiveUnionPath * create_recursiveunion_path ( PlannerInfo *  root,
RelOptInfo *  rel,
Path *  leftpath,
Path *  rightpath,
PathTarget *  target,
List *  distinctList,
int  wtParam,
double  numGroups 
)
extern

Definition at line 3605 of file pathnode.c.

3613{
3615
3616 pathnode->path.pathtype = T_RecursiveUnion;
3617 pathnode->path.parent = rel;
3618 pathnode->path.pathtarget = target;
3619 /* For now, assume we are above any joins, so no parameterization */
3620 pathnode->path.param_info = NULL;
3621 pathnode->path.parallel_aware = false;
3622 pathnode->path.parallel_safe = rel->consider_parallel &&
3623 leftpath->parallel_safe && rightpath->parallel_safe;
3624 /* Foolish, but we'll do it like joins for now: */
3625 pathnode->path.parallel_workers = leftpath->parallel_workers;
3626 /* RecursiveUnion result is always unsorted */
3627 pathnode->path.pathkeys = NIL;
3628
3629 pathnode->leftpath = leftpath;
3630 pathnode->rightpath = rightpath;
3631 pathnode->distinctList = distinctList;
3632 pathnode->wtParam = wtParam;
3633 pathnode->numGroups = numGroups;
3634
3635 cost_recursive_union(&pathnode->path, leftpath, rightpath);
3636
3637 return pathnode;
3638}
void cost_recursive_union(Path *runion, Path *nrterm, Path *rterm)
Definition costsize.c:1876
int parallel_workers
Definition pathnodes.h:2002

References RelOptInfo::consider_parallel, cost_recursive_union(), fb(), makeNode, NIL, Path::parallel_safe, and Path::parallel_workers.

Referenced by generate_recursion_path().

◆ create_rel_agg_info()

RelAggInfo * create_rel_agg_info ( PlannerInfo *  root,
RelOptInfo *  rel,
bool  calculate_grouped_rows 
)
extern

Definition at line 2691 of file relnode.c.

2693{
2694 ListCell *lc;
2696 PathTarget *agg_input;
2697 PathTarget *target;
2698 List *group_clauses = NIL;
2699 List *group_exprs = NIL;
2700
2701 /*
2702 * The lists of aggregate expressions and grouping expressions should have
2703 * been constructed.
2704 */
2705 Assert(root->agg_clause_list != NIL);
2706 Assert(root->group_expr_list != NIL);
2707
2708 /*
2709 * If this is a child rel, the grouped rel for its parent rel must have
2710 * been created if it can. So we can just use parent's RelAggInfo if
2711 * there is one, with appropriate variable substitutions.
2712 */
2713 if (IS_OTHER_REL(rel))
2714 {
2715 RelOptInfo *grouped_rel;
2716 RelAggInfo *agg_info;
2717
2718 grouped_rel = rel->top_parent->grouped_rel;
2719 if (grouped_rel == NULL)
2720 return NULL;
2721
2722 Assert(IS_GROUPED_REL(grouped_rel));
2723
2724 /* Must do multi-level transformation */
2725 agg_info = (RelAggInfo *)
2727 (Node *) grouped_rel->agg_info,
2728 rel,
2729 rel->top_parent);
2730
2731 agg_info->apply_agg_at = NULL; /* caller will change this later */
2732
2734 {
2735 agg_info->grouped_rows =
2737 rel->rows, NULL, NULL);
2738
2739 /*
2740 * The grouped paths for the given relation are considered useful
2741 * iff the average group size is no less than
2742 * min_eager_agg_group_size.
2743 */
2744 agg_info->agg_useful =
2745 (rel->rows / agg_info->grouped_rows) >= min_eager_agg_group_size;
2746 }
2747
2748 return agg_info;
2749 }
2750
2751 /* Check if it's possible to produce grouped paths for this relation. */
2753 return NULL;
2754
2755 /*
2756 * Create targets for the grouped paths and for the input paths of the
2757 * grouped paths.
2758 */
2759 target = create_empty_pathtarget();
2760 agg_input = create_empty_pathtarget();
2761
2762 /* ... and initialize these targets */
2763 if (!init_grouping_targets(root, rel, target, agg_input,
2764 &group_clauses, &group_exprs))
2765 return NULL;
2766
2767 /*
2768 * Eager aggregation is not applicable if there are no available grouping
2769 * expressions.
2770 */
2771 if (group_clauses == NIL)
2772 return NULL;
2773
2774 /* Add aggregates to the grouping target */
2775 foreach(lc, root->agg_clause_list)
2776 {
2778 Aggref *aggref;
2779
2780 Assert(IsA(ac_info->aggref, Aggref));
2781
2782 aggref = (Aggref *) copyObject(ac_info->aggref);
2784
2785 add_column_to_pathtarget(target, (Expr *) aggref, 0);
2786 }
2787
2788 /* Set the estimated eval cost and output width for both targets */
2790 set_pathtarget_cost_width(root, agg_input);
2791
2792 /* build the RelAggInfo result */
2794 result->target = target;
2795 result->agg_input = agg_input;
2796 result->group_clauses = group_clauses;
2797 result->group_exprs = group_exprs;
2798 result->apply_agg_at = NULL; /* caller will change this later */
2799
2801 {
2802 result->grouped_rows = estimate_num_groups(root, result->group_exprs,
2803 rel->rows, NULL, NULL);
2804
2805 /*
2806 * The grouped paths for the given relation are considered useful iff
2807 * the average group size is no less than min_eager_agg_group_size.
2808 */
2809 result->agg_useful =
2810 (rel->rows / result->grouped_rows) >= min_eager_agg_group_size;
2811 }
2812
2813 return result;
2814}
double min_eager_agg_group_size
Definition allpaths.c:84
Node * adjust_appendrel_attrs_multilevel(PlannerInfo *root, Node *node, RelOptInfo *childrel, RelOptInfo *parentrel)
Definition appendinfo.c:597
uint32 result
PathTarget * set_pathtarget_cost_width(PlannerInfo *root, PathTarget *target)
Definition costsize.c:6534
#define copyObject(obj)
Definition nodes.h:230
@ AGGSPLIT_INITIAL_SERIAL
Definition nodes.h:387
#define IS_GROUPED_REL(rel)
Definition pathnodes.h:1257
#define lfirst_node(type, lc)
Definition pg_list.h:176
void mark_partial_aggref(Aggref *agg, AggSplit aggsplit)
Definition planner.c:6009
static bool init_grouping_targets(PlannerInfo *root, RelOptInfo *rel, PathTarget *target, PathTarget *agg_input, List **group_clauses, List **group_exprs)
Definition relnode.c:2927
static bool eager_aggregation_possible_for_relation(PlannerInfo *root, RelOptInfo *rel)
Definition relnode.c:2821
double estimate_num_groups(PlannerInfo *root, List *groupExprs, double input_rows, List **pgset, EstimationInfo *estinfo)
Definition selfuncs.c:3804
List * group_exprs
Definition pathnodes.h:1299
void add_column_to_pathtarget(PathTarget *target, Expr *expr, Index sortgroupref)
Definition tlist.c:704

References add_column_to_pathtarget(), adjust_appendrel_attrs_multilevel(), RelOptInfo::agg_info, RelAggInfo::agg_useful, AGGSPLIT_INITIAL_SERIAL, RelAggInfo::apply_agg_at, Assert, copyObject, create_empty_pathtarget(), eager_aggregation_possible_for_relation(), estimate_num_groups(), fb(), RelAggInfo::group_exprs, RelOptInfo::grouped_rel, RelAggInfo::grouped_rows, init_grouping_targets(), IS_GROUPED_REL, IS_OTHER_REL, IsA, lfirst_node, makeNode, mark_partial_aggref(), min_eager_agg_group_size, NIL, result, root, RelOptInfo::rows, and set_pathtarget_cost_width().

Referenced by build_simple_grouped_rel(), and make_grouped_join_rel().

◆ create_resultscan_path()

Path * create_resultscan_path ( PlannerInfo *  root,
RelOptInfo *  rel,
Relids  required_outer 
)
extern

Definition at line 2069 of file pathnode.c.

2071{
2073
2074 pathnode->pathtype = T_Result;
2075 pathnode->parent = rel;
2076 pathnode->pathtarget = rel->reltarget;
2077 pathnode->param_info = get_baserel_parampathinfo(root, rel,
2079 pathnode->parallel_aware = false;
2080 pathnode->parallel_safe = rel->consider_parallel;
2081 pathnode->parallel_workers = 0;
2082 pathnode->pathkeys = NIL; /* result is always unordered */
2083
2084 cost_resultscan(pathnode, root, rel, pathnode->param_info);
2085
2086 return pathnode;
2087}
void cost_resultscan(Path *path, PlannerInfo *root, RelOptInfo *baserel, ParamPathInfo *param_info)
Definition costsize.c:1834

References RelOptInfo::consider_parallel, cost_resultscan(), fb(), get_baserel_parampathinfo(), makeNode, NIL, RelOptInfo::reltarget, and root.

Referenced by reparameterize_path(), and set_result_pathlist().

◆ create_samplescan_path()

Path * create_samplescan_path ( PlannerInfo *  root,
RelOptInfo *  rel,
Relids  required_outer 
)
extern

Definition at line 1051 of file pathnode.c.

1052{
1054
1055 pathnode->pathtype = T_SampleScan;
1056 pathnode->parent = rel;
1057 pathnode->pathtarget = rel->reltarget;
1058 pathnode->param_info = get_baserel_parampathinfo(root, rel,
1060 pathnode->parallel_aware = false;
1061 pathnode->parallel_safe = rel->consider_parallel;
1062 pathnode->parallel_workers = 0;
1063 pathnode->pathkeys = NIL; /* samplescan has unordered result */
1064
1065 cost_samplescan(pathnode, root, rel, pathnode->param_info);
1066
1067 return pathnode;
1068}
void cost_samplescan(Path *path, PlannerInfo *root, RelOptInfo *baserel, ParamPathInfo *param_info)
Definition costsize.c:350

References RelOptInfo::consider_parallel, cost_samplescan(), fb(), get_baserel_parampathinfo(), makeNode, NIL, RelOptInfo::reltarget, and root.

Referenced by reparameterize_path(), and set_tablesample_rel_pathlist().

◆ create_seqscan_path()

Path * create_seqscan_path ( PlannerInfo *  root,
RelOptInfo *  rel,
Relids  required_outer,
int  parallel_workers 
)
extern

Definition at line 1026 of file pathnode.c.

1028{
1030
1031 pathnode->pathtype = T_SeqScan;
1032 pathnode->parent = rel;
1033 pathnode->pathtarget = rel->reltarget;
1034 pathnode->param_info = get_baserel_parampathinfo(root, rel,
1036 pathnode->parallel_aware = (parallel_workers > 0);
1037 pathnode->parallel_safe = rel->consider_parallel;
1038 pathnode->parallel_workers = parallel_workers;
1039 pathnode->pathkeys = NIL; /* seqscan has unordered result */
1040
1041 cost_seqscan(pathnode, root, rel, pathnode->param_info);
1042
1043 return pathnode;
1044}
void cost_seqscan(Path *path, PlannerInfo *root, RelOptInfo *baserel, ParamPathInfo *param_info)
Definition costsize.c:271

References RelOptInfo::consider_parallel, cost_seqscan(), fb(), get_baserel_parampathinfo(), makeNode, NIL, RelOptInfo::reltarget, and root.

Referenced by create_plain_partial_paths(), plan_cluster_use_sort(), reparameterize_path(), and set_plain_rel_pathlist().

◆ create_set_projection_path()

ProjectSetPath * create_set_projection_path ( PlannerInfo *  root,
RelOptInfo *  rel,
Path *  subpath,
PathTarget *  target 
)
extern

Definition at line 2785 of file pathnode.c.

2789{
2791 double tlist_rows;
2792 ListCell *lc;
2793
2794 pathnode->path.pathtype = T_ProjectSet;
2795 pathnode->path.parent = rel;
2796 pathnode->path.pathtarget = target;
2797 /* For now, assume we are above any joins, so no parameterization */
2798 pathnode->path.param_info = NULL;
2799 pathnode->path.parallel_aware = false;
2800 pathnode->path.parallel_safe = rel->consider_parallel &&
2801 subpath->parallel_safe &&
2802 is_parallel_safe(root, (Node *) target->exprs);
2803 pathnode->path.parallel_workers = subpath->parallel_workers;
2804 /* Projection does not change the sort order XXX? */
2805 pathnode->path.pathkeys = subpath->pathkeys;
2806
2807 pathnode->subpath = subpath;
2808
2809 /*
2810 * Estimate number of rows produced by SRFs for each row of input; if
2811 * there's more than one in this node, use the maximum.
2812 */
2813 tlist_rows = 1;
2814 foreach(lc, target->exprs)
2815 {
2816 Node *node = (Node *) lfirst(lc);
2817 double itemrows;
2818
2820 if (tlist_rows < itemrows)
2822 }
2823
2824 /*
2825 * In addition to the cost of evaluating the tlist, charge cpu_tuple_cost
2826 * per input row, and half of cpu_tuple_cost for each added output row.
2827 * This is slightly bizarre maybe, but it's what 9.6 did; we may revisit
2828 * this estimate later.
2829 */
2830 pathnode->path.disabled_nodes = subpath->disabled_nodes;
2831 pathnode->path.rows = subpath->rows * tlist_rows;
2832 pathnode->path.startup_cost = subpath->startup_cost +
2833 target->cost.startup;
2834 pathnode->path.total_cost = subpath->total_cost +
2835 target->cost.startup +
2836 (cpu_tuple_cost + target->cost.per_tuple) * subpath->rows +
2837 (pathnode->path.rows - subpath->rows) * cpu_tuple_cost / 2;
2838
2839 return pathnode;
2840}
double expression_returns_set_rows(PlannerInfo *root, Node *clause)
Definition clauses.c:318

References RelOptInfo::consider_parallel, PathTarget::cost, cpu_tuple_cost, expression_returns_set_rows(), PathTarget::exprs, fb(), is_parallel_safe(), lfirst, makeNode, QualCost::per_tuple, root, QualCost::startup, and subpath().

Referenced by adjust_paths_for_srfs().

◆ create_setop_path()

SetOpPath * create_setop_path ( PlannerInfo *  root,
RelOptInfo *  rel,
Path *  leftpath,
Path *  rightpath,
SetOpCmd  cmd,
SetOpStrategy  strategy,
List *  groupList,
double  numGroups,
double  outputRows 
)
extern

Definition at line 3476 of file pathnode.c.

3485{
3487
3488 pathnode->path.pathtype = T_SetOp;
3489 pathnode->path.parent = rel;
3490 pathnode->path.pathtarget = rel->reltarget;
3491 /* For now, assume we are above any joins, so no parameterization */
3492 pathnode->path.param_info = NULL;
3493 pathnode->path.parallel_aware = false;
3494 pathnode->path.parallel_safe = rel->consider_parallel &&
3495 leftpath->parallel_safe && rightpath->parallel_safe;
3496 pathnode->path.parallel_workers =
3497 leftpath->parallel_workers + rightpath->parallel_workers;
3498 /* SetOp preserves the input sort order if in sort mode */
3499 pathnode->path.pathkeys =
3500 (strategy == SETOP_SORTED) ? leftpath->pathkeys : NIL;
3501
3502 pathnode->leftpath = leftpath;
3503 pathnode->rightpath = rightpath;
3504 pathnode->cmd = cmd;
3505 pathnode->strategy = strategy;
3506 pathnode->groupList = groupList;
3507 pathnode->numGroups = numGroups;
3508
3509 /*
3510 * Compute cost estimates. As things stand, we end up with the same total
3511 * cost in this node for sort and hash methods, but different startup
3512 * costs. This could be refined perhaps, but it'll do for now.
3513 */
3514 pathnode->path.disabled_nodes =
3515 leftpath->disabled_nodes + rightpath->disabled_nodes;
3516 if (strategy == SETOP_SORTED)
3517 {
3518 /*
3519 * In sorted mode, we can emit output incrementally. Charge one
3520 * cpu_operator_cost per comparison per input tuple. Like cost_group,
3521 * we assume all columns get compared at most of the tuples.
3522 */
3523 pathnode->path.startup_cost =
3524 leftpath->startup_cost + rightpath->startup_cost;
3525 pathnode->path.total_cost =
3526 leftpath->total_cost + rightpath->total_cost +
3527 cpu_operator_cost * (leftpath->rows + rightpath->rows) * list_length(groupList);
3528
3529 /*
3530 * Also charge a small amount per extracted tuple. Like cost_sort,
3531 * charge only operator cost not cpu_tuple_cost, since SetOp does no
3532 * qual-checking or projection.
3533 */
3534 pathnode->path.total_cost += cpu_operator_cost * outputRows;
3535
3536 /*
3537 * Mark the path as disabled if enable_groupagg is off. While this
3538 * isn't a grouping Agg node, it is the sort-based implementation and
3539 * so is the natural counterpart to the SETOP_HASHED path that
3540 * enable_hashagg controls; it seems close enough to justify letting
3541 * that switch control it.
3542 */
3543 if (!enable_groupagg)
3544 pathnode->path.disabled_nodes++;
3545 }
3546 else
3547 {
3549
3550 /*
3551 * In hashed mode, we must read all the input before we can emit
3552 * anything. Also charge comparison costs to represent the cost of
3553 * hash table lookups.
3554 */
3555 pathnode->path.startup_cost =
3556 leftpath->total_cost + rightpath->total_cost +
3557 cpu_operator_cost * (leftpath->rows + rightpath->rows) * list_length(groupList);
3558 pathnode->path.total_cost = pathnode->path.startup_cost;
3559
3560 /*
3561 * Also charge a small amount per extracted tuple. Like cost_sort,
3562 * charge only operator cost not cpu_tuple_cost, since SetOp does no
3563 * qual-checking or projection.
3564 */
3565 pathnode->path.total_cost += cpu_operator_cost * outputRows;
3566
3567 /*
3568 * Mark the path as disabled if enable_hashagg is off. While this
3569 * isn't exactly a HashAgg node, it seems close enough to justify
3570 * letting that switch control it.
3571 */
3572 if (!enable_hashagg)
3573 pathnode->path.disabled_nodes++;
3574
3575 /*
3576 * Also disable if it doesn't look like the hashtable will fit into
3577 * hash_mem. (Note: reject on equality, to ensure that an estimate of
3578 * SIZE_MAX disables hashing regardless of the hash_mem limit.)
3579 */
3581 leftpath->pathtarget->width);
3583 pathnode->path.disabled_nodes++;
3584 }
3585 pathnode->path.rows = outputRows;
3586
3587 return pathnode;
3588}
size_t Size
Definition c.h:748
double cpu_operator_cost
Definition costsize.c:135
bool enable_groupagg
Definition costsize.c:154
bool enable_hashagg
Definition costsize.c:153
size_t get_hash_memory_limit(void)
Definition nodeHash.c:3680
Size EstimateSetOpHashTableSpace(double nentries, Size tupleWidth)
Definition nodeSetOp.c:116
@ SETOP_SORTED
Definition nodes.h:414

References RelOptInfo::consider_parallel, cpu_operator_cost, Path::disabled_nodes, enable_groupagg, enable_hashagg, EstimateSetOpHashTableSpace(), fb(), get_hash_memory_limit(), list_length(), makeNode, NIL, Path::parallel_safe, Path::parallel_workers, Path::pathkeys, RelOptInfo::reltarget, Path::rows, SETOP_SORTED, Path::startup_cost, and Path::total_cost.

Referenced by generate_nonunion_paths().

◆ create_sort_path()

SortPath * create_sort_path ( PlannerInfo *  root,
RelOptInfo *  rel,
Path *  subpath,
List *  pathkeys,
double  limit_tuples 
)
extern

Definition at line 2904 of file pathnode.c.

2909{
2911
2912 pathnode->path.pathtype = T_Sort;
2913 pathnode->path.parent = rel;
2914 /* Sort doesn't project, so use source path's pathtarget */
2915 pathnode->path.pathtarget = subpath->pathtarget;
2916 pathnode->path.param_info = subpath->param_info;
2917 pathnode->path.parallel_aware = false;
2918 pathnode->path.parallel_safe = rel->consider_parallel &&
2919 subpath->parallel_safe;
2920 pathnode->path.parallel_workers = subpath->parallel_workers;
2921 pathnode->path.pathkeys = pathkeys;
2922
2923 pathnode->subpath = subpath;
2924
2925 cost_sort(&pathnode->path, root, pathkeys,
2926 subpath->disabled_nodes,
2927 subpath->total_cost,
2928 subpath->rows,
2929 subpath->pathtarget->width,
2930 0.0, /* XXX comparison_cost shouldn't be 0? */
2931 work_mem, limit_tuples);
2932
2933 return pathnode;
2934}

References RelOptInfo::consider_parallel, cost_sort(), fb(), makeNode, root, subpath(), and work_mem.

Referenced by add_paths_with_pathkeys_for_rel(), build_setop_child_paths(), create_final_unique_paths(), create_one_window_path(), create_ordered_paths(), create_partial_unique_paths(), gather_grouping_paths(), generate_grouped_paths(), generate_nonunion_paths(), generate_union_paths(), generate_useful_gather_paths(), and make_ordered_path().

◆ create_subqueryscan_path()

SubqueryScanPath * create_subqueryscan_path ( PlannerInfo *  root,
RelOptInfo *  rel,
Path *  subpath,
bool  trivial_pathtarget,
List *  pathkeys,
Relids  required_outer 
)
extern

Definition at line 1909 of file pathnode.c.

1912{
1914
1915 pathnode->path.pathtype = T_SubqueryScan;
1916 pathnode->path.parent = rel;
1917 pathnode->path.pathtarget = rel->reltarget;
1918 pathnode->path.param_info = get_baserel_parampathinfo(root, rel,
1920 pathnode->path.parallel_aware = false;
1921 pathnode->path.parallel_safe = rel->consider_parallel &&
1922 subpath->parallel_safe;
1923 pathnode->path.parallel_workers = subpath->parallel_workers;
1924 pathnode->path.pathkeys = pathkeys;
1925 pathnode->subpath = subpath;
1926
1927 cost_subqueryscan(pathnode, root, rel, pathnode->path.param_info,
1929
1930 return pathnode;
1931}
void cost_subqueryscan(SubqueryScanPath *path, PlannerInfo *root, RelOptInfo *baserel, ParamPathInfo *param_info, bool trivial_pathtarget)
Definition costsize.c:1479

References RelOptInfo::consider_parallel, cost_subqueryscan(), fb(), get_baserel_parampathinfo(), makeNode, RelOptInfo::reltarget, root, and subpath().

Referenced by build_setop_child_paths(), reparameterize_path(), and set_subquery_pathlist().

◆ create_tablefuncscan_path()

Path * create_tablefuncscan_path ( PlannerInfo *  root,
RelOptInfo *  rel,
Relids  required_outer 
)
extern

Definition at line 1965 of file pathnode.c.

1967{
1969
1970 pathnode->pathtype = T_TableFuncScan;
1971 pathnode->parent = rel;
1972 pathnode->pathtarget = rel->reltarget;
1973 pathnode->param_info = get_baserel_parampathinfo(root, rel,
1975 pathnode->parallel_aware = false;
1976 pathnode->parallel_safe = rel->consider_parallel;
1977 pathnode->parallel_workers = 0;
1978 pathnode->pathkeys = NIL; /* result is always unordered */
1979
1980 cost_tablefuncscan(pathnode, root, rel, pathnode->param_info);
1981
1982 return pathnode;
1983}
void cost_tablefuncscan(Path *path, PlannerInfo *root, RelOptInfo *baserel, ParamPathInfo *param_info)
Definition costsize.c:1630

References RelOptInfo::consider_parallel, cost_tablefuncscan(), fb(), get_baserel_parampathinfo(), makeNode, NIL, RelOptInfo::reltarget, and root.

Referenced by set_tablefunc_pathlist().

◆ create_tidrangescan_path()

TidRangePath * create_tidrangescan_path ( PlannerInfo *  root,
RelOptInfo *  rel,
List *  tidrangequals,
Relids  required_outer,
int  parallel_workers 
)
extern

Definition at line 1315 of file pathnode.c.

1318{
1320
1321 pathnode->path.pathtype = T_TidRangeScan;
1322 pathnode->path.parent = rel;
1323 pathnode->path.pathtarget = rel->reltarget;
1324 pathnode->path.param_info = get_baserel_parampathinfo(root, rel,
1326 pathnode->path.parallel_aware = (parallel_workers > 0);
1327 pathnode->path.parallel_safe = rel->consider_parallel;
1328 pathnode->path.parallel_workers = parallel_workers;
1329 pathnode->path.pathkeys = NIL; /* always unordered */
1330
1331 pathnode->tidrangequals = tidrangequals;
1332
1333 cost_tidrangescan(&pathnode->path, root, rel, tidrangequals,
1334 pathnode->path.param_info);
1335
1336 return pathnode;
1337}
void cost_tidrangescan(Path *path, PlannerInfo *root, RelOptInfo *baserel, List *tidrangequals, ParamPathInfo *param_info)
Definition costsize.c:1362

References RelOptInfo::consider_parallel, cost_tidrangescan(), fb(), get_baserel_parampathinfo(), makeNode, NIL, RelOptInfo::reltarget, and root.

Referenced by create_tidscan_paths().

◆ create_tidscan_path()

TidPath * create_tidscan_path ( PlannerInfo *  root,
RelOptInfo *  rel,
List *  tidquals,
Relids  required_outer 
)
extern

Definition at line 1286 of file pathnode.c.

1288{
1290
1291 pathnode->path.pathtype = T_TidScan;
1292 pathnode->path.parent = rel;
1293 pathnode->path.pathtarget = rel->reltarget;
1294 pathnode->path.param_info = get_baserel_parampathinfo(root, rel,
1296 pathnode->path.parallel_aware = false;
1297 pathnode->path.parallel_safe = rel->consider_parallel;
1298 pathnode->path.parallel_workers = 0;
1299 pathnode->path.pathkeys = NIL; /* always unordered */
1300
1301 pathnode->tidquals = tidquals;
1302
1303 cost_tidscan(&pathnode->path, root, rel, tidquals,
1304 pathnode->path.param_info);
1305
1306 return pathnode;
1307}
void cost_tidscan(Path *path, PlannerInfo *root, RelOptInfo *baserel, List *tidquals, ParamPathInfo *param_info)
Definition costsize.c:1252

References RelOptInfo::consider_parallel, cost_tidscan(), fb(), get_baserel_parampathinfo(), makeNode, NIL, RelOptInfo::reltarget, and root.

Referenced by BuildParameterizedTidPaths(), and create_tidscan_paths().

◆ create_unique_path()

UniquePath * create_unique_path ( PlannerInfo *  root,
RelOptInfo *  rel,
Path *  subpath,
int  numCols,
double  numGroups 
)
extern

Definition at line 3005 of file pathnode.c.

3010{
3012
3013 pathnode->path.pathtype = T_Unique;
3014 pathnode->path.parent = rel;
3015 /* Unique doesn't project, so use source path's pathtarget */
3016 pathnode->path.pathtarget = subpath->pathtarget;
3017 pathnode->path.param_info = subpath->param_info;
3018 pathnode->path.parallel_aware = false;
3019 pathnode->path.parallel_safe = rel->consider_parallel &&
3020 subpath->parallel_safe;
3021 pathnode->path.parallel_workers = subpath->parallel_workers;
3022 /* Unique doesn't change the input ordering */
3023 pathnode->path.pathkeys = subpath->pathkeys;
3024
3025 pathnode->subpath = subpath;
3026 pathnode->numkeys = numCols;
3027
3028 /*
3029 * Charge one cpu_operator_cost per comparison per input tuple. We assume
3030 * all columns get compared at most of the tuples. (XXX probably this is
3031 * an overestimate.)
3032 */
3033 pathnode->path.disabled_nodes = subpath->disabled_nodes;
3034 pathnode->path.startup_cost = subpath->startup_cost;
3035 pathnode->path.total_cost = subpath->total_cost +
3036 cpu_operator_cost * subpath->rows * numCols;
3037 pathnode->path.rows = numGroups;
3038
3039 /*
3040 * Mark the path as disabled if enable_groupagg is off. While this isn't
3041 * a grouping Agg node, it is the sort-based way of removing duplicates
3042 * and so is the natural counterpart to the AGG_HASHED path that
3043 * enable_hashagg controls; it seems close enough to justify letting that
3044 * switch control it.
3045 */
3046 if (!enable_groupagg)
3047 pathnode->path.disabled_nodes++;
3048
3049 return pathnode;
3050}

References RelOptInfo::consider_parallel, cpu_operator_cost, enable_groupagg, fb(), makeNode, and subpath().

Referenced by create_final_distinct_paths(), create_final_unique_paths(), create_partial_distinct_paths(), create_partial_unique_paths(), and generate_union_paths().

◆ create_valuesscan_path()

Path * create_valuesscan_path ( PlannerInfo *  root,
RelOptInfo *  rel,
Relids  required_outer 
)
extern

Definition at line 1991 of file pathnode.c.

1993{
1995
1996 pathnode->pathtype = T_ValuesScan;
1997 pathnode->parent = rel;
1998 pathnode->pathtarget = rel->reltarget;
1999 pathnode->param_info = get_baserel_parampathinfo(root, rel,
2001 pathnode->parallel_aware = false;
2002 pathnode->parallel_safe = rel->consider_parallel;
2003 pathnode->parallel_workers = 0;
2004 pathnode->pathkeys = NIL; /* result is always unordered */
2005
2006 cost_valuesscan(pathnode, root, rel, pathnode->param_info);
2007
2008 return pathnode;
2009}
void cost_valuesscan(Path *path, PlannerInfo *root, RelOptInfo *baserel, ParamPathInfo *param_info)
Definition costsize.c:1691

References RelOptInfo::consider_parallel, cost_valuesscan(), fb(), get_baserel_parampathinfo(), makeNode, NIL, RelOptInfo::reltarget, and root.

Referenced by set_values_pathlist().

◆ create_windowagg_path()

WindowAggPath * create_windowagg_path ( PlannerInfo *  root,
RelOptInfo *  rel,
Path *  subpath,
PathTarget *  target,
List *  windowFuncs,
List *  runCondition,
WindowClause *  winclause,
List *  qual,
bool  topwindow 
)
extern

Definition at line 3403 of file pathnode.c.

3412{
3414
3415 /* qual can only be set for the topwindow */
3416 Assert(qual == NIL || topwindow);
3417
3418 pathnode->path.pathtype = T_WindowAgg;
3419 pathnode->path.parent = rel;
3420 pathnode->path.pathtarget = target;
3421 /* For now, assume we are above any joins, so no parameterization */
3422 pathnode->path.param_info = NULL;
3423 pathnode->path.parallel_aware = false;
3424 pathnode->path.parallel_safe = rel->consider_parallel &&
3425 subpath->parallel_safe;
3426 pathnode->path.parallel_workers = subpath->parallel_workers;
3427 /* WindowAgg preserves the input sort order */
3428 pathnode->path.pathkeys = subpath->pathkeys;
3429
3430 pathnode->subpath = subpath;
3431 pathnode->winclause = winclause;
3432 pathnode->qual = qual;
3433 pathnode->runCondition = runCondition;
3434 pathnode->topwindow = topwindow;
3435
3436 /*
3437 * For costing purposes, assume that there are no redundant partitioning
3438 * or ordering columns; it's not worth the trouble to deal with that
3439 * corner case here. So we just pass the unmodified list lengths to
3440 * cost_windowagg.
3441 */
3443 windowFuncs,
3444 winclause,
3445 subpath->disabled_nodes,
3446 subpath->startup_cost,
3447 subpath->total_cost,
3448 subpath->rows);
3449
3450 /* add tlist eval cost for each output row */
3451 pathnode->path.startup_cost += target->cost.startup;
3452 pathnode->path.total_cost += target->cost.startup +
3453 target->cost.per_tuple * pathnode->path.rows;
3454
3455 return pathnode;
3456}
void cost_windowagg(Path *path, PlannerInfo *root, List *windowFuncs, WindowClause *winclause, int input_disabled_nodes, Cost input_startup_cost, Cost input_total_cost, double input_tuples)
Definition costsize.c:3227

References Assert, RelOptInfo::consider_parallel, PathTarget::cost, cost_windowagg(), fb(), makeNode, NIL, QualCost::per_tuple, root, QualCost::startup, and subpath().

Referenced by create_one_window_path().

◆ create_worktablescan_path()

Path * create_worktablescan_path ( PlannerInfo *  root,
RelOptInfo *  rel,
Relids  required_outer 
)
extern

Definition at line 2095 of file pathnode.c.

2097{
2099
2100 pathnode->pathtype = T_WorkTableScan;
2101 pathnode->parent = rel;
2102 pathnode->pathtarget = rel->reltarget;
2103 pathnode->param_info = get_baserel_parampathinfo(root, rel,
2105 pathnode->parallel_aware = false;
2106 pathnode->parallel_safe = rel->consider_parallel;
2107 pathnode->parallel_workers = 0;
2108 pathnode->pathkeys = NIL; /* result is always unordered */
2109
2110 /* Cost is the same as for a regular CTE scan */
2111 cost_ctescan(pathnode, root, rel, pathnode->param_info);
2112
2113 return pathnode;
2114}

References RelOptInfo::consider_parallel, cost_ctescan(), fb(), get_baserel_parampathinfo(), makeNode, NIL, RelOptInfo::reltarget, and root.

Referenced by set_worktable_pathlist().

◆ expand_planner_arrays()

void expand_planner_arrays ( PlannerInfo *  root,
int  add_size 
)
extern

Definition at line 183 of file relnode.c.

184{
185 int new_size;
186
187 Assert(add_size > 0);
188
189 new_size = root->simple_rel_array_size + add_size;
190
191 root->simple_rel_array =
192 repalloc0_array(root->simple_rel_array, RelOptInfo *, root->simple_rel_array_size, new_size);
193
194 root->simple_rte_array =
195 repalloc0_array(root->simple_rte_array, RangeTblEntry *, root->simple_rel_array_size, new_size);
196
197 if (root->append_rel_array)
198 root->append_rel_array =
199 repalloc0_array(root->append_rel_array, AppendRelInfo *, root->simple_rel_array_size, new_size);
200 else
201 root->append_rel_array =
203
204 root->simple_rel_array_size = new_size;
205}
Size add_size(Size s1, Size s2)
Definition mcxt.c:1733
#define repalloc0_array(pointer, type, oldcount, count)
Definition palloc.h:122

References add_size(), Assert, fb(), palloc0_array, repalloc0_array, and root.

Referenced by expand_inherited_rtentry(), and expand_partitioned_rtentry().

◆ fetch_upper_rel()

RelOptInfo * fetch_upper_rel ( PlannerInfo *  root,
UpperRelationKind  kind,
Relids  relids 
)
extern

Definition at line 1617 of file relnode.c.

1618{
1620 ListCell *lc;
1621
1622 /*
1623 * For the moment, our indexing data structure is just a List for each
1624 * relation kind. If we ever get so many of one kind that this stops
1625 * working well, we can improve it. No code outside this function should
1626 * assume anything about how to find a particular upperrel.
1627 */
1628
1629 /* If we already made this upperrel for the query, return it */
1630 foreach(lc, root->upper_rels[kind])
1631 {
1633
1634 if (bms_equal(upperrel->relids, relids))
1635 return upperrel;
1636 }
1637
1639 upperrel->reloptkind = RELOPT_UPPER_REL;
1640 upperrel->relids = bms_copy(relids);
1641 upperrel->pgs_mask = root->glob->default_pgs_mask;
1642
1643 /* cheap startup cost is interesting iff not all tuples to be retrieved */
1644 upperrel->consider_startup = (root->tuple_fraction > 0);
1645 upperrel->consider_param_startup = false;
1646 upperrel->consider_parallel = false; /* might get changed later */
1647 upperrel->reltarget = create_empty_pathtarget();
1648 upperrel->pathlist = NIL;
1649 upperrel->cheapest_startup_path = NULL;
1650 upperrel->cheapest_total_path = NULL;
1651 upperrel->cheapest_parameterized_paths = NIL;
1652
1653 root->upper_rels[kind] = lappend(root->upper_rels[kind], upperrel);
1654
1655 return upperrel;
1656}
@ RELOPT_UPPER_REL
Definition pathnodes.h:981

References bms_copy(), bms_equal(), create_empty_pathtarget(), fb(), lappend(), lfirst, makeNode, NIL, RELOPT_UPPER_REL, and root.

Referenced by add_rtes_to_flat_rtable(), build_setop_child_paths(), create_distinct_paths(), create_ordered_paths(), create_partial_distinct_paths(), create_partial_grouping_paths(), create_window_paths(), generate_nonunion_paths(), generate_recursion_path(), generate_union_paths(), grouping_planner(), make_grouping_rel(), make_subplan(), preprocess_minmax_aggregates(), set_subquery_pathlist(), set_subquery_size_estimates(), SS_process_ctes(), standard_planner(), and subquery_planner().

◆ find_base_rel()

◆ find_base_rel_ignore_join()

RelOptInfo * find_base_rel_ignore_join ( PlannerInfo *  root,
int  relid 
)
extern

Definition at line 584 of file relnode.c.

585{
586 /* use an unsigned comparison to prevent negative array element access */
587 if ((uint32) relid < (uint32) root->simple_rel_array_size)
588 {
589 RelOptInfo *rel;
591
592 rel = root->simple_rel_array[relid];
593 if (rel)
594 return rel;
595
596 /*
597 * We could just return NULL here, but for debugging purposes it seems
598 * best to actually verify that the relid is an outer join and not
599 * something weird.
600 */
601 rte = root->simple_rte_array[relid];
602 if (rte && rte->rtekind == RTE_JOIN && rte->jointype != JOIN_INNER)
603 return NULL;
604 }
605
606 elog(ERROR, "no relation entry for relid %d", relid);
607
608 return NULL; /* keep compiler quiet */
609}

References elog, ERROR, fb(), JOIN_INNER, root, and RTE_JOIN.

Referenced by add_join_clause_to_rels(), create_lateral_join_info(), eager_aggregation_possible_for_relation(), find_appinfos_by_relids(), and remove_join_clause_from_rels().

◆ find_base_rel_noerr()

RelOptInfo * find_base_rel_noerr ( PlannerInfo *  root,
int  relid 
)
extern

Definition at line 566 of file relnode.c.

567{
568 /* use an unsigned comparison to prevent negative array element access */
569 if ((uint32) relid < (uint32) root->simple_rel_array_size)
570 return root->simple_rel_array[relid];
571 return NULL;
572}

References fb(), and root.

Referenced by all_rows_selectable().

◆ find_childrel_parents()

Relids find_childrel_parents ( PlannerInfo *  root,
RelOptInfo *  rel 
)
extern

Definition at line 1668 of file relnode.c.

1669{
1670 Relids result = NULL;
1671
1673 Assert(rel->relid > 0 && rel->relid < root->simple_rel_array_size);
1674
1675 do
1676 {
1677 AppendRelInfo *appinfo = root->append_rel_array[rel->relid];
1679
1681
1682 /* traverse up to the parent rel, loop if it's also a child rel */
1683 rel = find_base_rel(root, prelid);
1684 } while (rel->reloptkind == RELOPT_OTHER_MEMBER_REL);
1685
1687
1688 return result;
1689}
Bitmapset * bms_add_member(Bitmapset *a, int x)
Definition bitmapset.c:934
unsigned int Index
Definition c.h:757
RelOptInfo * find_base_rel(PlannerInfo *root, int relid)
Definition relnode.c:544
Index parent_relid
Definition pathnodes.h:3301

References Assert, bms_add_member(), fb(), find_base_rel(), AppendRelInfo::parent_relid, RelOptInfo::relid, RELOPT_BASEREL, RELOPT_OTHER_MEMBER_REL, RelOptInfo::reloptkind, result, and root.

Referenced by check_index_predicates(), and generate_implied_equalities_for_column().

◆ find_join_rel()

RelOptInfo * find_join_rel ( PlannerInfo *  root,
Relids  relids 
)
extern

Definition at line 657 of file relnode.c.

658{
659 /*
660 * Switch to using hash lookup when list grows "too long". The threshold
661 * is arbitrary and is known only here.
662 */
663 if (!root->join_rel_hash && list_length(root->join_rel_list) > 32)
665
666 /*
667 * Use either hashtable lookup or linear search, as appropriate.
668 *
669 * Note: the seemingly redundant hashkey variable is used to avoid taking
670 * the address of relids; unless the compiler is exceedingly smart, doing
671 * so would force relids out of a register and thus probably slow down the
672 * list-search case.
673 */
674 if (root->join_rel_hash)
675 {
676 Relids hashkey = relids;
678
679 hentry = (JoinHashEntry *) hash_search(root->join_rel_hash,
680 &hashkey,
681 HASH_FIND,
682 NULL);
683 if (hentry)
684 return hentry->join_rel;
685 }
686 else
687 {
688 ListCell *l;
689
690 foreach(l, root->join_rel_list)
691 {
692 RelOptInfo *rel = (RelOptInfo *) lfirst(l);
693
694 if (bms_equal(rel->relids, relids))
695 return rel;
696 }
697 }
698
699 return NULL;
700}
void * hash_search(HTAB *hashp, const void *keyPtr, HASHACTION action, bool *foundPtr)
Definition dynahash.c:889
@ HASH_FIND
Definition hsearch.h:108
static void build_join_rel_hash(PlannerInfo *root)
Definition relnode.c:616
RelOptInfo * join_rel
Definition relnode.c:47

References bms_equal(), build_join_rel_hash(), fb(), HASH_FIND, hash_search(), JoinHashEntry::join_rel, lfirst, list_length(), RelOptInfo::relids, and root.

Referenced by build_child_join_rel(), build_join_rel(), examine_variable(), find_join_input_rel(), get_matching_part_pairs(), and postgresPlanDirectModify().

◆ find_param_path_info()

ParamPathInfo * find_param_path_info ( RelOptInfo *  rel,
Relids  required_outer 
)
extern

Definition at line 2048 of file relnode.c.

2049{
2050 ListCell *lc;
2051
2052 foreach(lc, rel->ppilist)
2053 {
2055
2056 if (bms_equal(ppi->ppi_req_outer, required_outer))
2057 return ppi;
2058 }
2059
2060 return NULL;
2061}

References bms_equal(), fb(), lfirst, and RelOptInfo::ppilist.

Referenced by get_appendrel_parampathinfo(), get_baserel_parampathinfo(), get_joinrel_parampathinfo(), and reparameterize_path_by_child().

◆ get_appendrel_parampathinfo()

ParamPathInfo * get_appendrel_parampathinfo ( RelOptInfo *  appendrel,
Relids  required_outer 
)
extern

Definition at line 2015 of file relnode.c.

2016{
2018
2019 /* If rel has LATERAL refs, every path for it should account for them */
2020 Assert(bms_is_subset(appendrel->lateral_relids, required_outer));
2021
2022 /* Unparameterized paths have no ParamPathInfo */
2024 return NULL;
2025
2027
2028 /* If we already have a PPI for this parameterization, just return it */
2030 return ppi;
2031
2032 /* Else build the ParamPathInfo */
2034 ppi->ppi_req_outer = required_outer;
2035 ppi->ppi_rows = 0;
2036 ppi->ppi_clauses = NIL;
2037 ppi->ppi_serials = NULL;
2038 appendrel->ppilist = lappend(appendrel->ppilist, ppi);
2039
2040 return ppi;
2041}
bool bms_is_subset(const Bitmapset *a, const Bitmapset *b)
Definition bitmapset.c:547
ParamPathInfo * find_param_path_info(RelOptInfo *rel, Relids required_outer)
Definition relnode.c:2048

References Assert, bms_is_empty, bms_is_subset(), bms_overlap(), fb(), find_param_path_info(), lappend(), makeNode, and NIL.

Referenced by create_append_path().

◆ get_baserel_parampathinfo()

ParamPathInfo * get_baserel_parampathinfo ( PlannerInfo *  root,
RelOptInfo *  baserel,
Relids  required_outer 
)
extern

Definition at line 1704 of file relnode.c.

1706{
1709 List *pclauses;
1710 List *eqclauses;
1712 double rows;
1713 ListCell *lc;
1714
1715 /* If rel has LATERAL refs, every path for it should account for them */
1716 Assert(bms_is_subset(baserel->lateral_relids, required_outer));
1717
1718 /* Unparameterized paths have no ParamPathInfo */
1720 return NULL;
1721
1723
1724 /* If we already have a PPI for this parameterization, just return it */
1726 return ppi;
1727
1728 /*
1729 * Identify all joinclauses that are movable to this base rel given this
1730 * parameterization.
1731 */
1733 pclauses = NIL;
1734 foreach(lc, baserel->joininfo)
1735 {
1736 RestrictInfo *rinfo = (RestrictInfo *) lfirst(lc);
1737
1739 baserel->relids,
1740 joinrelids))
1741 pclauses = lappend(pclauses, rinfo);
1742 }
1743
1744 /*
1745 * Add in joinclauses generated by EquivalenceClasses, too. (These
1746 * necessarily satisfy join_clause_is_movable_into; but in assert-enabled
1747 * builds, let's verify that.)
1748 */
1750 joinrelids,
1752 baserel,
1753 NULL);
1754#ifdef USE_ASSERT_CHECKING
1755 foreach(lc, eqclauses)
1756 {
1757 RestrictInfo *rinfo = (RestrictInfo *) lfirst(lc);
1758
1760 baserel->relids,
1761 joinrelids));
1762 }
1763#endif
1765
1766 /* Compute set of serial numbers of the enforced clauses */
1767 pserials = NULL;
1768 foreach(lc, pclauses)
1769 {
1770 RestrictInfo *rinfo = (RestrictInfo *) lfirst(lc);
1771
1773 }
1774
1775 /* Estimate the number of rows returned by the parameterized scan */
1777
1778 /* And now we can build the ParamPathInfo */
1780 ppi->ppi_req_outer = required_outer;
1781 ppi->ppi_rows = rows;
1782 ppi->ppi_clauses = pclauses;
1783 ppi->ppi_serials = pserials;
1784 baserel->ppilist = lappend(baserel->ppilist, ppi);
1785
1786 return ppi;
1787}
double get_parameterized_baserel_size(PlannerInfo *root, RelOptInfo *rel, List *param_clauses)
Definition costsize.c:5546
List * generate_join_implied_equalities(PlannerInfo *root, Relids join_relids, Relids outer_relids, RelOptInfo *inner_rel, SpecialJoinInfo *sjinfo)
bool join_clause_is_movable_into(RestrictInfo *rinfo, Relids currentrelids, Relids current_and_outer)

References Assert, bms_add_member(), bms_is_empty, bms_is_subset(), bms_overlap(), bms_union(), fb(), find_param_path_info(), generate_join_implied_equalities(), get_parameterized_baserel_size(), join_clause_is_movable_into(), lappend(), lfirst, list_concat(), makeNode, NIL, RestrictInfo::rinfo_serial, and root.

Referenced by create_append_path(), create_bitmap_and_path(), create_bitmap_heap_path(), create_bitmap_or_path(), create_ctescan_path(), create_foreignscan_path(), create_functionscan_path(), create_gather_merge_path(), create_gather_path(), create_index_path(), create_namedtuplestorescan_path(), create_resultscan_path(), create_samplescan_path(), create_seqscan_path(), create_subqueryscan_path(), create_tablefuncscan_path(), create_tidrangescan_path(), create_tidscan_path(), create_valuesscan_path(), create_worktablescan_path(), postgresGetForeignPaths(), and reparameterize_path().

◆ get_joinrel_parampathinfo()

ParamPathInfo * get_joinrel_parampathinfo ( PlannerInfo *  root,
RelOptInfo *  joinrel,
Path *  outer_path,
Path *  inner_path,
SpecialJoinInfo *  sjinfo,
Relids  required_outer,
List **  restrict_clauses 
)
extern

Definition at line 1818 of file relnode.c.

1824{
1829 List *pclauses;
1830 List *eclauses;
1832 double rows;
1833 ListCell *lc;
1834
1835 /* If rel has LATERAL refs, every path for it should account for them */
1837
1838 /* Unparameterized paths have no ParamPathInfo or extra join clauses */
1840 return NULL;
1841
1843
1844 /*
1845 * Identify all joinclauses that are movable to this join rel given this
1846 * parameterization. These are the clauses that are movable into this
1847 * join, but not movable into either input path. Treat an unparameterized
1848 * input path as not accepting parameterized clauses (because it won't,
1849 * per the shortcut exit above), even though the joinclause movement rules
1850 * might allow the same clauses to be moved into a parameterized path for
1851 * that rel.
1852 */
1854 if (outer_path->param_info)
1855 outer_and_req = bms_union(outer_path->parent->relids,
1857 else
1858 outer_and_req = NULL; /* outer path does not accept parameters */
1859 if (inner_path->param_info)
1860 inner_and_req = bms_union(inner_path->parent->relids,
1862 else
1863 inner_and_req = NULL; /* inner path does not accept parameters */
1864
1865 pclauses = NIL;
1866 foreach(lc, joinrel->joininfo)
1867 {
1868 RestrictInfo *rinfo = (RestrictInfo *) lfirst(lc);
1869
1871 joinrel->relids,
1872 join_and_req) &&
1874 outer_path->parent->relids,
1875 outer_and_req) &&
1877 inner_path->parent->relids,
1879 pclauses = lappend(pclauses, rinfo);
1880 }
1881
1882 /* Consider joinclauses generated by EquivalenceClasses, too */
1886 joinrel,
1887 NULL);
1888 /* We only want ones that aren't movable to lower levels */
1889 dropped_ecs = NIL;
1890 foreach(lc, eclauses)
1891 {
1892 RestrictInfo *rinfo = (RestrictInfo *) lfirst(lc);
1893
1895 joinrel->relids,
1896 join_and_req));
1898 outer_path->parent->relids,
1900 continue; /* drop if movable into LHS */
1902 inner_path->parent->relids,
1904 {
1905 /* drop if movable into RHS, but remember EC for use below */
1906 Assert(rinfo->left_ec == rinfo->right_ec);
1907 dropped_ecs = lappend(dropped_ecs, rinfo->left_ec);
1908 continue;
1909 }
1910 pclauses = lappend(pclauses, rinfo);
1911 }
1912
1913 /*
1914 * EquivalenceClasses are harder to deal with than we could wish, because
1915 * of the fact that a given EC can generate different clauses depending on
1916 * context. Suppose we have an EC {X.X, Y.Y, Z.Z} where X and Y are the
1917 * LHS and RHS of the current join and Z is in required_outer, and further
1918 * suppose that the inner_path is parameterized by both X and Z. The code
1919 * above will have produced either Z.Z = X.X or Z.Z = Y.Y from that EC,
1920 * and in the latter case will have discarded it as being movable into the
1921 * RHS. However, the EC machinery might have produced either Y.Y = X.X or
1922 * Y.Y = Z.Z as the EC enforcement clause within the inner_path; it will
1923 * not have produced both, and we can't readily tell from here which one
1924 * it did pick. If we add no clause to this join, we'll end up with
1925 * insufficient enforcement of the EC; either Z.Z or X.X will fail to be
1926 * constrained to be equal to the other members of the EC. (When we come
1927 * to join Z to this X/Y path, we will certainly drop whichever EC clause
1928 * is generated at that join, so this omission won't get fixed later.)
1929 *
1930 * To handle this, for each EC we discarded such a clause from, try to
1931 * generate a clause connecting the required_outer rels to the join's LHS
1932 * ("Z.Z = X.X" in the terms of the above example). If successful, and if
1933 * the clause can't be moved to the LHS, add it to the current join's
1934 * restriction clauses. (If an EC cannot generate such a clause then it
1935 * has nothing that needs to be enforced here, while if the clause can be
1936 * moved into the LHS then it should have been enforced within that path.)
1937 *
1938 * Note that we don't need similar processing for ECs whose clause was
1939 * considered to be movable into the LHS, because the LHS can't refer to
1940 * the RHS so there is no comparable ambiguity about what it might
1941 * actually be enforcing internally.
1942 */
1943 if (dropped_ecs)
1944 {
1946
1947 real_outer_and_req = bms_union(outer_path->parent->relids,
1949 eclauses =
1954 outer_path->parent);
1955 foreach(lc, eclauses)
1956 {
1957 RestrictInfo *rinfo = (RestrictInfo *) lfirst(lc);
1958
1960 outer_path->parent->relids,
1962 if (!join_clause_is_movable_into(rinfo,
1963 outer_path->parent->relids,
1965 pclauses = lappend(pclauses, rinfo);
1966 }
1967 }
1968
1969 /*
1970 * Now, attach the identified moved-down clauses to the caller's
1971 * restrict_clauses list. By using list_concat in this order, we leave
1972 * the original list structure of restrict_clauses undamaged.
1973 */
1975
1976 /* If we already have a PPI for this parameterization, just return it */
1977 if ((ppi = find_param_path_info(joinrel, required_outer)))
1978 return ppi;
1979
1980 /* Estimate the number of rows returned by the parameterized join */
1981 rows = get_parameterized_joinrel_size(root, joinrel,
1982 outer_path,
1983 inner_path,
1984 sjinfo,
1986
1987 /*
1988 * And now we can build the ParamPathInfo. No point in saving the
1989 * input-pair-dependent clause list, though.
1990 *
1991 * Note: in GEQO mode, we'll be called in a temporary memory context, but
1992 * the joinrel structure is there too, so no problem.
1993 */
1995 ppi->ppi_req_outer = required_outer;
1996 ppi->ppi_rows = rows;
1997 ppi->ppi_clauses = NIL;
1998 ppi->ppi_serials = NULL;
1999 joinrel->ppilist = lappend(joinrel->ppilist, ppi);
2000
2001 return ppi;
2002}
double get_parameterized_joinrel_size(PlannerInfo *root, RelOptInfo *rel, Path *outer_path, Path *inner_path, SpecialJoinInfo *sjinfo, List *restrict_clauses)
Definition costsize.c:5627
List * generate_join_implied_equalities_for_ecs(PlannerInfo *root, List *eclasses, Relids join_relids, Relids outer_relids, RelOptInfo *inner_rel)

References Assert, bms_is_empty, bms_is_subset(), bms_overlap(), bms_union(), fb(), find_param_path_info(), generate_join_implied_equalities(), generate_join_implied_equalities_for_ecs(), get_parameterized_joinrel_size(), join_clause_is_movable_into(), RelOptInfo::joininfo, lappend(), RelOptInfo::lateral_relids, lfirst, list_concat(), makeNode, NIL, PATH_REQ_OUTER, RelOptInfo::ppilist, RelOptInfo::relids, and root.

Referenced by create_hashjoin_path(), create_mergejoin_path(), and create_nestloop_path().

◆ get_param_path_clause_serials()

Bitmapset * get_param_path_clause_serials ( Path *  path)
extern

Definition at line 2069 of file relnode.c.

2070{
2071 if (path->param_info == NULL)
2072 return NULL; /* not parameterized */
2073
2074 /*
2075 * We don't currently support parameterized MergeAppend paths, as
2076 * explained in the comments for generate_orderedappend_paths.
2077 */
2078 Assert(!IsA(path, MergeAppendPath));
2079
2080 if (IsA(path, NestPath) ||
2081 IsA(path, MergePath) ||
2082 IsA(path, HashPath))
2083 {
2084 /*
2085 * For a join path, combine clauses enforced within either input path
2086 * with those enforced as joinrestrictinfo in this path. Note that
2087 * joinrestrictinfo may include some non-pushed-down clauses, but for
2088 * current purposes it's okay if we include those in the result. (To
2089 * be more careful, we could check for clause_relids overlapping the
2090 * path parameterization, but it's not worth the cycles for now.)
2091 */
2092 JoinPath *jpath = (JoinPath *) path;
2094 ListCell *lc;
2095
2096 pserials = NULL;
2101 foreach(lc, jpath->joinrestrictinfo)
2102 {
2103 RestrictInfo *rinfo = (RestrictInfo *) lfirst(lc);
2104
2106 }
2107 return pserials;
2108 }
2109 else if (IsA(path, AppendPath))
2110 {
2111 /*
2112 * For an appendrel, take the intersection of the sets of clauses
2113 * enforced in each input path.
2114 */
2115 AppendPath *apath = (AppendPath *) path;
2117 ListCell *lc;
2118
2119 pserials = NULL;
2120 foreach(lc, apath->subpaths)
2121 {
2122 Path *subpath = (Path *) lfirst(lc);
2124
2126 if (lc == list_head(apath->subpaths))
2128 else
2130 }
2131 return pserials;
2132 }
2133 else
2134 {
2135 /*
2136 * Otherwise, it's a baserel path and we can use the
2137 * previously-computed set of serial numbers.
2138 */
2139 return path->param_info->ppi_serials;
2140 }
2141}
Bitmapset * bms_int_members(Bitmapset *a, const Bitmapset *b)
Definition bitmapset.c:1228
static ListCell * list_head(const List *l)
Definition pg_list.h:128
Path * outerjoinpath
Definition pathnodes.h:2404
Path * innerjoinpath
Definition pathnodes.h:2405
List * joinrestrictinfo
Definition pathnodes.h:2407

References Assert, bms_add_member(), bms_add_members(), bms_copy(), bms_int_members(), fb(), get_param_path_clause_serials(), JoinPath::innerjoinpath, IsA, JoinPath::joinrestrictinfo, lfirst, list_head(), JoinPath::outerjoinpath, RestrictInfo::rinfo_serial, and subpath().

Referenced by create_nestloop_path(), and get_param_path_clause_serials().

◆ min_join_parameterization()

Relids min_join_parameterization ( PlannerInfo *  root,
Relids  joinrelids,
RelOptInfo *  outer_rel,
RelOptInfo *  inner_rel 
)
extern

Definition at line 1181 of file relnode.c.

1185{
1186 Relids result;
1187
1188 /*
1189 * Basically we just need the union of the inputs' lateral_relids, less
1190 * whatever is already in the join.
1191 *
1192 * It's not immediately obvious that this is a valid way to compute the
1193 * result, because it might seem that we're ignoring possible lateral refs
1194 * of PlaceHolderVars that are due to be computed at the join but not in
1195 * either input. However, because create_lateral_join_info() already
1196 * charged all such PHV refs to each member baserel of the join, they'll
1197 * be accounted for already in the inputs' lateral_relids. Likewise, we
1198 * do not need to worry about doing transitive closure here, because that
1199 * was already accounted for in the original baserel lateral_relids.
1200 */
1201 result = bms_union(outer_rel->lateral_relids, inner_rel->lateral_relids);
1203 return result;
1204}

References bms_del_members(), bms_union(), fb(), and result.

Referenced by build_join_rel(), and join_is_legal().

◆ path_is_reparameterizable_by_child()

bool path_is_reparameterizable_by_child ( Path *  path,
RelOptInfo *  child_rel 
)
extern

Definition at line 4403 of file pathnode.c.

4404{
4405#define REJECT_IF_PATH_NOT_REPARAMETERIZABLE(path) \
4406do { \
4407 if (!path_is_reparameterizable_by_child(path, child_rel)) \
4408 return false; \
4409} while(0)
4410
4411#define REJECT_IF_PATH_LIST_NOT_REPARAMETERIZABLE(pathlist) \
4412do { \
4413 if (!pathlist_is_reparameterizable_by_child(pathlist, child_rel)) \
4414 return false; \
4415} while(0)
4416
4417 /*
4418 * If the path is not parameterized by the parent of the given relation,
4419 * it doesn't need reparameterization.
4420 */
4421 if (!path->param_info ||
4422 !bms_overlap(PATH_REQ_OUTER(path), child_rel->top_parent_relids))
4423 return true;
4424
4425 /*
4426 * Check that the path type is one that reparameterize_path_by_child() can
4427 * handle, and recursively check subpaths.
4428 */
4429 switch (nodeTag(path))
4430 {
4431 case T_Path:
4432 case T_IndexPath:
4433 break;
4434
4435 case T_BitmapHeapPath:
4436 {
4438
4440 }
4441 break;
4442
4443 case T_BitmapAndPath:
4444 {
4446
4448 }
4449 break;
4450
4451 case T_BitmapOrPath:
4452 {
4453 BitmapOrPath *bopath = (BitmapOrPath *) path;
4454
4456 }
4457 break;
4458
4459 case T_ForeignPath:
4460 {
4461 ForeignPath *fpath = (ForeignPath *) path;
4462
4463 if (fpath->fdw_outerpath)
4465 }
4466 break;
4467
4468 case T_CustomPath:
4469 {
4470 CustomPath *cpath = (CustomPath *) path;
4471
4473 }
4474 break;
4475
4476 case T_NestPath:
4477 case T_MergePath:
4478 case T_HashPath:
4479 {
4480 JoinPath *jpath = (JoinPath *) path;
4481
4484 }
4485 break;
4486
4487 case T_AppendPath:
4488 {
4489 AppendPath *apath = (AppendPath *) path;
4490
4492 }
4493 break;
4494
4495 case T_MaterialPath:
4496 {
4497 MaterialPath *mpath = (MaterialPath *) path;
4498
4500 }
4501 break;
4502
4503 case T_MemoizePath:
4504 {
4505 MemoizePath *mpath = (MemoizePath *) path;
4506
4508 }
4509 break;
4510
4511 case T_GatherPath:
4512 {
4513 GatherPath *gpath = (GatherPath *) path;
4514
4516 }
4517 break;
4518
4519 default:
4520 /* We don't know how to reparameterize this path. */
4521 return false;
4522 }
4523
4524 return true;
4525}
#define nodeTag(nodeptr)
Definition nodes.h:137
#define REJECT_IF_PATH_LIST_NOT_REPARAMETERIZABLE(pathlist)
#define REJECT_IF_PATH_NOT_REPARAMETERIZABLE(path)

References bms_overlap(), fb(), JoinPath::innerjoinpath, nodeTag, JoinPath::outerjoinpath, PATH_REQ_OUTER, REJECT_IF_PATH_LIST_NOT_REPARAMETERIZABLE, and REJECT_IF_PATH_NOT_REPARAMETERIZABLE.

Referenced by pathlist_is_reparameterizable_by_child(), try_nestloop_path(), and try_partial_nestloop_path().

◆ reparameterize_path()

Path * reparameterize_path ( PlannerInfo *  root,
Path *  path,
Relids  required_outer,
double  loop_count 
)
extern

Definition at line 3937 of file pathnode.c.

3940{
3941 RelOptInfo *rel = path->parent;
3942
3943 /* Can only increase, not decrease, path's parameterization */
3945 return NULL;
3946 switch (path->pathtype)
3947 {
3948 case T_SeqScan:
3949 return create_seqscan_path(root, rel, required_outer, 0);
3950 case T_SampleScan:
3952 case T_IndexScan:
3953 case T_IndexOnlyScan:
3954 {
3955 IndexPath *ipath = (IndexPath *) path;
3957
3958 /*
3959 * We can't use create_index_path directly, and would not want
3960 * to because it would re-compute the indexqual conditions
3961 * which is wasted effort. Instead we hack things a bit:
3962 * flat-copy the path node, revise its param_info, and redo
3963 * the cost estimate.
3964 */
3965 memcpy(newpath, ipath, sizeof(IndexPath));
3966 newpath->path.param_info =
3969 return (Path *) newpath;
3970 }
3971 case T_BitmapHeapScan:
3972 {
3974
3976 rel,
3977 bpath->bitmapqual,
3979 loop_count, 0);
3980 }
3981 case T_SubqueryScan:
3982 {
3983 SubqueryScanPath *spath = (SubqueryScanPath *) path;
3984 Path *subpath = spath->subpath;
3985 bool trivial_pathtarget;
3986
3987 /*
3988 * If existing node has zero extra cost, we must have decided
3989 * its target is trivial. (The converse is not true, because
3990 * it might have a trivial target but quals to enforce; but in
3991 * that case the new node will too, so it doesn't matter
3992 * whether we get the right answer here.)
3993 */
3995 (subpath->total_cost == spath->path.total_cost);
3996
3998 rel,
3999 subpath,
4001 spath->path.pathkeys,
4003 }
4004 case T_Result:
4005 /* Supported only for RTE_RESULT scan paths */
4006 if (IsA(path, Path))
4008 break;
4009 case T_Append:
4010 {
4011 AppendPath *apath = (AppendPath *) path;
4013 int i;
4014 ListCell *lc;
4015
4016 new_append.child_append_relid_sets = apath->child_append_relid_sets;
4017
4018 /* Reparameterize the children */
4019 i = 0;
4020 foreach(lc, apath->subpaths)
4021 {
4022 Path *spath = (Path *) lfirst(lc);
4023
4024 spath = reparameterize_path(root, spath,
4026 loop_count);
4027 if (spath == NULL)
4028 return NULL;
4029 /* We have to re-split the regular and partial paths */
4030 if (i < apath->first_partial_path)
4031 new_append.subpaths = lappend(new_append.subpaths, spath);
4032 else
4033 new_append.partial_subpaths = lappend(new_append.partial_subpaths, spath);
4034 i++;
4035 }
4036 return (Path *)
4038 apath->path.pathkeys, required_outer,
4039 apath->path.parallel_workers,
4040 apath->path.parallel_aware,
4041 -1);
4042 }
4043 case T_Material:
4044 {
4045 MaterialPath *mpath = (MaterialPath *) path;
4046 Path *spath = mpath->subpath;
4047 bool enabled;
4048
4049 spath = reparameterize_path(root, spath,
4051 loop_count);
4052 if (spath == NULL)
4053 return NULL;
4054 enabled =
4055 (mpath->path.disabled_nodes <= spath->disabled_nodes);
4056 return (Path *) create_material_path(rel, spath, enabled);
4057 }
4058 case T_Memoize:
4059 {
4060 MemoizePath *mpath = (MemoizePath *) path;
4061 Path *spath = mpath->subpath;
4062
4063 spath = reparameterize_path(root, spath,
4065 loop_count);
4066 if (spath == NULL)
4067 return NULL;
4068 return (Path *) create_memoize_path(root, rel,
4069 spath,
4070 mpath->param_exprs,
4071 mpath->hash_operators,
4072 mpath->singlerow,
4073 mpath->binary_mode,
4074 mpath->est_calls);
4075 }
4076 default:
4077 break;
4078 }
4079 return NULL;
4080}
int i
Definition isn.c:77
MemoizePath * create_memoize_path(PlannerInfo *root, RelOptInfo *rel, Path *subpath, List *param_exprs, List *hash_operators, bool singlerow, bool binary_mode, Cardinality est_calls)
Definition pathnode.c:1746
MaterialPath * create_material_path(RelOptInfo *rel, Path *subpath, bool enabled)
Definition pathnode.c:1712
Path * create_seqscan_path(PlannerInfo *root, RelOptInfo *rel, Relids required_outer, int parallel_workers)
Definition pathnode.c:1026
SubqueryScanPath * create_subqueryscan_path(PlannerInfo *root, RelOptInfo *rel, Path *subpath, bool trivial_pathtarget, List *pathkeys, Relids required_outer)
Definition pathnode.c:1909
BitmapHeapPath * create_bitmap_heap_path(PlannerInfo *root, RelOptInfo *rel, Path *bitmapqual, Relids required_outer, double loop_count, int parallel_degree)
Definition pathnode.c:1149
Path * create_samplescan_path(PlannerInfo *root, RelOptInfo *rel, Relids required_outer)
Definition pathnode.c:1051
Path * create_resultscan_path(PlannerInfo *root, RelOptInfo *rel, Relids required_outer)
Definition pathnode.c:2069
AppendPath * create_append_path(PlannerInfo *root, RelOptInfo *rel, AppendPathInput input, List *pathkeys, Relids required_outer, int parallel_workers, bool parallel_aware, double rows)
Definition pathnode.c:1352
Path * reparameterize_path(PlannerInfo *root, Path *path, Relids required_outer, double loop_count)
Definition pathnode.c:3937

References bms_is_subset(), cost_index(), create_append_path(), create_bitmap_heap_path(), create_material_path(), create_memoize_path(), create_resultscan_path(), create_samplescan_path(), create_seqscan_path(), create_subqueryscan_path(), Path::disabled_nodes, fb(), get_baserel_parampathinfo(), i, IsA, lappend(), lfirst, makeNode, memcpy(), SubqueryScanPath::path, PATH_REQ_OUTER, Path::pathkeys, Path::pathtype, reparameterize_path(), root, subpath(), SubqueryScanPath::subpath, and Path::total_cost.

Referenced by get_cheapest_parameterized_child_path(), and reparameterize_path().

◆ reparameterize_path_by_child()

Path * reparameterize_path_by_child ( PlannerInfo *  root,
Path *  path,
RelOptInfo *  child_rel 
)
extern

Definition at line 4107 of file pathnode.c.

4109{
4110 Path *new_path;
4114
4115#define ADJUST_CHILD_ATTRS(node) \
4116 ((node) = (void *) adjust_appendrel_attrs_multilevel(root, \
4117 (Node *) (node), \
4118 child_rel, \
4119 child_rel->top_parent))
4120
4121#define REPARAMETERIZE_CHILD_PATH(path) \
4122do { \
4123 (path) = reparameterize_path_by_child(root, (path), child_rel); \
4124 if ((path) == NULL) \
4125 return NULL; \
4126} while(0)
4127
4128#define REPARAMETERIZE_CHILD_PATH_LIST(pathlist) \
4129do { \
4130 if ((pathlist) != NIL) \
4131 { \
4132 (pathlist) = reparameterize_pathlist_by_child(root, (pathlist), \
4133 child_rel); \
4134 if ((pathlist) == NIL) \
4135 return NULL; \
4136 } \
4137} while(0)
4138
4139 /*
4140 * If the path is not parameterized by the parent of the given relation,
4141 * it doesn't need reparameterization.
4142 */
4143 if (!path->param_info ||
4144 !bms_overlap(PATH_REQ_OUTER(path), child_rel->top_parent_relids))
4145 return path;
4146
4147 /*
4148 * If possible, reparameterize the given path.
4149 *
4150 * This function is currently only applied to the inner side of a nestloop
4151 * join that is being partitioned by the partitionwise-join code. Hence,
4152 * we need only support path types that plausibly arise in that context.
4153 * (In particular, supporting sorted path types would be a waste of code
4154 * and cycles: even if we translated them here, they'd just lose in
4155 * subsequent cost comparisons.) If we do see an unsupported path type,
4156 * that just means we won't be able to generate a partitionwise-join plan
4157 * using that path type.
4158 */
4159 switch (nodeTag(path))
4160 {
4161 case T_Path:
4162 new_path = path;
4163 ADJUST_CHILD_ATTRS(new_path->parent->baserestrictinfo);
4164 if (path->pathtype == T_SampleScan)
4165 {
4166 Index scan_relid = path->parent->relid;
4168
4169 /* it should be a base rel with a tablesample clause... */
4170 Assert(scan_relid > 0);
4172 Assert(rte->rtekind == RTE_RELATION);
4173 Assert(rte->tablesample != NULL);
4174
4175 ADJUST_CHILD_ATTRS(rte->tablesample);
4176 }
4177 break;
4178
4179 case T_IndexPath:
4180 {
4181 IndexPath *ipath = (IndexPath *) path;
4182
4183 ADJUST_CHILD_ATTRS(ipath->indexinfo->indrestrictinfo);
4184 ADJUST_CHILD_ATTRS(ipath->indexclauses);
4185 new_path = (Path *) ipath;
4186 }
4187 break;
4188
4189 case T_BitmapHeapPath:
4190 {
4192
4193 ADJUST_CHILD_ATTRS(bhpath->path.parent->baserestrictinfo);
4194 REPARAMETERIZE_CHILD_PATH(bhpath->bitmapqual);
4195 new_path = (Path *) bhpath;
4196 }
4197 break;
4198
4199 case T_BitmapAndPath:
4200 {
4202
4204 new_path = (Path *) bapath;
4205 }
4206 break;
4207
4208 case T_BitmapOrPath:
4209 {
4210 BitmapOrPath *bopath = (BitmapOrPath *) path;
4211
4213 new_path = (Path *) bopath;
4214 }
4215 break;
4216
4217 case T_ForeignPath:
4218 {
4219 ForeignPath *fpath = (ForeignPath *) path;
4221
4222 ADJUST_CHILD_ATTRS(fpath->path.parent->baserestrictinfo);
4223 if (fpath->fdw_outerpath)
4224 REPARAMETERIZE_CHILD_PATH(fpath->fdw_outerpath);
4225 if (fpath->fdw_restrictinfo)
4226 ADJUST_CHILD_ATTRS(fpath->fdw_restrictinfo);
4227
4228 /* Hand over to FDW if needed. */
4229 rfpc_func =
4230 path->parent->fdwroutine->ReparameterizeForeignPathByChild;
4231 if (rfpc_func)
4232 fpath->fdw_private = rfpc_func(root, fpath->fdw_private,
4233 child_rel);
4234 new_path = (Path *) fpath;
4235 }
4236 break;
4237
4238 case T_CustomPath:
4239 {
4240 CustomPath *cpath = (CustomPath *) path;
4241
4242 ADJUST_CHILD_ATTRS(cpath->path.parent->baserestrictinfo);
4244 if (cpath->custom_restrictinfo)
4245 ADJUST_CHILD_ATTRS(cpath->custom_restrictinfo);
4246 if (cpath->methods &&
4247 cpath->methods->ReparameterizeCustomPathByChild)
4248 cpath->custom_private =
4249 cpath->methods->ReparameterizeCustomPathByChild(root,
4250 cpath->custom_private,
4251 child_rel);
4252 new_path = (Path *) cpath;
4253 }
4254 break;
4255
4256 case T_NestPath:
4257 {
4258 NestPath *npath = (NestPath *) path;
4259 JoinPath *jpath = (JoinPath *) npath;
4260
4264 new_path = (Path *) npath;
4265 }
4266 break;
4267
4268 case T_MergePath:
4269 {
4270 MergePath *mpath = (MergePath *) path;
4271 JoinPath *jpath = (JoinPath *) mpath;
4272
4276 ADJUST_CHILD_ATTRS(mpath->path_mergeclauses);
4277 new_path = (Path *) mpath;
4278 }
4279 break;
4280
4281 case T_HashPath:
4282 {
4283 HashPath *hpath = (HashPath *) path;
4284 JoinPath *jpath = (JoinPath *) hpath;
4285
4289 ADJUST_CHILD_ATTRS(hpath->path_hashclauses);
4290 new_path = (Path *) hpath;
4291 }
4292 break;
4293
4294 case T_AppendPath:
4295 {
4296 AppendPath *apath = (AppendPath *) path;
4297
4299 new_path = (Path *) apath;
4300 }
4301 break;
4302
4303 case T_MaterialPath:
4304 {
4305 MaterialPath *mpath = (MaterialPath *) path;
4306
4308 new_path = (Path *) mpath;
4309 }
4310 break;
4311
4312 case T_MemoizePath:
4313 {
4314 MemoizePath *mpath = (MemoizePath *) path;
4315
4317 ADJUST_CHILD_ATTRS(mpath->param_exprs);
4318 new_path = (Path *) mpath;
4319 }
4320 break;
4321
4322 case T_GatherPath:
4323 {
4324 GatherPath *gpath = (GatherPath *) path;
4325
4327 new_path = (Path *) gpath;
4328 }
4329 break;
4330
4331 default:
4332 /* We don't know how to reparameterize this path. */
4333 return NULL;
4334 }
4335
4336 /*
4337 * Adjust the parameterization information, which refers to the topmost
4338 * parent. The topmost parent can be multiple levels away from the given
4339 * child, hence use multi-level expression adjustment routines.
4340 */
4341 old_ppi = new_path->param_info;
4344 child_rel,
4345 child_rel->top_parent);
4346
4347 /* If we already have a PPI for this parameterization, just return it */
4349
4350 /*
4351 * If not, build a new one and link it to the list of PPIs. For the same
4352 * reason as explained in mark_dummy_rel(), allocate new PPI in the same
4353 * context the given RelOptInfo is in.
4354 */
4355 if (new_ppi == NULL)
4356 {
4357 MemoryContext oldcontext;
4358 RelOptInfo *rel = path->parent;
4359
4361
4363 new_ppi->ppi_req_outer = bms_copy(required_outer);
4364 new_ppi->ppi_rows = old_ppi->ppi_rows;
4365 new_ppi->ppi_clauses = old_ppi->ppi_clauses;
4366 ADJUST_CHILD_ATTRS(new_ppi->ppi_clauses);
4367 new_ppi->ppi_serials = bms_copy(old_ppi->ppi_serials);
4368 rel->ppilist = lappend(rel->ppilist, new_ppi);
4369
4370 MemoryContextSwitchTo(oldcontext);
4371 }
4373
4374 new_path->param_info = new_ppi;
4375
4376 /*
4377 * Adjust the path target if the parent of the outer relation is
4378 * referenced in the targetlist. This can happen when only the parent of
4379 * outer relation is laterally referenced in this relation.
4380 */
4381 if (bms_overlap(path->parent->lateral_relids,
4382 child_rel->top_parent_relids))
4383 {
4384 new_path->pathtarget = copy_pathtarget(new_path->pathtarget);
4385 ADJUST_CHILD_ATTRS(new_path->pathtarget->exprs);
4386 }
4387
4388 return new_path;
4389}
Relids adjust_child_relids_multilevel(PlannerInfo *root, Relids relids, RelOptInfo *childrel, RelOptInfo *parentrel)
Definition appendinfo.c:664
void bms_free(Bitmapset *a)
Definition bitmapset.c:240
List *(* ReparameterizeForeignPathByChild_function)(PlannerInfo *root, List *fdw_private, RelOptInfo *child_rel)
Definition fdwapi.h:186
MemoryContext GetMemoryChunkContext(void *pointer)
Definition mcxt.c:759
static MemoryContext MemoryContextSwitchTo(MemoryContext context)
Definition palloc.h:138
#define REPARAMETERIZE_CHILD_PATH_LIST(pathlist)
#define REPARAMETERIZE_CHILD_PATH(path)
#define ADJUST_CHILD_ATTRS(node)
#define planner_rt_fetch(rti, root)
Definition pathnodes.h:704
PathTarget * copy_pathtarget(PathTarget *src)
Definition tlist.c:666

References ADJUST_CHILD_ATTRS, adjust_child_relids_multilevel(), Assert, bms_copy(), bms_free(), bms_overlap(), copy_pathtarget(), fb(), find_param_path_info(), GetMemoryChunkContext(), JoinPath::innerjoinpath, JoinPath::joinrestrictinfo, lappend(), makeNode, MemoryContextSwitchTo(), nodeTag, JoinPath::outerjoinpath, PATH_REQ_OUTER, Path::pathtype, planner_rt_fetch, RelOptInfo::ppilist, REPARAMETERIZE_CHILD_PATH, REPARAMETERIZE_CHILD_PATH_LIST, root, and RTE_RELATION.

Referenced by create_nestloop_plan(), and reparameterize_pathlist_by_child().

◆ set_cheapest()

void set_cheapest ( RelOptInfo *  parent_rel)
extern

Definition at line 268 of file pathnode.c.

269{
270 Path *cheapest_startup_path;
271 Path *cheapest_total_path;
274 ListCell *p;
275
277
278 if (parent_rel->pathlist == NIL)
279 elog(ERROR, "could not devise a query plan for the given query");
280
281 cheapest_startup_path = cheapest_total_path = best_param_path = NULL;
283
284 foreach(p, parent_rel->pathlist)
285 {
286 Path *path = (Path *) lfirst(p);
287 int cmp;
288
289 if (path->param_info)
290 {
291 /* Parameterized path, so add it to parameterized_paths */
293
294 /*
295 * If we have an unparameterized cheapest-total, we no longer care
296 * about finding the best parameterized path, so move on.
297 */
298 if (cheapest_total_path)
299 continue;
300
301 /*
302 * Otherwise, track the best parameterized path, which is the one
303 * with least total cost among those of the minimum
304 * parameterization.
305 */
306 if (best_param_path == NULL)
307 best_param_path = path;
308 else
309 {
312 {
313 case BMS_EQUAL:
314 /* keep the cheaper one */
316 TOTAL_COST) < 0)
317 best_param_path = path;
318 break;
319 case BMS_SUBSET1:
320 /* new path is less-parameterized */
321 best_param_path = path;
322 break;
323 case BMS_SUBSET2:
324 /* old path is less-parameterized, keep it */
325 break;
326 case BMS_DIFFERENT:
327
328 /*
329 * This means that neither path has the least possible
330 * parameterization for the rel. We'll sit on the old
331 * path until something better comes along.
332 */
333 break;
334 }
335 }
336 }
337 else
338 {
339 /* Unparameterized path, so consider it for cheapest slots */
340 if (cheapest_total_path == NULL)
341 {
342 cheapest_startup_path = cheapest_total_path = path;
343 continue;
344 }
345
346 /*
347 * If we find two paths of identical costs, try to keep the
348 * better-sorted one. The paths might have unrelated sort
349 * orderings, in which case we can only guess which might be
350 * better to keep, but if one is superior then we definitely
351 * should keep that one.
352 */
353 cmp = compare_path_costs(cheapest_startup_path, path, STARTUP_COST);
354 if (cmp > 0 ||
355 (cmp == 0 &&
356 compare_pathkeys(cheapest_startup_path->pathkeys,
357 path->pathkeys) == PATHKEYS_BETTER2))
358 cheapest_startup_path = path;
359
360 cmp = compare_path_costs(cheapest_total_path, path, TOTAL_COST);
361 if (cmp > 0 ||
362 (cmp == 0 &&
363 compare_pathkeys(cheapest_total_path->pathkeys,
364 path->pathkeys) == PATHKEYS_BETTER2))
365 cheapest_total_path = path;
366 }
367 }
368
369 /* Add cheapest unparameterized path, if any, to parameterized_paths */
370 if (cheapest_total_path)
371 parameterized_paths = lcons(cheapest_total_path, parameterized_paths);
372
373 /*
374 * If there is no unparameterized path, use the best parameterized path as
375 * cheapest_total_path (but not as cheapest_startup_path).
376 */
377 if (cheapest_total_path == NULL)
378 cheapest_total_path = best_param_path;
379 Assert(cheapest_total_path != NULL);
380
381 parent_rel->cheapest_startup_path = cheapest_startup_path;
382 parent_rel->cheapest_total_path = cheapest_total_path;
383 parent_rel->cheapest_parameterized_paths = parameterized_paths;
384}
@ BMS_DIFFERENT
Definition bitmapset.h:65
List * lcons(void *datum, List *list)
Definition list.c:495
static int cmp(const chr *x, const chr *y, size_t len)

References Assert, BMS_DIFFERENT, BMS_EQUAL, BMS_SUBSET1, BMS_SUBSET2, bms_subset_compare(), cmp(), compare_path_costs(), compare_pathkeys(), elog, ERROR, fb(), IsA, lappend(), lcons(), lfirst, NIL, PATH_REQ_OUTER, Path::pathkeys, PATHKEYS_BETTER2, STARTUP_COST, and TOTAL_COST.

Referenced by apply_scanjoin_target_to_paths(), create_distinct_paths(), create_grouping_paths(), create_ordinary_grouping_paths(), create_partial_distinct_paths(), create_partial_unique_paths(), create_partitionwise_grouping_paths(), create_unique_paths(), create_window_paths(), generate_partitionwise_join_paths(), mark_dummy_rel(), merge_clump(), postprocess_setop_rel(), query_planner(), set_dummy_rel_pathlist(), set_grouped_rel_pathlist(), set_rel_pathlist(), standard_join_search(), and subquery_planner().

◆ setup_simple_rel_arrays()

void setup_simple_rel_arrays ( PlannerInfo *  root)
extern

Definition at line 114 of file relnode.c.

115{
116 int size;
117 Index rti;
118 ListCell *lc;
119
120 /* Arrays are accessed using RT indexes (1..N) */
121 size = list_length(root->parse->rtable) + 1;
122 root->simple_rel_array_size = size;
123
124 /*
125 * simple_rel_array is initialized to all NULLs, since no RelOptInfos
126 * exist yet. It'll be filled by later calls to build_simple_rel().
127 */
128 root->simple_rel_array = (RelOptInfo **)
129 palloc0_array(RelOptInfo *, size);
130
131 /* simple_rte_array is an array equivalent of the rtable list */
132 root->simple_rte_array = (RangeTblEntry **)
134 rti = 1;
135 foreach(lc, root->parse->rtable)
136 {
138
139 root->simple_rte_array[rti++] = rte;
140 }
141
142 /* append_rel_array is not needed if there are no AppendRelInfos */
143 if (root->append_rel_list == NIL)
144 {
145 root->append_rel_array = NULL;
146 return;
147 }
148
149 root->append_rel_array = (AppendRelInfo **)
151
152 /*
153 * append_rel_array is filled with any already-existing AppendRelInfos,
154 * which currently could only come from UNION ALL flattening. We might
155 * add more later during inheritance expansion, but it's the
156 * responsibility of the expansion code to update the array properly.
157 */
158 foreach(lc, root->append_rel_list)
159 {
161 int child_relid = appinfo->child_relid;
162
163 /* Sanity check */
164 Assert(child_relid < size);
165
166 if (root->append_rel_array[child_relid])
167 elog(ERROR, "child relation already exists");
168
169 root->append_rel_array[child_relid] = appinfo;
170 }
171}

References Assert, elog, ERROR, fb(), lfirst, lfirst_node, list_length(), NIL, palloc0_array, and root.

Referenced by plan_cluster_use_sort(), plan_create_index_workers(), plan_set_operations(), and query_planner().

Variable Documentation

◆ build_simple_rel_hook

PGDLLIMPORT build_simple_rel_hook_type build_simple_rel_hook
extern

Definition at line 51 of file relnode.c.

Referenced by build_simple_rel(), and pgpa_planner_install_hooks().

◆ joinrel_setup_hook

PGDLLIMPORT joinrel_setup_hook_type joinrel_setup_hook
extern

Definition at line 54 of file relnode.c.

Referenced by build_child_join_rel(), build_join_rel(), and pgpa_planner_install_hooks().